omp-map-gpt4o-ground-003
dom · homebot-dom · 2026-11-02 19:10 ·
homebot-dom/runs/omp-map-gpt4o-ground-003MP4 · 450.8 KB · pełny ekran w playerze
room
living_ground · rev 1| wymiar | wartość | status |
|---|---|---|
| width | 1.958 m | measured_across_calibrated_views |
| length | — | opposing_planes_not_observed |
| height | 2.702 m | observed_floor_and_ceiling |
ściany: wall_main_w, wall_wc_e, wall_vest_e, wall_vest_s, wall_fitness_e
obiekty: g_wc_frame, g_vestibule_frame, g_wc, g_vestibule, g_kitchen_w, g_kitchen_n, g_island, g_dining, g_chair0
skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt9 calli · $0.190
ag. limity9 req · 7 seq · 13 tools
czas misji31.3s
calle LLM
9
tool calls
13
koszt zadania
$0.190
tokeny (sum)
118,515
in / out
26,693 / 942
cache R/W
90,880 / 0
czas modelu
24.4s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 2.0s toolUse | robot_capabilities Discover complete capabilities of the robot mode=SIMULATION_ONLY robot_observe Initial observation to start room exploration {"observation_id":"obs-271537f3-1-350","session_id":"271537f3","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… | 5,833 in 5775 · out 58 | $0.015 |
| 2 | 2.6s toolUse | robot_look Rotate left for new view ok robot_look Rotate right for new view rejected | 9,301 in 9176 · out 125 | $0.024 |
| 3 | 2.1s toolUse | robot_observe Get current observation after look movement {"observation_id":"obs-271537f3-2-1100","session_id":"271537f3","time_s":2.2,"rgb_path":"/home/pawel/Documents/HomeBot_… robot_look Rotate back to neutral for new view rejected | 9,470 in 163 · out 91 · cR 9216 · cW 0 | $0.013 |
| 4 | 3.6s toolUse | robot_look Pan slightly left for better coverage ok robot_look Tilt slightly down to capture the floor rejected | 11,576 in 2101 · out 131 · cR 9344 · cW 0 | $0.018 |
| 5 | 1.9s toolUse | robot_observe Get current observation after pan adjustment {"observation_id":"obs-271537f3-3-1475","session_id":"271537f3","time_s":2.95,"rgb_path":"/home/pawel/Documents/HomeBot… | 11,675 in 262 · out 21 · cR 11392 · cW 0 | $0.015 |
| 6 | 3.3s toolUse | robot_look Pan slightly more to right for coverage ok robot_look Tilt slightly down to capture more floor rejected | 14,912 in 3261 · out 131 · cR 11520 · cW 0 | $0.024 |
| 7 | 1.5s toolUse | robot_observe Get current observation after pan right adjustment {"observation_id":"obs-271537f3-4-2225","session_id":"271537f3","time_s":4.45,"rgb_path":"/home/pawel/Documents/HomeBot… | 15,012 in 270 · out 22 · cR 14720 · cW 0 | $0.019 |
| 8 | 2.1s toolUse | room_measure Measure and record the current room layout based on observations {"memory_revision":1,"dimensions":{"width":{"value_m":1.9579,"sigma_floor_m":0.02,"source_walls":["wall_main_w","wall_w… | 20,060 in 5184 · out 28 · cR 14848 · cW 0 | $0.032 |
| 9 | 5.2s stop | ### Raport z mapowania salonu #### Wymiary pomieszczenia: - **Szerokość**: 1.96 m ±0.02 m - Źródło: ściany "wall_main_w" i "wall_wc_e" - **Długość**: niezmierzona (brak przeciwnych ścian w polu widzenia) - **Wysokość… | 20,676 in 501 · out 335 · cR 19840 · cW 0 | $0.029 |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
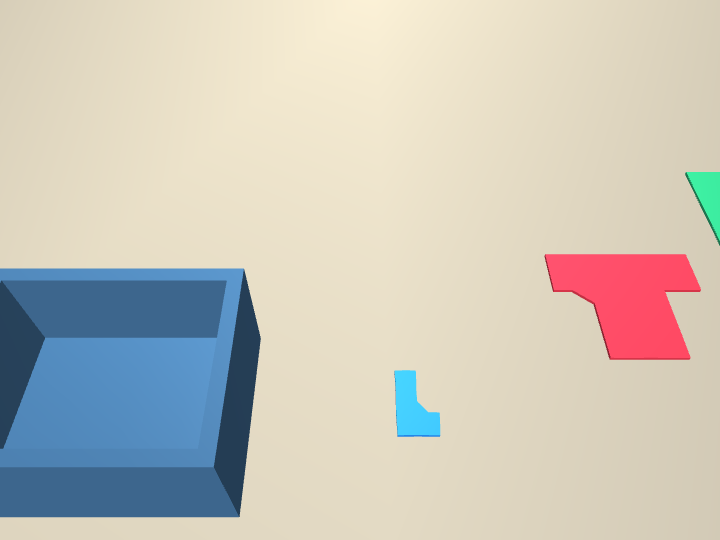
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981172712442117
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976743280257718
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976121953713187
    }
  },
  "events": [],
  "sim_time_s": 4.449999999999732,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 2.394337903616256e-38,
      "handle_angle_rad": -2.474362245376641e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.092799729361118e-09,
      "handle_angle_rad": 4.838773212432055e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -3.8405142703747334e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -6.0927997293420396e-09,
      "handle_angle_rad": 3.2697716257142916e-19,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -6.295382006313478e-09,
      "handle_angle_rad": -1.9560379617888122e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.295382006313478e-09,
      "handle_angle_rad": -1.9560379617888122e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.092799729346169e-09,
      "handle_angle_rad": -7.182565744721386e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}