Wszystkie przebiegi Mapowanie domu GPT-4o mapa 003 Laundry Archiwum

HomeBot — wyniki, filmy i calle LLM

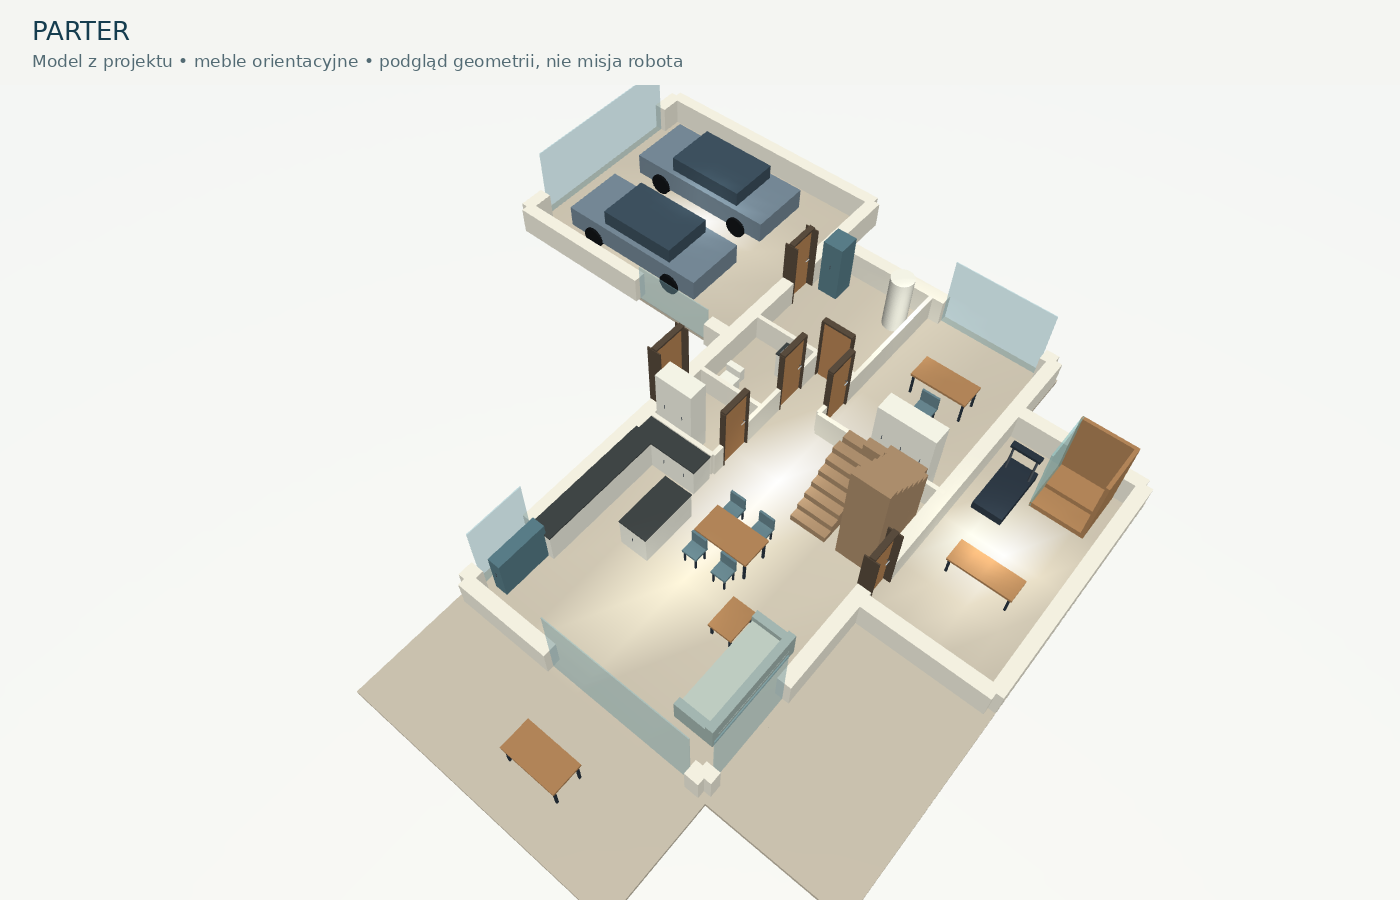
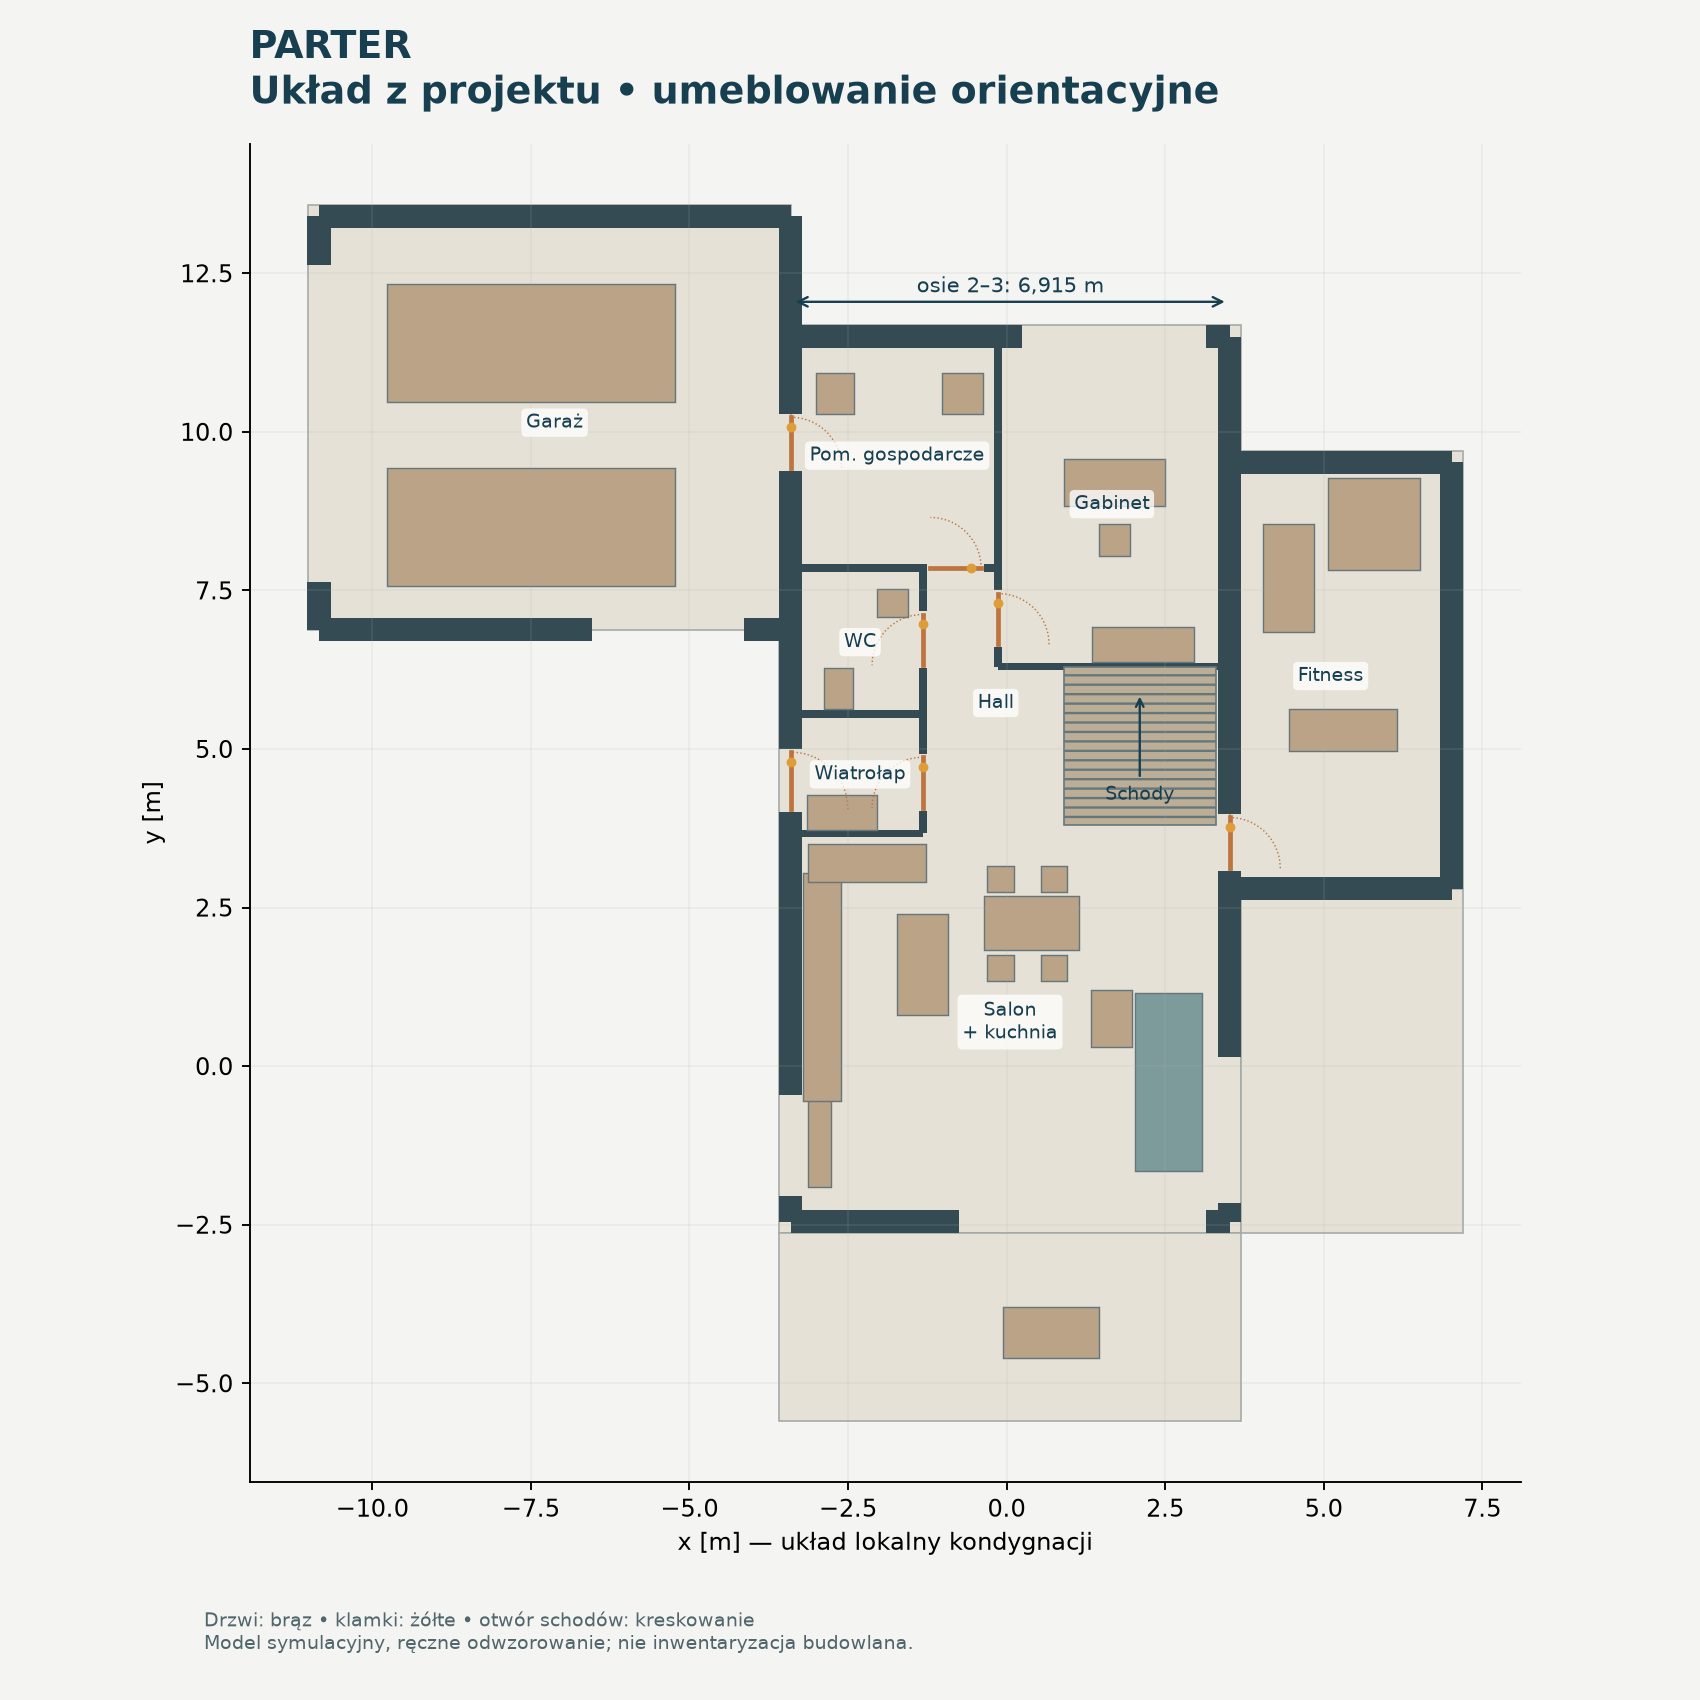
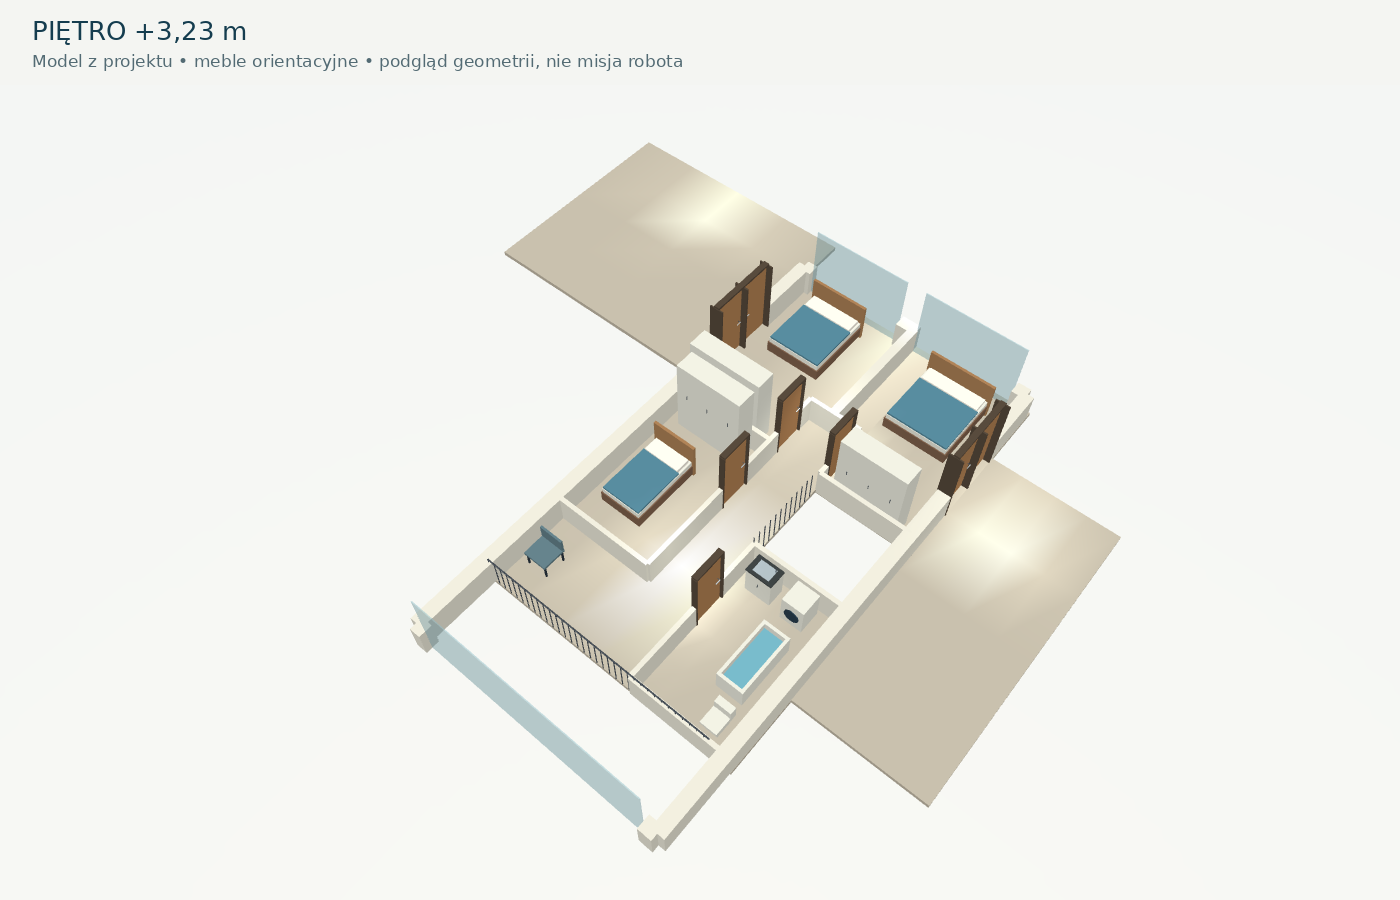
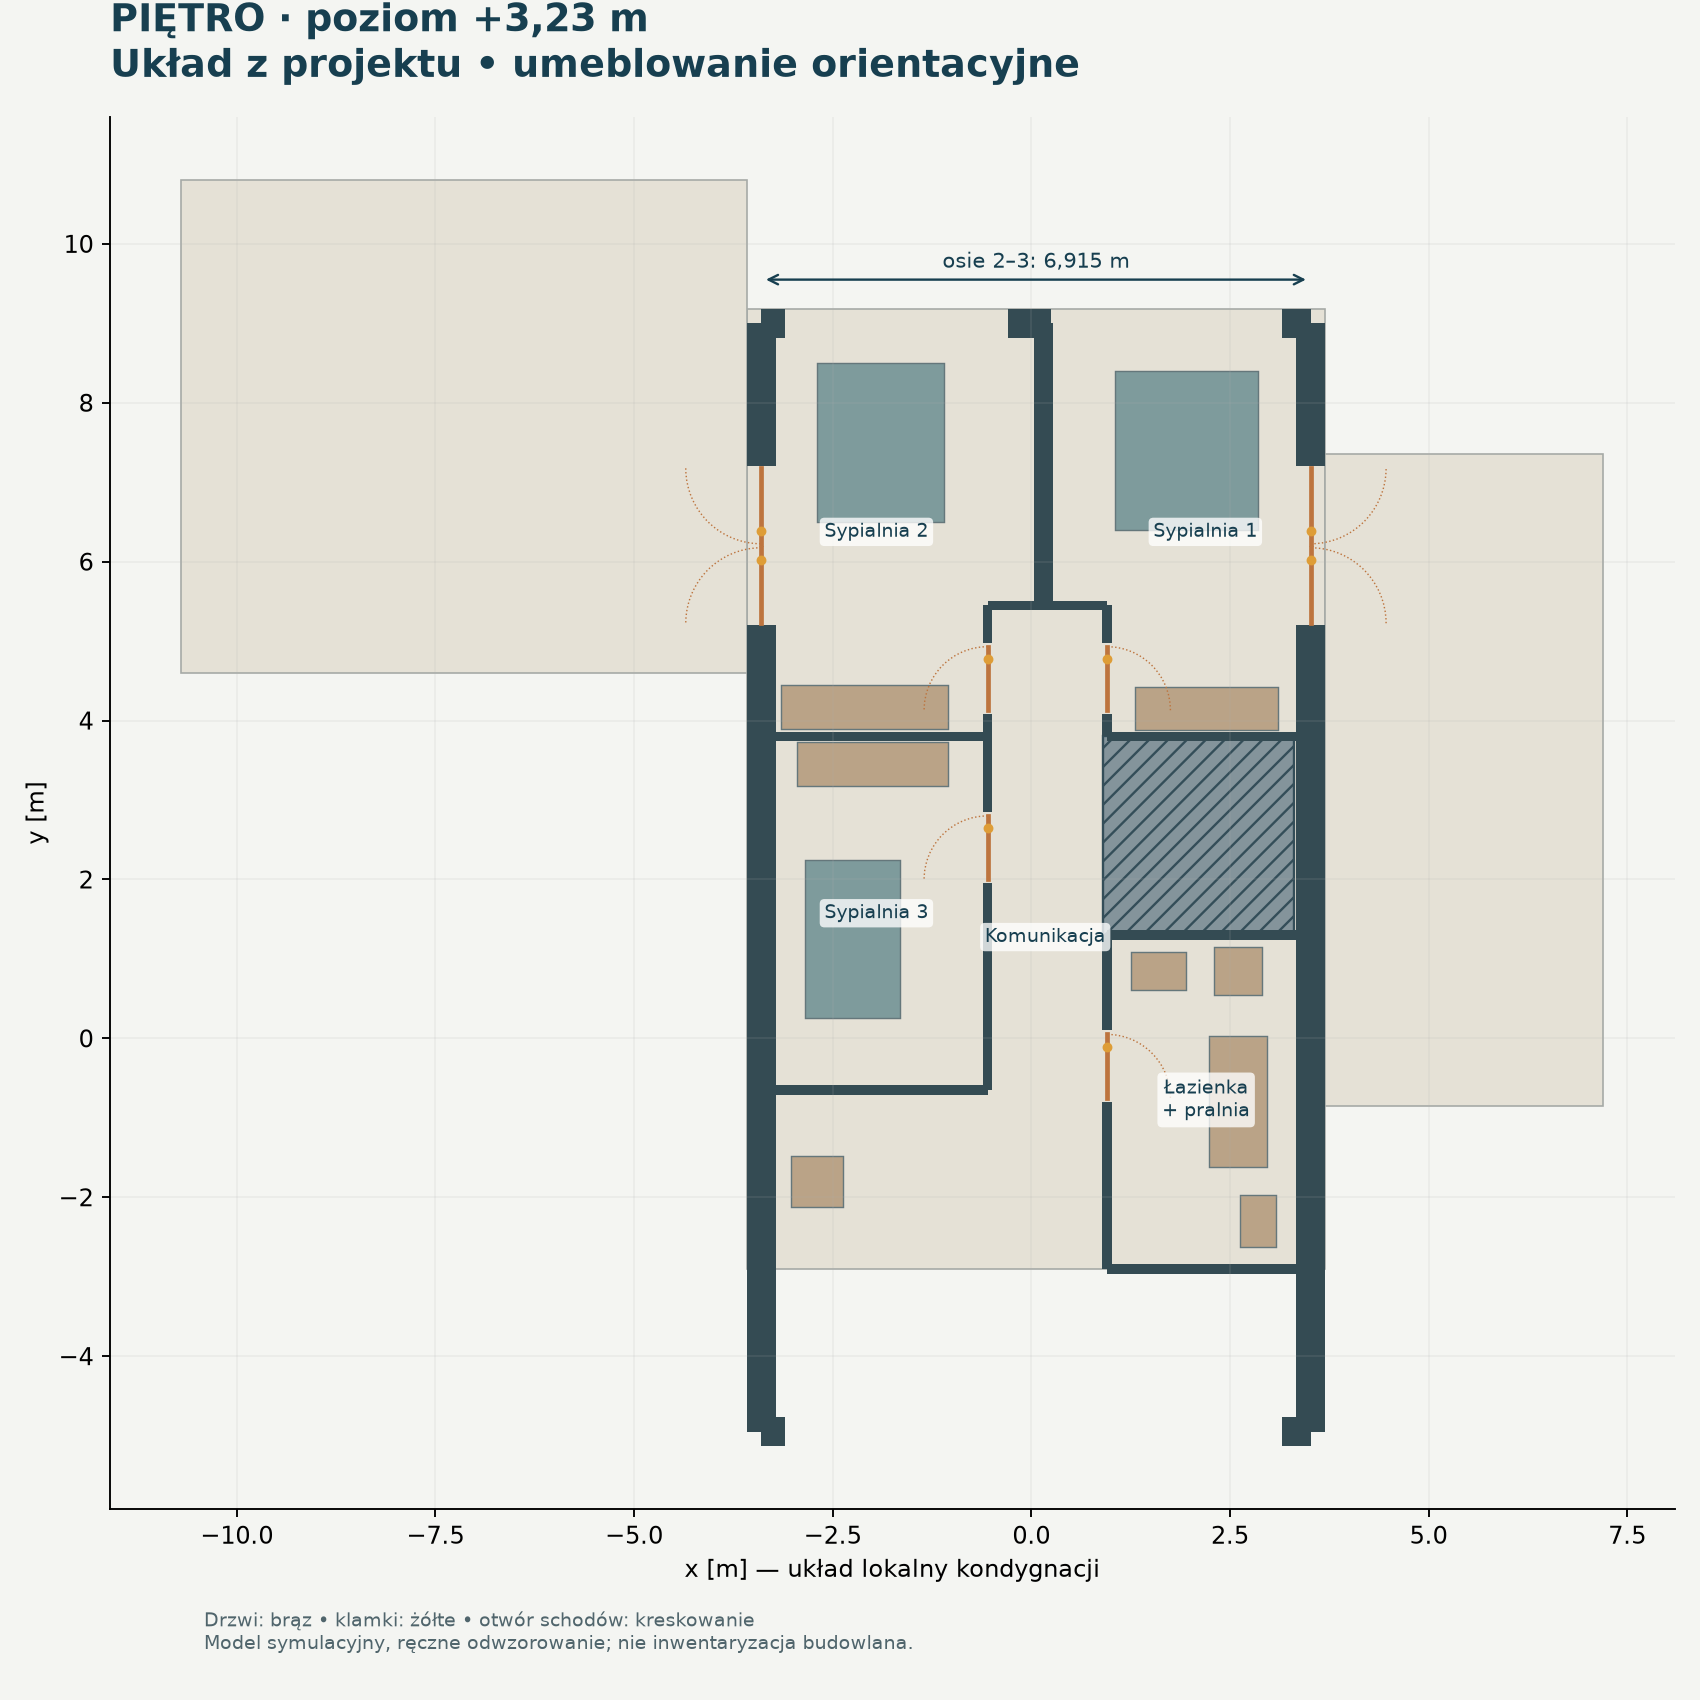
Projekt domu (mapowanie GPT-4o) na górze. Dalej: laundry i archiwum. Odśwież stronę twardo (Ctrl+Shift+R).

Projekt domu · mapowanie

omp-map-gpt4o-ground-004-length

dom · homebot-dom · 2026-11-02 19:30 · homebot-dom/runs/omp-map-gpt4o-ground-004-length
mapa · w=1.96m · l=2.69m · h=2.70m

MP4 · 334.6 KB · pełny ekran w playerze

room living_ground · rev 2
wymiarwartośćstatus
width1.958 mmeasured_across_calibrated_views
length2.691 mmeasured_across_calibrated_views
height2.701 mobserved_floor_and_ceiling

ściany: wall_main_w, wall_office_s, wall_office_w, wall_wc_e, wall_vest_e, wall_vest_s
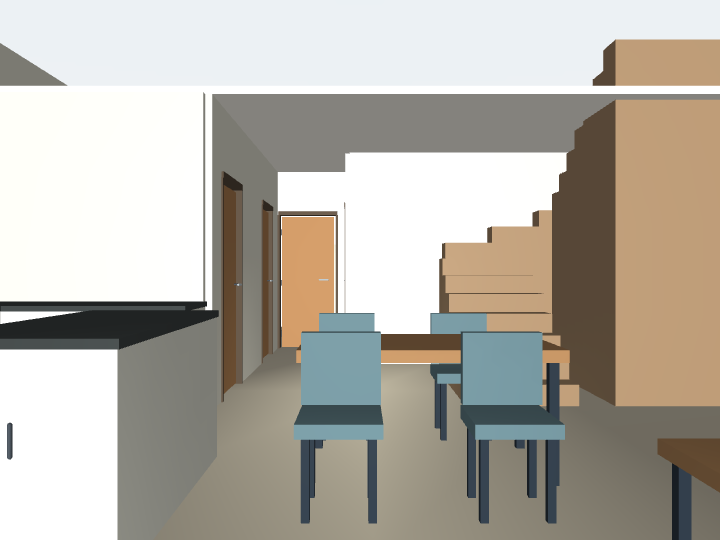
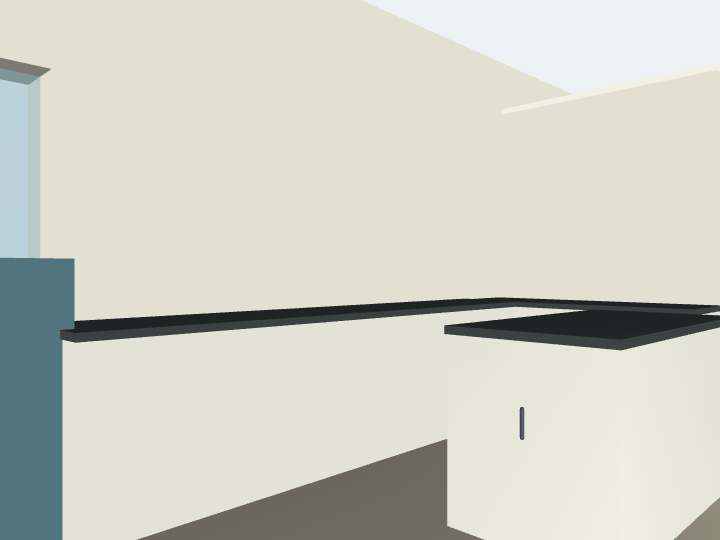
obiekty: collection_bin, g_entrance_frame, g_garage_utility_frame, g_office_frame, g_wc_frame, g_vestibule_frame, g_vestibule, g_coffee, g_kitchen_n, g_island, g_dining, g_chair0, g_chair1, g_chair2, g_chair3

skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt6 calli · $0.131
ag. limity6 req · 3 seq · 10 tools
czas misji22.1s
calle LLM
6
tool calls
10
koszt zadania
$0.131
tokeny (sum)
76,875
in / out
23,473 / 666
cache R/W
52,736 / 0
czas modelu
16.0s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.1s
toolUse
robot_capabilities
Discover robot capabilities, dimensions, and memory context for initial setup
mode=SIMULATION_ONLY
mission_memory_read
Check past memory for measurement context
{"revision":0,"agent_notes":null}
robot_observe
Gather a fresh observation from the robot's sensors
{"observation_id":"obs-6a2d6a9a-1-350","session_id":"6a2d6a9a","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
6,357
in 6268 · out 89
$0.017
22.9s
toolUse
robot_look
Adjust the camera to look directly at the walls for better visibility
ok
room_measure
Attempt to measure room dimensions post adjustment
{"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
9,833
in 9730 · out 103
$0.025
32.5s
toolUse
robot_move_base
Rotate right to find the missing wall along the Y axis
rejected
robot_observe
Observe the scene again after rotation to capture the room's dimensions
{"observation_id":"obs-6a2d6a9a-2-913","session_id":"6a2d6a9a","time_s":1.826,"rgb_path":"/home/pawel/Documents/HomeBot…
10,159
in 320 · out 111 · cR 9728 · cW 0
$0.014
42.4s
toolUse
room_measure
Measure room dimensions based on the new observation
{"memory_revision":2,"dimensions":{"width":{"value_m":1.9579,"sigma_floor_m":0.02,"source_walls":["wall_main_w","wall_w…
robot_move_base
Rotate left to continue searching for the Y-axis wall
ok
16,361
in 6267 · out 110 · cR 9984 · cW 0
$0.029
52.9s
toolUse
mission_memory_write
Save the observed walls and dimensions to agent memory after successful measurement
{"revision":1,"kind":"agent_mission_notes","notes":"Walls: [wall_main_w, wall_office_s, wall_office_w, wall_wc_e, wall_…
16,947
in 606 · out 85 · cR 16256 · cW 0
$0.023
63.2s
stop
**Raport pomiaru salonu:** - **Szerokość (width):** 1.96 m (pomiędzy ścianami `wall_main_w` i `wall_wc_e`) - **Długość (length):** 2.69 m (pomiędzy ścianami `wall_vest_s` i `wall_office_w`) - **Wysokość (height):** 2.7…
17,218
in 282 · out 168 · cR 16768 · cW 0
$0.023

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
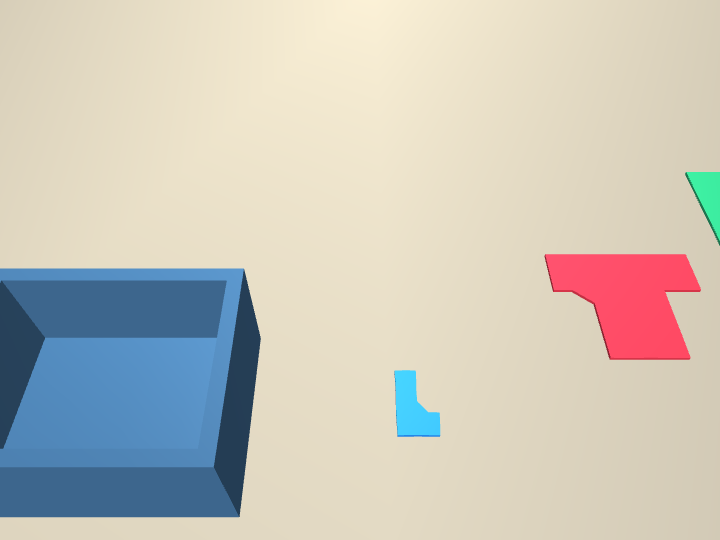
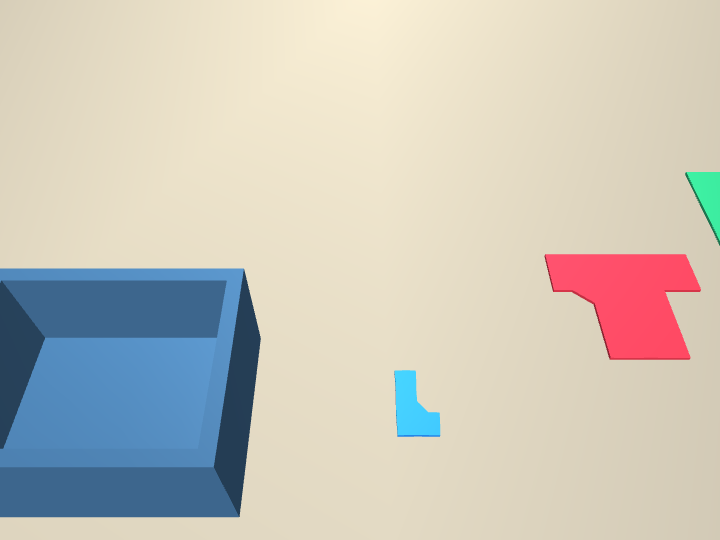
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981341493557777
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976747703093815
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039762428392429786
    }
  },
  "events": [],
  "sim_time_s": 3.763999999999807,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 4.5047598224383705e-38,
      "handle_angle_rad": -3.293718532894255e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.548019428077347e-09,
      "handle_angle_rad": 2.332507939218802e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -2.2575735220521414e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -6.548019428059878e-09,
      "handle_angle_rad": -5.426791797586747e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -6.1044323402293055e-09,
      "handle_angle_rad": -2.755194612991635e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.1044323402293055e-09,
      "handle_angle_rad": -2.755194612991635e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.5480194280647275e-09,
      "handle_angle_rad": -4.3732926685517466e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-map-gpt4o-ground-002

dom · homebot-dom · 2026-11-02 19:10 · homebot-dom/runs/omp-map-gpt4o-ground-002
mapa częściowa · 2 ścian · 4 obj

MP4 · 183.0 KB · pełny ekran w playerze

room living_ground · rev 1
wymiarwartośćstatus
width—opposing_planes_not_observed
length—opposing_planes_not_observed
height—floor_or_ceiling_not_observed

ściany: wall_main_w, wall_vest_s
obiekty: g_tv, g_kitchen_w, g_kitchen_n, g_island

skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt8 calli · $0.108
ag. limity7 req · 2 seq · 8 tools
czas misji20.2s
status agentarobot_stop_latched
calle LLM
8
tool calls
8
koszt zadania
$0.108
tokeny (sum)
65,282
in / out
18,775 / 299
cache R/W
46,208 / 0
czas modelu
16.3s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
11.8s
toolUse
robot_capabilities
Discover capabilities of the robot
mode=SIMULATION_ONLY
mission_memory_read
Read previous mission memory, if available
{"revision":0,"agent_notes":null}
5,890
in 5831 · out 59
$0.015
21.5s
toolUse
robot_observe
Gather initial observation of the room
{"observation_id":"obs-332a92a6-1-350","session_id":"332a92a6","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
6,796
in 1015 · out 21 · cR 5760 · cW 0
$0.0099
34.2s
toolUse
robot_look
Pan and tilt to get a better view
ok
9,050
in 8992 · out 58
$0.023
42.1s
toolUse
robot_observe
Gather observation after camera movement
{"observation_id":"obs-332a92a6-2-913","session_id":"332a92a6","time_s":1.826,"rgb_path":"/home/pawel/Documents/HomeBot…
9,119
in 139 · out 20 · cR 8960 · cW 0
$0.012
52.3s
toolUse
room_measure
Measure room dimensions after new observation
{"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
11,283
in 2299 · out 24 · cR 8960 · cW 0
$0.017
62.4s
toolUse
mission_memory_write
Write notes about visible room elements after observation
{"revision":1,"kind":"agent_mission_notes","notes":"Observed walls: wall_main_w, wall_vest_s. Visible furniture: TV, ki…
11,504
in 319 · out 49 · cR 11136 · cW 0
$0.015
72.1s
toolUse
robot_move_base
Move base slightly to gain a better perspective on room dimensions
collision_guard
11,640
in 180 · out 68 · cR 11392 · cW 0
$0.015
8—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981167881223428
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976830550232652
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976194567067097
    }
  },
  "events": [],
  "sim_time_s": 1.8260000000000014,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 1.7954173729684502e-38,
      "handle_angle_rad": -1.4801365655551515e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -9.115101869203954e-09,
      "handle_angle_rad": -7.134280375091383e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -1.4800792036491003e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -9.115101869192668e-09,
      "handle_angle_rad": -2.303831533336789e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -9.105487218718805e-09,
      "handle_angle_rad": -3.474846430570292e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -9.105487218718805e-09,
      "handle_angle_rad": -3.474846430570292e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -9.115101869195405e-09,
      "handle_angle_rad": -6.926040406684193e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-map-gpt4o-ground-003

dom · homebot-dom · 2026-11-02 19:10 · homebot-dom/runs/omp-map-gpt4o-ground-003
mapa · w=1.96m · h=2.70m

MP4 · 450.8 KB · pełny ekran w playerze

room living_ground · rev 1
wymiarwartośćstatus
width1.958 mmeasured_across_calibrated_views
length—opposing_planes_not_observed
height2.702 mobserved_floor_and_ceiling

ściany: wall_main_w, wall_wc_e, wall_vest_e, wall_vest_s, wall_fitness_e
obiekty: g_wc_frame, g_vestibule_frame, g_wc, g_vestibule, g_kitchen_w, g_kitchen_n, g_island, g_dining, g_chair0

skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt9 calli · $0.190
ag. limity9 req · 7 seq · 13 tools
czas misji31.3s
calle LLM
9
tool calls
13
koszt zadania
$0.190
tokeny (sum)
118,515
in / out
26,693 / 942
cache R/W
90,880 / 0
czas modelu
24.4s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.0s
toolUse
robot_capabilities
Discover complete capabilities of the robot
mode=SIMULATION_ONLY
robot_observe
Initial observation to start room exploration
{"observation_id":"obs-271537f3-1-350","session_id":"271537f3","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
5,833
in 5775 · out 58
$0.015
22.6s
toolUse
robot_look
Rotate left for new view
ok
robot_look
Rotate right for new view
rejected
9,301
in 9176 · out 125
$0.024
32.1s
toolUse
robot_observe
Get current observation after look movement
{"observation_id":"obs-271537f3-2-1100","session_id":"271537f3","time_s":2.2,"rgb_path":"/home/pawel/Documents/HomeBot_…
robot_look
Rotate back to neutral for new view
rejected
9,470
in 163 · out 91 · cR 9216 · cW 0
$0.013
43.6s
toolUse
robot_look
Pan slightly left for better coverage
ok
robot_look
Tilt slightly down to capture the floor
rejected
11,576
in 2101 · out 131 · cR 9344 · cW 0
$0.018
51.9s
toolUse
robot_observe
Get current observation after pan adjustment
{"observation_id":"obs-271537f3-3-1475","session_id":"271537f3","time_s":2.95,"rgb_path":"/home/pawel/Documents/HomeBot…
11,675
in 262 · out 21 · cR 11392 · cW 0
$0.015
63.3s
toolUse
robot_look
Pan slightly more to right for coverage
ok
robot_look
Tilt slightly down to capture more floor
rejected
14,912
in 3261 · out 131 · cR 11520 · cW 0
$0.024
71.5s
toolUse
robot_observe
Get current observation after pan right adjustment
{"observation_id":"obs-271537f3-4-2225","session_id":"271537f3","time_s":4.45,"rgb_path":"/home/pawel/Documents/HomeBot…
15,012
in 270 · out 22 · cR 14720 · cW 0
$0.019
82.1s
toolUse
room_measure
Measure and record the current room layout based on observations
{"memory_revision":1,"dimensions":{"width":{"value_m":1.9579,"sigma_floor_m":0.02,"source_walls":["wall_main_w","wall_w…
20,060
in 5184 · out 28 · cR 14848 · cW 0
$0.032
95.2s
stop
### Raport z mapowania salonu #### Wymiary pomieszczenia: - **Szerokość**: 1.96 m ±0.02 m - Źródło: ściany "wall_main_w" i "wall_wc_e" - **Długość**: niezmierzona (brak przeciwnych ścian w polu widzenia) - **Wysokość…
20,676
in 501 · out 335 · cR 19840 · cW 0
$0.029

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981172712442117
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976743280257718
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976121953713187
    }
  },
  "events": [],
  "sim_time_s": 4.449999999999732,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 2.394337903616256e-38,
      "handle_angle_rad": -2.474362245376641e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.092799729361118e-09,
      "handle_angle_rad": 4.838773212432055e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -3.8405142703747334e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -6.0927997293420396e-09,
      "handle_angle_rad": 3.2697716257142916e-19,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -6.295382006313478e-09,
      "handle_angle_rad": -1.9560379617888122e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.295382006313478e-09,
      "handle_angle_rad": -1.9560379617888122e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.092799729346169e-09,
      "handle_angle_rad": -7.182565744721386e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-map-gpt4o-ground-001

dom · homebot-dom · 2026-11-02 19:08 · homebot-dom/runs/omp-map-gpt4o-ground-001
mapa częściowa · 0 ścian · 1 obj

MP4 · 48.5 KB · pełny ekran w playerze

room living_ground · rev 3
wymiarwartośćstatus
width—opposing_planes_not_observed
length—opposing_planes_not_observed
height—floor_or_ceiling_not_observed

ściany: —
obiekty: collection_bin

skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt7 calli · $0.131
ag. limity7 req · 2 seq · 9 tools
czas misji25.7s
calle LLM
7
tool calls
9
koszt zadania
$0.131
tokeny (sum)
78,494
in / out
20,951 / 711
cache R/W
56,832 / 0
czas modelu
22.8s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.1s
toolUse
robot_capabilities
Odkryj zdolności robota w kontekście MCP v4
mode=SIMULATION_ONLY
robot_observe
Pobierz pierwsze RGB-D i sensory dla pomieszczenia startowego
{"observation_id":"obs-10066ff8-1-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
5,793
in 5715 · out 78
$0.015
26.3s
toolUse
room_measure
Zmierz nową obserwację dla pokoju, uwzględniając obecną kalibrację
{"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
9,177
in 9136 · out 41
$0.023
32.5s
toolUse
robot_observe
Pobierz kolejną obserwację RGB-D i sensory
{"observation_id":"obs-10066ff8-2-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
robot_look
Obróć kamerę w bezpiecznym zakresie aby zbadać więcej pomieszczenia
rejected
9,433
in 229 · out 116 · cR 9088 · cW 0
$0.013
41.6s
toolUse
room_measure
Zmierz kolejną obserwację dla pokoju po zmianie widoku
{"memory_revision":2,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
11,966
in 2588 · out 34 · cR 9344 · cW 0
$0.018
52.6s
toolUse
robot_observe
Pobierz trzecią unikalną obserwację RGB-D i sensory
{"observation_id":"obs-10066ff8-3-350","session_id":"10066ff8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
robot_look
Obróć kamerę na nowe miejsce aby spróbować uchwycić więcej przestrzeni
rejected
12,223
in 329 · out 118 · cR 11776 · cW 0
$0.017
62.8s
toolUse
room_measure
Zaktualizuj pomiary na bazie trzeciej obserwacji
{"memory_revision":3,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
14,736
in 2670 · out 34 · cR 12032 · cW 0
$0.022
74.8s
stop
**Raport z mapowania pomieszczenia:** 1. **Zmierzono:** - Zidentyfikowano lokalizację pojemnika (obiekt: collection_bin). - Widoczna powierzchnia podłogi jest odnotowana, ale brak pełnych danych na temat przeciws…
15,166
in 284 · out 290 · cR 14592 · cW 0
$0.022

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981376356301913
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976800826699878
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976144772117645
    }
  },
  "events": [],
  "sim_time_s": 0.7000000000000005,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 8.355828800962518e-38,
      "handle_angle_rad": -4.155420223110155e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -7.54215544090371e-09,
      "handle_angle_rad": 6.22153966751848e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.155420223108506e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -7.542155440900925e-09,
      "handle_angle_rad": -4.457617378534617e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -7.534199941256135e-09,
      "handle_angle_rad": -2.208855896820167e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -7.534199941256135e-09,
      "handle_angle_rad": -2.208855896820167e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -7.542155440901597e-09,
      "handle_angle_rad": -7.199704968859303e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-phased-luna56-006

dom · homebot-dom · 2026-11-03 11:26 · homebot-dom/runs/omp-door-chain-phased-luna56-006
0/3 w koszu

MP4 · 567.4 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt45 calli · $0.182
ag. limity45 req · 20 seq · 44 tools
czas misji236.8s
status agentaError: 402 This request would exceed your available credits given your current in-flight requests. Retry after in-flight requests settle, or add credits. retry-after-ms=120000
calle LLM
45
tool calls
44
koszt zadania
$0.182
tokeny (sum)
1,627,981
in / out
132 / 4,592
cache R/W
996,282 / 626,975
czas modelu
160.6s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.6s
toolUse
robot_capabilities
DISCOVER: sprawdź pełne możliwości v4, podnośnik, ramy i limity dla fazy 1; bez ruchu
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć misji dla fazy 1; traktuj jako niezweryfikowane notatki
{"revision":0,"agent_notes":null}
7,871
in 3 · out 151 · cR 7184 · cW 533 · reason 42
$0.0005
21.9s
toolUse
robot_observe
SURVEY: świeża obserwacja widocznych drzwi gabinetu g_office, klamki, liścia, lidar, sił i odometrii; bez ruchu
{"observation_id":"obs-6658f778-1-350","session_id":"6658f778","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,658
in 3 · out 68 · cR 7717 · cW 870 · reason 8
$0.0005
34.1s
toolUse
robot_look
SURVEY uzupełniające: skieruj kamerę na klamkę g_office i uzyskaj aktualnego handle_candidate_m oraz geometrię zawiasu/liścia; bez manipulacji
ok
11,364
in 3 · out 237 · cR 8587 · cW 2537 · reason 136
$0.0011
42.1s
toolUse
robot_observe
SWEEP_CHECK: po zmianie widoku ponownie zmierz klamkę, liść i wolną przestrzeń; potwierdź bezpieczny łuk otwierania przed ruchem
{"observation_id":"obs-6658f778-2-788","session_id":"6658f778","time_s":1.576,"rgb_path":"/home/pawel/Documents/HomeBot…
11,347
in 3 · out 59 · cR 11124 · cW 161
$0.0003
53.3s
toolUse
robot_move_base
SWEEP_CHECK zaliczony z aktualnej obserwacji; ramię schowane, lift=0. Obróć bazę krótko w stronę zawiasu (+0.785 rad), bez przejazdu przez próg
ok
13,969
in 3 · out 143 · cR 11285 · cW 2538 · reason 29
$0.0010
63.1s
toolUse
robot_observe
Po hinge-clear: świeża obserwacja potwierdzająca brak stopu, pozycję bazy i aktualną klamkę przed podniesieniem kolumny
{"observation_id":"obs-6658f778-3-2002","session_id":"6658f778","time_s":4.004,"rgb_path":"/home/pawel/Documents/HomeBo…
14,086
in 3 · out 56 · cR 13823 · cW 204
$0.0004
73.0s
toolUse
robot_move_lift
REACH przygotowanie: podnieś pustą, schowaną kolumnę do 0.40 m; bez jazdy
ok
16,474
in 3 · out 98 · cR 14027 · cW 2346 · reason 16
$0.0010
82.7s
toolUse
robot_observe
Po podniesieniu: świeża obserwacja z aktualnym handle_candidate_m w arm_carriage i kontrolą stop/contact
{"observation_id":"obs-6658f778-4-5336","session_id":"6658f778","time_s":10.672,"rgb_path":"/home/pawel/Documents/HomeB…
16,549
in 3 · out 45 · cR 16373 · cW 128
$0.0004
94.0s
toolUse
robot_look
REACH: po podniesieniu klamka jest chwilowo poza maską; zmień tylko widok, aby ponownie uzyskać aktualny handle_candidate_m dla g_office
ok
19,025
in 3 · out 150 · cR 16501 · cW 2371 · reason 47
$0.0011
102.8s
toolUse
robot_observe
REACH: świeży pomiar po zmianie widoku; użyj wyłącznie aktualnego handle_candidate_m
{"observation_id":"obs-6658f778-5-5555","session_id":"6658f778","time_s":11.11,"rgb_path":"/home/pawel/Documents/HomeBo…
19,079
in 3 · out 42 · cR 18872 · cW 162
$0.0005
114.3s
toolUse
robot_look
REACH korekta widoku: obróć kamerę w stronę klamki po zmianie yaw bazy; bez ruchu ramienia
ok
21,536
in 3 · out 148 · cR 19034 · cW 2351 · reason 52
$0.0011
122.1s
toolUse
robot_observe
REACH: ostatni świeży pomiar klamki po korekcie widoku
{"observation_id":"obs-6658f778-6-5993","session_id":"6658f778","time_s":11.986,"rgb_path":"/home/pawel/Documents/HomeB…
21,581
in 3 · out 37 · cR 21385 · cW 156
$0.0005
134.5s
toolUse
robot_execute_sequence
REACH: podejdź TCP do aktualnie zmierzonej klamki g_office jednym krótkim ruchem; zachowaj świeżą obserwację jako podstawę
ok · move_tcp · F=0.00N · grip=no
23,712
in 3 · out 153 · cR 8587 · cW 14969 · reason 46
$0.0041
142.6s
toolUse
robot_observe
Po REACH: sprawdź aktualny TCP, kontakt i stop przed grasp
{"observation_id":"obs-6658f778-7-8120","session_id":"6658f778","time_s":16.24,"rgb_path":"/home/pawel/Documents/HomeBo…
23,765
in 3 · out 35 · cR 23556 · cW 171
$0.0006
152.6s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_office przy aktualnym TCP; bez otwierania w tej samej komendzie
ok
25,788
in 3 · out 88 · cR 8587 · cW 17110
$0.0046
163.3s
toolUse
robot_observe
Po GRASP: sprawdź kontakt, chwyt drzwi i stop przed naciśnięciem
{"observation_id":"obs-6658f778-8-8170","session_id":"6658f778","time_s":16.34,"rgb_path":"/home/pawel/Documents/HomeBo…
26,000
in 3 · out 40 · cR 25697 · cW 260
$0.0006
172.6s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_office przed otwieraniem
ok
28,076
in 3 · out 76 · cR 8587 · cW 19410
$0.0051
182.2s
toolUse
robot_observe
Po PRESS: sprawdź zwolnienie zatrzasku, kontakt i brak stopu przed OPEN
{"observation_id":"obs-6658f778-9-8620","session_id":"6658f778","time_s":17.24,"rgb_path":"/home/pawel/Documents/HomeBo…
28,291
in 3 · out 40 · cR 27997 · cW 251
$0.0007
193.1s
toolUse
robot_door_action
OPEN: po potwierdzonym PRESS otwórz g_office; obserwuj wynik ruchu skrzydła i ewentualne clipped leaf
ok
30,361
in 3 · out 88 · cR 7184 · cW 23086
$0.0060
202.7s
toolUse
robot_observe
Po OPEN: potwierdź opening_progress, kontakt i aktualny TCP przed RELEASE
{"observation_id":"obs-6658f778-10-12964","session_id":"6658f778","time_s":25.928,"rgb_path":"/home/pawel/Documents/Hom…
30,566
in 3 · out 36 · cR 30270 · cW 257
$0.0007
214.0s
toolUse
robot_door_action
RELEASE: otwarcie potwierdzone (opening_progress_rad=-1.4546); zwolnij chwyt drzwi g_office przed wycofaniem
ok
33,634
in 3 · out 107 · cR 7184 · cW 26340 · reason 15
$0.0069
222.3s
toolUse
robot_observe
Po RELEASE: potwierdź door_grip=null, TCP i aktualny liść przed pierwszym waypointem retreat
{"observation_id":"obs-6658f778-11-13214","session_id":"6658f778","time_s":26.428,"rgb_path":"/home/pawel/Documents/Hom…
33,950
in 3 · out 43 · cR 33524 · cW 380
$0.0008
234.0s
toolUse
robot_execute_sequence
RETREAT 1/4: wykonaj dokładnie pierwszy suggested_retreat waypoint po release; jeden waypoint, bez skoku przez liść
ok · move_tcp · F=0.00N · grip=no
37,071
in 3 · out 142 · cR 7184 · cW 29742 · reason 46
$0.0078
242.7s
toolUse
robot_observe
Po retreat waypoint 1: sprawdź TCP, liść i stop przed waypointem 2
{"observation_id":"obs-6658f778-12-13436","session_id":"6658f778","time_s":26.872,"rgb_path":"/home/pawel/Documents/Hom…
37,127
in 3 · out 39 · cR 36926 · cW 159
$0.0008
254.2s
toolUse
robot_execute_sequence
RETREAT 2/4: po obserwacji wykonaj drugi waypoint suggested_retreat, nadal osobny krótki ruch TCP
ok · move_tcp · F=0.00N · grip=no
40,197
in 3 · out 124 · cR 7184 · cW 32886 · reason 29
$0.0085
262.4s
toolUse
robot_observe
Po retreat waypoint 2: sprawdź TCP, liść i stop przed waypointem 3
{"observation_id":"obs-6658f778-13-14237","session_id":"6658f778","time_s":28.474,"rgb_path":"/home/pawel/Documents/Hom…
40,270
in 3 · out 39 · cR 40070 · cW 158
$0.0009
273.8s
toolUse
robot_execute_sequence
RETREAT 3/4: wykonaj trzeci waypoint suggested_retreat po świeżej kontroli
ok · move_tcp · F=0.00N · grip=no
43,334
in 3 · out 126 · cR 7184 · cW 36021 · reason 38
$0.0093
282.4s
toolUse
robot_observe
Po retreat waypoint 3: sprawdź TCP, liść i stop przed końcowym stow waypointem
{"observation_id":"obs-6658f778-14-14931","session_id":"6658f778","time_s":29.862,"rgb_path":"/home/pawel/Documents/Hom…
43,401
in 3 · out 42 · cR 43205 · cW 151
$0.0010
296.3s
toolUse
robot_execute_sequence
RETREAT 4/4: końcowy waypoint suggested_retreat do pozycji stow, osobny ruch TCP; nadal bez jazdy
ok · move_tcp · F=0.00N · grip=no
46,476
in 3 · out 88 · cR 7184 · cW 39201
$0.010
302.9s
toolUse
robot_observe
Po pełnym RETREAT/STOW: potwierdź TCP stowed, xy norm<=0.10, z jazdowy, pusty chwytak, door_grip=null i stop=false przed opuszczeniem liftu
{"observation_id":"obs-6658f778-15-16385","session_id":"6658f778","time_s":32.77,"rgb_path":"/home/pawel/Documents/Home…
46,607
in 3 · out 66 · cR 46385 · cW 153
$0.0010
313.2s
toolUse
robot_move_lift
LOWER: ramię jest stowed, puste i bez chwytu drzwi; opuść lift do 0, bez jazdy
ok
49,652
in 3 · out 79 · cR 7184 · cW 42386
$0.011
325.3s
toolUse
robot_observe
Końcowa weryfikacja fazy 1: potwierdź otwarte g_office, postęp, stowed TCP, lift=0, door_grip=null i gotowość do jazdy; nie jedź
{"observation_id":"obs-6658f778-16-19719","session_id":"6658f778","time_s":39.438,"rgb_path":"/home/pawel/Documents/Hom…
49,764
in 3 · out 67 · cR 49570 · cW 124
$0.0011
337.5s
toolUse
mission_memory_write
Zapisz zweryfikowany postęp fazy 1 przed zakończeniem: obserwacje, drzwi, otwarcie, retreat, stow/lift; bez planowania przejazdu
{"revision":1,"kind":"agent_mission_notes","notes":"Phase 1 verified for g_office on ground / house_ground_v4. Capabili…
53,143
in 3 · out 408 · cR 7184 · cW 45548 · reason 33
$0.012
343.6s
stop
Drzwi `g_office` otwarte: `opening_progress_rad=-1.4546` (po release: `-1.4340`). Ramię bezpiecznie wycofane i schowane, chwyt pusty, `door_grip=null`, `lift_m=0`, `stop_latched=false`. Nie wykonano jazdy ani przekroc…
53,590
in 3 · out 124 · cR 52732 · cW 731
$0.0014
353.0s
toolUse
robot_observe
Sprawdź stan po fazie 1: lift, TCP stowed, door_grip, stop oraz lidar przed rozpoczęciem krótkiego przejazdu przez otwarte drzwi
{"observation_id":"obs-6658f778-17-19719","session_id":"6658f778","time_s":39.438,"rgb_path":"/home/pawel/Documents/Hom…
54,195
in 3 · out 71 · cR 53463 · cW 658 · reason 12
$0.0013
365.7s
toolUse
robot_move_base
CROSS krok 1 przez otwarte g_office: stan jest bezpieczny (lift=0, TCP stowed, door_grip=null); krótki ruch do przodu w osi lokalnej x, bez zmiany yaw
ok
57,451
in 3 · out 264 · cR 7184 · cW 50000 · reason 153
$0.013
375.3s
toolUse
robot_observe
Po CROSS krok 1: świeży lidar i otwór g_office przed następnym krótkim krokiem; sprawdź brak blokady
{"observation_id":"obs-6658f778-18-20719","session_id":"6658f778","time_s":41.438,"rgb_path":"/home/pawel/Documents/Hom…
57,447
in 3 · out 52 · cR 57184 · cW 208
$0.0013
383.5s
toolUse
robot_move_base
CROSS krok 2: po świeżym lidarze wykonaj kolejny krótki ruch do przodu przez g_office, nadal bez jazdy poza fazą celu
ok
60,515
in 3 · out 97 · cR 7184 · cW 53231
$0.014
393.7s
toolUse
robot_observe
Po CROSS krok 2: sprawdź położenie względem otwartego g_office, lidar i kandydatów drzwi; nie traktuj jeszcze przejścia jako zweryfikowanego
{"observation_id":"obs-6658f778-19-21719","session_id":"6658f778","time_s":43.438,"rgb_path":"/home/pawel/Documents/Hom…
60,675
in 3 · out 62 · cR 60415 · cW 195
$0.0013
404.6s
toolUse
robot_move_base
CROSS krok 3: świeży lidar wskazuje dalszą wolną trasę; wykonaj krótki krok 0.20 m, aby cały footprint minął pierwotny próg g_office
rejected
63,695
in 3 · out 156 · cR 7184 · cW 56352 · reason 48
$0.014
413.2s
toolUse
robot_observe
Recoverable base_path_blocked: świeża obserwacja po odrzuceniu; skrócę krok i wybiorę bezpieczniejszy pas na podstawie lidar
{"observation_id":"obs-6658f778-20-21719","session_id":"6658f778","time_s":43.438,"rgb_path":"/home/pawel/Documents/Hom…
63,771
in 3 · out 55 · cR 63536 · cW 177
$0.0014
427.3s
toolUse
robot_move_base
Replan po base_path_blocked: zmień pas boczny z dala od widocznego skrzydła g_office/g_wc, krótki ruch dy=+0.20, lift=0 i ramię stowed
rejected
67,057
in 3 · out 367 · cR 7184 · cW 59503 · reason 253
$0.015
433.7s
toolUse
robot_observe
Drugi miękki reject: ponownie odczytaj lidar i stan, bez resetu stopu; wybiorę krótką korektę yaw zamiast forsowania przejazdu
{"observation_id":"obs-6658f778-21-21719","session_id":"6658f778","time_s":43.438,"rgb_path":"/home/pawel/Documents/Hom…
66,957
in 3 · out 81 · cR 66687 · cW 186 · reason 21
$0.0015
444.7s
toolUse
robot_move_base
Replan po blokadach: obróć bazę o mały kąt +0.25 rad, aby zmienić obwiednię swept volume; bez forsowania translacji
ok
69,904
in 3 · out 103 · cR 7184 · cW 62614
$0.016
45881ms
error
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981319869218271
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039766359664054965
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039761293541438515
    }
  },
  "events": [],
  "sim_time_s": 44.808000000008796,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 1.7152930136106895e-38,
      "handle_angle_rad": -3.847839578496212e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -5.082472607345579e-09,
      "handle_angle_rad": 6.460864508694632e-20,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.641105564161354e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3983811997746702,
      "handle_angle_rad": 1.6324911336911917e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -4.738168337469004e-09,
      "handle_angle_rad": -3.916108302640851e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -4.738168337469004e-09,
      "handle_angle_rad": -3.916108302640851e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -5.082472607240996e-09,
      "handle_angle_rad": -6.182137722499362e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-phased-luna56-005

dom · homebot-dom · 2026-11-03 11:08 · homebot-dom/runs/omp-door-chain-phased-luna56-005
0/3 w koszu

MP4 · 1.1 MB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt62 calli · $0.372
ag. limity62 req · 28 seq · 60 tools
czas misji331.3s
status agentaError: 402 This request would exceed your available credits given your current in-flight requests. Retry after in-flight requests settle, or add credits. retry-after-ms=120000
calle LLM
62
tool calls
60
koszt zadania
$0.372
tokeny (sum)
3,041,497
in / out
183 / 7,349
cache R/W
1,719,831 / 1,314,134
czas modelu
225.5s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.4s
toolUse
robot_capabilities
DISCOVER: sprawdź wariant v4, podnośnik, ramy, limity i stan robota dla fazy otwarcia drzwi gabinetu
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć misji jako niezweryfikowane notatki; nie używaj jej geometrii do planowania
{"revision":0,"agent_notes":null}
7,869
in 3 · out 149 · cR 0 · cW 7717 · reason 31
$0.0021
22.1s
toolUse
robot_observe
SURVEY: świeża obserwacja startu przy g_office; zidentyfikuj widoczne zamknięte drzwi gabinetu, handle candidate, leaf, lidar i odometrię
{"observation_id":"obs-80125e5e-1-350","session_id":"80125e5e","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,670
in 3 · out 71 · cR 7717 · cW 879 · reason 7
$0.0005
33.1s
toolUse
robot_move_base
SWEEP_CHECK/hinge-clear: na podstawie świeżej obserwacji drzwi g_office i zachowując ramię schowane oraz lift=0, obróć bazę krótko w stronę zawiasu zgodnie z fazą
ok
11,296
in 3 · out 152 · cR 8596 · cW 2545 · reason 34
$0.0010
42.4s
toolUse
robot_observe
Potwierdź po hinge-clear: świeże lidar/RGB-D, brak stop latch, drzwi g_office, geometria uchwytu oraz bezpieczeństwo podniesienia kolumny
{"observation_id":"obs-80125e5e-2-1564","session_id":"80125e5e","time_s":3.128,"rgb_path":"/home/pawel/Documents/HomeBo…
11,410
in 3 · out 59 · cR 11141 · cW 207
$0.0003
54.0s
toolUse
robot_look
SURVEY uzupełniające: skieruj kamerę na widoczną klamkę g_office, aby uzyskać aktualny noisy handle candidate i potwierdzić sweep geometry
ok
14,082
in 3 · out 155 · cR 11348 · cW 2576 · reason 52
$0.0011
62.6s
toolUse
robot_observe
Po zmianie widoku potwierdź handle_candidate_m drzwi g_office i przygotowanie do liftu; nie wykonuj jeszcze manipulacji
{"observation_id":"obs-80125e5e-3-1783","session_id":"80125e5e","time_s":3.566,"rgb_path":"/home/pawel/Documents/HomeBo…
14,136
in 3 · out 49 · cR 13924 · cW 160
$0.0004
73.6s
toolUse
robot_move_lift
SWEEP_CHECK zakończony na podstawie trzech świeżych widoków; podnieś pustą, schowaną kolumnę do 0.40 m dla klamki ~1.05 m
ok
16,712
in 3 · out 136 · cR 14084 · cW 2489 · reason 35
$0.0011
82.7s
toolUse
robot_observe
REACH: po podniesieniu pobierz świeży handle_candidate_m w arm_carriage i potwierdź aktualny lift oraz brak blokady
{"observation_id":"obs-80125e5e-4-5117","session_id":"80125e5e","time_s":10.234,"rgb_path":"/home/pawel/Documents/HomeB…
16,772
in 3 · out 50 · cR 16573 · cW 146
$0.0004
94.8s
toolUse
robot_look
Klamka nie pojawiła się jawnie w ostatnim detektorze; wykonaj dodatkowy świeży look na stronę klamki przed REACH, bez ruchu ramienia
ok
19,419
in 3 · out 233 · cR 16719 · cW 2464 · reason 130
$0.0012
102.1s
toolUse
robot_observe
REACH: odczytaj po dodatkowym look aktualny punkt klamki g_office i stan kolumny
{"observation_id":"obs-80125e5e-5-5336","session_id":"80125e5e","time_s":10.672,"rgb_path":"/home/pawel/Documents/HomeB…
19,394
in 3 · out 43 · cR 19183 · cW 165
$0.0005
114.7s
toolUse
robot_look
Odzyskaj widoczność uchwytu: zmień kamerę na przeciwny kąt obserwacji g_office; bez żadnego ruchu arm/base
ok
20,986
in 3 · out 194 · cR 19348 · cW 1441 · reason 94
$0.0010
122.5s
toolUse
robot_observe
Sprawdź ponownie widoczny handle candidate po zmianie kąta; jeśli nadal brak jawnej klamki, nie wykonuj ślepego chwytu
{"observation_id":"obs-80125e5e-6-5930","session_id":"80125e5e","time_s":11.86,"rgb_path":"/home/pawel/Documents/HomeBo…
21,003
in 3 · out 53 · cR 20789 · cW 158
$0.0005
133.8s
toolUse
robot_execute_sequence
REACH: przesuń TCP dokładnie do świeżego handle_candidate_m g_office, jednym krótkim ruchem; nie chwytaj w tym samym skrypcie
ok · move_tcp · F=0.00N · grip=no
23,173
in 3 · out 145 · cR 8596 · cW 14429 · reason 37
$0.0040
142.9s
toolUse
robot_observe
Potwierdź pozycję TCP przy klamce g_office i brak kontaktu/stopu przed grasp
{"observation_id":"obs-80125e5e-7-8058","session_id":"80125e5e","time_s":16.116,"rgb_path":"/home/pawel/Documents/HomeB…
23,242
in 3 · out 43 · cR 23025 · cW 171
$0.0006
152.9s
toolUse
robot_door_action
GRASP: uchwyt g_office jest świeżo widoczny i TCP jest przy nim; chwyć drzwi
ok
25,388
in 3 · out 85 · cR 8596 · cW 16704
$0.0045
162.3s
toolUse
robot_observe
Potwierdź po grasp kontakt, force, door_grip i stop przed press
{"observation_id":"obs-80125e5e-8-8108","session_id":"80125e5e","time_s":16.216,"rgb_path":"/home/pawel/Documents/HomeB…
25,597
in 3 · out 36 · cR 25300 · cW 258
$0.0006
173.6s
toolUse
robot_door_action
PRESS: po potwierdzonym chwycie naciśnij sprężynową klamkę g_office
ok
27,774
in 3 · out 81 · cR 8596 · cW 19094
$0.0050
182.6s
toolUse
robot_observe
Potwierdź po press zwolnienie zatrzasku, kontakt i brak stopu przed open
{"observation_id":"obs-80125e5e-9-8558","session_id":"80125e5e","time_s":17.116,"rgb_path":"/home/pawel/Documents/HomeB…
27,990
in 3 · out 40 · cR 27690 · cW 257
$0.0007
192.8s
toolUse
robot_door_action
OPEN: po świeżym potwierdzeniu press otwórz drzwi g_office; zatrzymaj się tylko przy hard stopie, nie jedź przez próg
ok
30,162
in 3 · out 93 · cR 7184 · cW 22882
$0.0060
202.3s
toolUse
robot_observe
Potwierdź po OPEN postęp skrzydła, kontakt, stop oraz aktualny TCP; przygotuj RELEASE bez dalszego otwierania
{"observation_id":"obs-80125e5e-10-12902","session_id":"80125e5e","time_s":25.804,"rgb_path":"/home/pawel/Documents/Hom…
30,379
in 3 · out 49 · cR 30066 · cW 261
$0.0007
212.7s
toolUse
robot_door_action
RELEASE: drzwi g_office są otwarte na 1.4546 rad bez hard stopu; zwolnij chwyt przez door_action, bez jazdy
ok
33,411
in 3 · out 111 · cR 7184 · cW 26113 · reason 18
$0.0068
224.1s
toolUse
robot_observe
Po release potwierdź door_grip=null, otwarte skrzydło i aktualny TCP; przygotuj pierwszy waypoint retreat, bez skoku przez liść
{"observation_id":"obs-80125e5e-11-13152","session_id":"80125e5e","time_s":26.304,"rgb_path":"/home/pawel/Documents/Hom…
33,735
in 3 · out 53 · cR 33297 · cW 382
$0.0008
234.8s
toolUse
robot_execute_sequence
RETREAT 1/4: wykonaj wyłącznie pierwszy waypoint z suggested_retreat, aby odejść od skrzydła po zwolnieniu
ok · move_tcp · F=0.00N · grip=no
36,819
in 3 · out 170 · cR 7184 · cW 29462 · reason 68
$0.0077
244.8s
toolUse
robot_observe
Potwierdź po retreat waypoint 1 aktualny TCP, otwarte skrzydło, brak kontaktu i brak stopu przed waypointem 2
{"observation_id":"obs-80125e5e-12-13374","session_id":"80125e5e","time_s":26.748,"rgb_path":"/home/pawel/Documents/Hom…
36,865
in 3 · out 51 · cR 36646 · cW 165
$0.0008
253.1s
toolUse
robot_execute_sequence
RETREAT 2/4: wykonaj drugi waypoint z wyniku release, po świeżej obserwacji i bez łączenia punktów
ok · move_tcp · F=0.00N · grip=no
39,864
in 3 · out 96 · cR 7184 · cW 32581
$0.0084
262.3s
toolUse
robot_observe
Potwierdź po retreat waypoint 2 stan TCP i skrzydła przed waypointem 3
{"observation_id":"obs-80125e5e-13-14175","session_id":"80125e5e","time_s":28.35,"rgb_path":"/home/pawel/Documents/Home…
39,969
in 3 · out 40 · cR 39765 · cW 161
$0.0009
272.9s
toolUse
robot_execute_sequence
RETREAT 3/4: wykonaj trzeci waypoint suggested_retreat po świeżej obserwacji
ok · move_tcp · F=0.00N · grip=no
43,099
in 3 · out 88 · cR 7184 · cW 35824
$0.0092
282.8s
toolUse
robot_observe
Potwierdź po retreat waypoint 3 stan i brak kolizji przed ostatnim stow waypointem
{"observation_id":"obs-80125e5e-14-14869","session_id":"80125e5e","time_s":29.738,"rgb_path":"/home/pawel/Documents/Hom…
43,205
in 3 · out 41 · cR 43008 · cW 153
$0.0009
294.1s
toolUse
robot_execute_sequence
RETREAT 4/4 i STOW: po obserwacji wykonaj ostatni waypoint suggested_retreat do pozycji stow, bez przejazdu
ok · move_tcp · F=0.00N · grip=no
46,335
in 3 · out 139 · cR 7184 · cW 39009 · reason 45
$0.010
302.5s
toolUse
robot_observe
Potwierdź końcowe stow TCP, pusty chwytak, door_grip=null i brak stopu przed obniżeniem liftu
{"observation_id":"obs-80125e5e-15-16323","session_id":"80125e5e","time_s":32.646,"rgb_path":"/home/pawel/Documents/Hom…
46,405
in 3 · out 52 · cR 46193 · cW 157
$0.0010
313.0s
toolUse
robot_move_lift
LOWER: ramię jest stowed, puste i bez door_grip; opuść kolumnę do 0 przed gotowością do jazdy. Nie wykonuj przejazdu
ok
49,481
in 3 · out 109 · cR 7184 · cW 42185 · reason 16
$0.011
322.8s
toolUse
robot_observe
VERIFY końca fazy: potwierdź lift=0, arm stowed, TCP drive-safe, door_grip=null, stop_latched=false i opening_progress g_office
{"observation_id":"obs-80125e5e-16-19657","session_id":"80125e5e","time_s":39.314,"rgb_path":"/home/pawel/Documents/Hom…
49,564
in 3 · out 56 · cR 49369 · cW 136
$0.0011
334.4s
stop
PHASE_COMPLETE g_office otwarte: opening_progress_rad ≈ -1.434; ramię wycofane i schowane, lift=0, TCP drive-safe, door_grip=null, stop_latched=false. Końcowa obserwacja: obs-80125e5e-16-19657. Przejazdu nie wykonano.
52,738
in 3 · out 163 · cR 7184 · cW 45388 · reason 81
$0.012
343.6s
toolUse
robot_observe
FAZA 2 start: świeżo sprawdź lift, TCP/stow, door_grip, próg otwartych g_office, lidar i widoczne inne drzwi
{"observation_id":"obs-80125e5e-17-19657","session_id":"80125e5e","time_s":39.314,"rgb_path":"/home/pawel/Documents/Hom…
53,342
in 3 · out 153 · cR 52572 · cW 614 · reason 92
$0.0014
356.4s
toolUse
robot_move_base
CROSS 1: lift=0, ramię stowed i puste; wykonaj krótki krok dx=0.18 w stronę obserwowanego otworu g_office, bez forsowania progu
ok
56,542
in 3 · out 333 · cR 7184 · cW 49022 · reason 222
$0.013
363.2s
toolUse
robot_observe
VERIFY/CROSS: po pierwszym kroku sprawdź signed distance do pierwotnej płaszczyzny g_office, lidar, przeszkody i inne drzwi; nie zakładaj jeszcze przekroczenia
{"observation_id":"obs-80125e5e-18-20606","session_id":"80125e5e","time_s":41.212,"rgb_path":"/home/pawel/Documents/Hom…
56,480
in 3 · out 65 · cR 56206 · cW 206
$0.0013
374.8s
toolUse
robot_move_base
CROSS 2: lidar po obserwacji wskazuje przejście; wykonaj kolejny krótki krok dx=0.20 przez otwór, nadal bez manipulacji drzwiami
ok
59,522
in 3 · out 164 · cR 7184 · cW 52171 · reason 59
$0.013
383.0s
toolUse
robot_observe
VERIFY po drugim kroku: sprawdź przekroczenie pierwotnej płaszczyzny g_office, bieżące otoczenie i widoczne inne klamki
{"observation_id":"obs-80125e5e-19-21606","session_id":"80125e5e","time_s":43.212,"rgb_path":"/home/pawel/Documents/Hom…
59,616
in 3 · out 58 · cR 59355 · cW 200
$0.0013
394.5s
toolUse
robot_look
W nowym pomieszczeniu wykonaj mały obrót kamery, aby przesurveyować g_wc i poszukać widocznej klamki innego door_id; bez manipulacji
ok
62,775
in 3 · out 226 · cR 7184 · cW 55362 · reason 122
$0.014
402.6s
toolUse
robot_observe
Znajdź po nowym widoku handle_candidate_m dla drzwi innego niż g_office; potwierdź przekroczenie i bezpieczny stan bazy
{"observation_id":"obs-80125e5e-20-21981","session_id":"80125e5e","time_s":43.962,"rgb_path":"/home/pawel/Documents/Hom…
62,764
in 3 · out 55 · cR 62546 · cW 160
$0.0014
414.8s
toolUse
robot_look
Poszukaj INNYCH drzwi w nowym pomieszczeniu: obróć kamerę w stronę g_wc/ścian bocznych, bez manipulacji i bez jazdy
ok
64,864
in 3 · out 170 · cR 7184 · cW 57507 · reason 67
$0.015
422.6s
toolUse
robot_observe
Odczytaj po nowym widoku wszystkie wykryte drzwi i klamki; wybierz door_id różny od g_office
{"observation_id":"obs-80125e5e-21-22763","session_id":"80125e5e","time_s":45.526,"rgb_path":"/home/pawel/Documents/Hom…
64,903
in 3 · out 49 · cR 64691 · cW 160
$0.0014
435.5s
toolUse
robot_move_base
APPROACH g_wc 1: świeży lidar, lift=0 i ramię stowed; skróć dystans do widocznej klamki g_wc krótkim krokiem w kierunku jej obserwowanego arm_carriage xy
ok
68,267
in 3 · out 263 · cR 7184 · cW 60817 · reason 142
$0.016
442.8s
toolUse
robot_observe
VERIFY podejścia: potwierdź świeży lidar, stow/lift=0, widoczność klamki g_wc i bezpieczną pozycję hinge-clear; nadal bez door_action
{"observation_id":"obs-80125e5e-22-23953","session_id":"80125e5e","time_s":47.906,"rgb_path":"/home/pawel/Documents/Hom…
68,285
in 3 · out 62 · cR 68001 · cW 219
$0.0015
455.1s
toolUse
robot_move_base
APPROACH g_wc 2: po świeżym lidarze skróć dystans do g_wc małym krokiem 0.15 m w kierunku drzwi; nadal lift=0, ramię stowed, bez door_action
ok
71,612
in 3 · out 287 · cR 7184 · cW 64138 · reason 168
$0.017
462.7s
toolUse
robot_observe
Koniec fazy: zweryfikuj świeżym observe pozycję hinge-clear, widoczną klamkę g_wc, lift=0, ramię stowed, door_grip=null i stop_latched=false
{"observation_id":"obs-80125e5e-23-24983","session_id":"80125e5e","time_s":49.966,"rgb_path":"/home/pawel/Documents/Hom…
71,609
in 3 · out 66 · cR 71322 · cW 218
$0.0016
475.1s
stop
PHASE_COMPLETE Przekroczono próg przez g_office. Zidentyfikowano inne drzwi: **g_wc**; klamka widoczna, handle_candidate_m ≈ [0.911, −0.732, 1.052]. Robot zatrzymany w pozycji podejścia, lift=0, ramię schowane, door_g…
74,888
in 3 · out 191 · cR 7184 · cW 67510 · reason 71
$0.017
483.9s
toolUse
robot_observe
FAZA 3 start/SURVEY: świeżo sprawdź stan robota i drzwi g_wc, handle candidate, lift, TCP, lidar oraz stop latch
{"observation_id":"obs-80125e5e-24-24983","session_id":"80125e5e","time_s":49.966,"rgb_path":"/home/pawel/Documents/Hom…
75,243
in 3 · out 69 · cR 74694 · cW 477 · reason 13
$0.0017
496.1s
toolUse
robot_move_base
SWEEP_CHECK/hinge-clear: g_wc uchwyt jest poza bezpiecznym TCP xy; przy opuszczonym lift i schowanym ramieniu wykonaj małą korektę bazy w stronę klamki, bez manipulacji drzwiami
ok
78,693
in 3 · out 323 · cR 7184 · cW 71183 · reason 197
$0.018
503.1s
toolUse
robot_observe
Po hinge-clear odśwież obserwację g_wc: handle_candidate_m, lidar i potwierdź lift=0, arm stowed, stop=false przed liftem
{"observation_id":"obs-80125e5e-25-25833","session_id":"80125e5e","time_s":51.666,"rgb_path":"/home/pawel/Documents/Hom…
78,657
in 3 · out 55 · cR 78367 · cW 232
$0.0017
516.0s
toolUse
robot_move_base
REACH przygotowanie: świeży candidate g_wc ma y=-0.764 poza limitem; wykonaj krótką korektę stowed/lift=0 w stronę większego standoffu, aby cały uchwyt wejść w workspace
ok
81,883
in 3 · out 303 · cR 7184 · cW 74393 · reason 186
$0.019
523.0s
toolUse
robot_observe
Po korekcie potwierdź aktualny candidate g_wc, lidar i że lift=0/stow/stop=false przed podniesieniem
{"observation_id":"obs-80125e5e-26-26541","session_id":"80125e5e","time_s":53.082,"rgb_path":"/home/pawel/Documents/Hom…
81,844
in 3 · out 49 · cR 81577 · cW 215
$0.0017
535.3s
toolUse
robot_move_base
REACH korekta: świeży candidate g_wc ma y=-0.863 poza workspace; przy lift=0 i stowed przesuń bazę krótkim krokiem w przeciwną stronę, aby uchwyt wejść z marginesem
ok
84,292
in 3 · out 203 · cR 7184 · cW 76902 · reason 84
$0.020
543.0s
toolUse
robot_observe
Po korekcie odśwież g_wc handle_candidate_m, lidar oraz stan robota przed liftem; nie zgaduj punktu
{"observation_id":"obs-80125e5e-27-27490","session_id":"80125e5e","time_s":54.98,"rgb_path":"/home/pawel/Documents/Home…
84,354
in 3 · out 48 · cR 84086 · cW 217
$0.0018
554.6s
toolUse
robot_move_lift
Po świeżym candidate g_wc [0.6832,-0.6847,1.0519] podnieś pustą schowaną kolumnę do 0.40 m; nie wykonuj jeszcze chwytu
ok
87,016
in 3 · out 121 · cR 7184 · cW 79708 · reason 19
$0.020
562.8s
toolUse
robot_observe
REACH po lifcie: odśwież handle_candidate_m g_wc w arm_carriage i sprawdź stop/contact przed ruchem TCP
{"observation_id":"obs-80125e5e-28-30824","session_id":"80125e5e","time_s":61.648,"rgb_path":"/home/pawel/Documents/Hom…
87,090
in 3 · out 48 · cR 86892 · cW 147
$0.0018
573.2s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego handle_candidate_m g_wc jednym ruchem, bez chwytu w tym skrypcie
rejected
89,724
in 3 · out 115 · cR 7184 · cW 82422 · reason 17
$0.021
585.2s
toolUse
robot_observe
Po odrzuceniu workspace_limit nie kontynuuj ślepo: odśwież stan, potwierdź brak chwytu i lift przed korektą pozycji
{"observation_id":"obs-80125e5e-29-30824","session_id":"80125e5e","time_s":61.648,"rgb_path":"/home/pawel/Documents/Hom…
89,937
in 3 · out 209 · cR 89606 · cW 119 · reason 152
$0.0021
597.1s
toolUse
robot_move_lift
Po workspace_limit: zgodnie z procedurą opuść lift do 0 przy pustym, schowanym ramieniu; następnie będzie możliwa kolejna krótka korekta bazy
ok
92,511
in 3 · out 209 · cR 7184 · cW 85115 · reason 112
$0.022
603.0s
toolUse
robot_observe
Po lower odśwież candidate g_wc i lidar do bezpiecznej korekty bazy; nie wykonuj chwytu ani TCP do czasu osiągnięcia zasięgu
{"observation_id":"obs-80125e5e-30-34158","session_id":"80125e5e","time_s":68.316,"rgb_path":"/home/pawel/Documents/Hom…
92,501
in 3 · out 57 · cR 92299 · cW 142
$0.0020
616.2s
toolUse
robot_move_base
REACH korekta końcowa: candidate g_wc ma y=-0.6845, minimalnie poza limitem; przy lift=0 i stowed wykonaj bardzo krótki krok dy=-0.03, potem ponownie zmierz
ok
95,339
in 3 · out 313 · cR 7184 · cW 87839 · reason 197
$0.022
62757ms
error
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981362307876331
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039768182634240465
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976029726254542
    }
  },
  "events": [],
  "sim_time_s": 69.09200000002038,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": -5.938910799029982e-39,
      "handle_angle_rad": -2.77074148651077e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -8.496145344660982e-09,
      "handle_angle_rad": 3.0012125296206997e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -7.818123113940756e-19,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.398220527019469,
      "handle_angle_rad": 1.0229168431062885e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -7.920587954022744e-09,
      "handle_angle_rad": -2.2304795336188768e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -7.920587954022744e-09,
      "handle_angle_rad": -2.2304795336188768e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -8.49614534440654e-09,
      "handle_angle_rad": -4.329162908329897e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-phased-luna56-003

dom · homebot-dom · 2026-11-03 10:59 · homebot-dom/runs/omp-door-chain-phased-luna56-003
0/3 w koszu

MP4 · 1.0 MB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt85 calli · $0.559
ag. limity84 req · 40 seq · 84 tools
czas misji464.0s
status agentarobot_stop_latched
calle LLM
85
tool calls
84
koszt zadania
$0.559
tokeny (sum)
4,740,230
in / out
252 / 9,628
cache R/W
2,761,575 / 1,968,775
czas modelu
282.9s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.0s
toolUse
robot_capabilities
DISCOVER: sprawdź pełne możliwości MCPv4, lift, limity, ramę i podłogę
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj bieżącą pamięć misji; traktuj notatki jako niezweryfikowane
{"revision":0,"agent_notes":null}
robot_observe
SURVEY: świeża obserwacja RGB-D/lidar/siły, widoczne drzwi gabinetu i klamka przy starcie g_office
{"observation_id":"obs-023062a8-1-350","session_id":"023062a8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
7,907
in 3 · out 188 · cR 0 · cW 7716 · reason 38
$0.0022
23.8s
toolUse
robot_look
SURVEY dodatkowy: ustaw kamerę na widoczną klamkę drzwi g_office, bez ruchu bazy/ramienia
ok
11,273
in 3 · out 166 · cR 7716 · cW 3388 · reason 77
$0.0012
31.9s
toolUse
robot_observe
SURVEY po zmianie widoku: zmierz aktualnie widoczną klamkę, zawias, płaszczyznę i łuk drzwi g_office; sprawdź stop i lidar
{"observation_id":"obs-023062a8-2-632","session_id":"023062a8","time_s":1.264,"rgb_path":"/home/pawel/Documents/HomeBot…
11,313
in 3 · out 62 · cR 11104 · cW 144
$0.0003
43.7s
toolUse
robot_move_base
SWEEP_CHECK zakończony na podstawie wielokrotnych punktów widocznego skrzydła i klamki; ustaw hinge-clear, ramię stowed, lift=0, yaw w stronę zawiasu
ok
13,932
in 3 · out 141 · cR 11248 · cW 2540 · reason 29
$0.0010
52.3s
toolUse
robot_observe
Po hinge-clear: sprawdź aktualny standoff, lidar, drzwi g_office i bezpieczeństwo łuku przed podniesieniem liftu
{"observation_id":"obs-023062a8-3-1846","session_id":"023062a8","time_s":3.692,"rgb_path":"/home/pawel/Documents/HomeBo…
14,041
in 3 · out 50 · cR 13788 · cW 200
$0.0004
64.7s
toolUse
robot_move_lift
Podnieś pustą, schowaną kolumnę do 0.40 m po potwierdzeniu SWEEP_CHECK i hinge-clear
ok
16,540
in 3 · out 125 · cR 13988 · cW 2424 · reason 43
$0.0010
71.9s
toolUse
robot_observe
REACH: po podniesieniu ponownie zmierz aktualną handle_candidate_m g_office i stan bezpieczeństwa
{"observation_id":"obs-023062a8-4-5180","session_id":"023062a8","time_s":10.36,"rgb_path":"/home/pawel/Documents/HomeBo…
16,584
in 3 · out 43 · cR 16412 · cW 126
$0.0004
85.5s
toolUse
robot_look
REACH: skieruj kamerę ponownie na klamkę po podniesieniu liftu, aby uzyskać świeży handle_candidate_m
ok
19,201
in 3 · out 195 · cR 16538 · cW 2465 · reason 104
$0.0012
91.9s
toolUse
robot_observe
Świeża obserwacja klamki po zmianie kamery; potwierdź handle_candidate_m i brak zatrzymania
{"observation_id":"obs-023062a8-5-5274","session_id":"023062a8","time_s":10.548,"rgb_path":"/home/pawel/Documents/HomeB…
19,198
in 3 · out 46 · cR 19003 · cW 146
$0.0005
104.6s
toolUse
robot_look
REACH korekta: zmień pan na 0.0 i tilt -0.15, aby odzyskać widoczną klamkę po lift=0.40
ok
21,573
in 3 · out 134 · cR 19149 · cW 2287 · reason 37
$0.0011
112.0s
toolUse
robot_observe
Potwierdź świeżą klamkę g_office po korekcie widoku; nie wykonuj ruchu ramienia bez kandydata
{"observation_id":"obs-023062a8-6-5493","session_id":"023062a8","time_s":10.986,"rgb_path":"/home/pawel/Documents/HomeB…
21,636
in 3 · out 49 · cR 21436 · cW 148
$0.0005
124.0s
toolUse
robot_look
Ponów survey klamki z innego kąta po lift=0.40; potrzebny świeży widoczny kandydat przed REACH
ok
23,637
in 3 · out 174 · cR 7716 · cW 15744 · reason 83
$0.0043
132.8s
toolUse
robot_observe
Sprawdź widoczność klamki po kolejnym kącie kamery; tylko świeże dane RGB-D
{"observation_id":"obs-023062a8-7-5931","session_id":"023062a8","time_s":11.862,"rgb_path":"/home/pawel/Documents/HomeB…
23,651
in 3 · out 43 · cR 23460 · cW 145
$0.0006
144.8s
toolUse
robot_look
Odzyskaj widok g_office po obrocie bazy: kamera w stronę drzwi, bez ruchu robota
ok
24,713
in 3 · out 201 · cR 7716 · cW 16793 · reason 111
$0.0046
152.2s
toolUse
robot_observe
Końcowy survey po zmianie pan/tilt: znajdź widoczną klamkę g_office i jej aktualny kandydat
{"observation_id":"obs-023062a8-8-6806","session_id":"023062a8","time_s":13.612,"rgb_path":"/home/pawel/Documents/HomeB…
24,708
in 3 · out 50 · cR 24509 · cW 146
$0.0006
165.1s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego kandydata klamki g_office w arm_carriage; pojedynczy ruch, bez chwytu
ok · move_tcp · F=0.00N · grip=no
26,829
in 3 · out 178 · cR 7716 · cW 18932 · reason 78
$0.0051
172.0s
toolUse
robot_observe
Po REACH: potwierdź TCP, kontakt i stop przed grasp
{"observation_id":"obs-023062a8-9-8934","session_id":"023062a8","time_s":17.868,"rgb_path":"/home/pawel/Documents/HomeB…
26,847
in 3 · out 34 · cR 26648 · cW 162
$0.0006
182.1s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_office z aktualnego TCP
ok
28,870
in 3 · out 75 · cR 7186 · cW 21606
$0.0056
192.4s
toolUse
robot_observe
Po grasp: potwierdź grip_contact, TCP i brak stopu przed press
{"observation_id":"obs-023062a8-10-8984","session_id":"023062a8","time_s":17.968,"rgb_path":"/home/pawel/Documents/Home…
29,074
in 3 · out 36 · cR 28792 · cW 243
$0.0007
202.7s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_office przed otwieraniem
ok
31,102
in 3 · out 74 · cR 7186 · cW 23839
$0.0062
212.2s
toolUse
robot_observe
Po press: potwierdź zwolnienie zatrzasku przez stan kontaktu i brak stopu przed open
{"observation_id":"obs-023062a8-11-9434","session_id":"023062a8","time_s":18.868,"rgb_path":"/home/pawel/Documents/Home…
31,320
in 3 · out 43 · cR 31025 · cW 249
$0.0007
225.3s
toolUse
robot_door_action
OPEN: po potwierdzonym press otwórz fizycznie drzwi g_office, monitorując limit i siłę
ok
33,337
in 3 · out 81 · cR 7186 · cW 26067
$0.0068
232.0s
toolUse
robot_observe
Po OPEN: potwierdź opening_progress, otwarte skrzydło, kontakt i brak stopu przed release
{"observation_id":"obs-023062a8-12-13778","session_id":"023062a8","time_s":27.556,"rgb_path":"/home/pawel/Documents/Hom…
33,551
in 3 · out 43 · cR 33253 · cW 252
$0.0008
243.5s
toolUse
robot_door_action
RELEASE: otwarte drzwi są potwierdzone; zwolnij chwyt g_office przed planowanym odwrotem
ok
35,768
in 3 · out 101 · cR 7186 · cW 28478 · reason 17
$0.0074
252.2s
toolUse
robot_observe
Po release: obserwuj otwarte skrzydło, TCP i aktualne przeszkody przed pierwszym waypointem odwrotu
{"observation_id":"obs-023062a8-13-14028","session_id":"023062a8","time_s":28.056,"rgb_path":"/home/pawel/Documents/Hom…
36,087
in 3 · out 47 · cR 35664 · cW 373
$0.0009
264.5s
toolUse
robot_execute_sequence
RETREAT 1/4: wykonaj dokładnie pierwszy waypoint suggested_retreat, jeden ruch TCP, z dala od skrzydła
ok · move_tcp · F=0.00N · grip=no
38,316
in 3 · out 147 · cR 7186 · cW 30980 · reason 52
$0.0081
272.2s
toolUse
robot_observe
Po retreat waypoint 1: sprawdź TCP i ponownie obserwuj skrzydło/clearance przed waypointem 2
{"observation_id":"obs-023062a8-14-14250","session_id":"023062a8","time_s":28.5,"rgb_path":"/home/pawel/Documents/HomeB…
38,373
in 3 · out 47 · cR 38166 · cW 157
$0.0009
283.6s
toolUse
robot_execute_sequence
RETREAT 2/4: wykonaj drugi waypoint z release, po świeżej obserwacji i bez skoku przez skrzydło
ok · move_tcp · F=0.00N · grip=no
40,529
in 3 · out 114 · cR 7186 · cW 33226 · reason 18
$0.0086
292.7s
toolUse
robot_observe
Po retreat waypoint 2: sprawdź TCP, otwarte skrzydło i stop przed waypointem 3
{"observation_id":"obs-023062a8-15-15051","session_id":"023062a8","time_s":30.102,"rgb_path":"/home/pawel/Documents/Hom…
40,616
in 3 · out 43 · cR 40412 · cW 158
$0.0009
303.0s
toolUse
robot_execute_sequence
RETREAT 3/4: wykonaj trzeci waypoint suggested_retreat po obserwacji, nadal pojedynczy ruch TCP
ok · move_tcp · F=0.00N · grip=no
42,802
in 3 · out 91 · cR 7186 · cW 35522
$0.0091
311.9s
toolUse
robot_observe
Po retreat waypoint 3: sprawdź TCP i stop przed końcowym stowaniem
{"observation_id":"obs-023062a8-16-15745","session_id":"023062a8","time_s":31.49,"rgb_path":"/home/pawel/Documents/Home…
42,904
in 3 · out 38 · cR 42708 · cW 155
$0.0009
322.5s
toolUse
robot_execute_sequence
RETREAT 4/4: wykonaj końcowy waypoint z release i stowaj ramię zgodnie z kolejnością, bez przejazdu
ok · move_tcp · F=0.00N · grip=no
45,064
in 3 · out 89 · cR 7186 · cW 37786
$0.0097
332.1s
toolUse
robot_observe
Po stow: potwierdź TCP stowed, pusty chwytak, door_grip=null i stop=false przed opuszczeniem liftu
{"observation_id":"obs-023062a8-17-17199","session_id":"023062a8","time_s":34.398,"rgb_path":"/home/pawel/Documents/Hom…
45,178
in 3 · out 50 · cR 44972 · cW 153
$0.0010
342.5s
toolUse
robot_move_lift
LOWER: ramię jest stowed, chwyt pusty i door_grip=null; opuść lift do 0 bez jazdy
ok
47,347
in 3 · out 79 · cR 7186 · cW 40079
$0.010
352.6s
toolUse
robot_observe
Końcowa weryfikacja fazy: potwierdź lift=0, TCP stowed w granicach jazdy, door_grip=null, drzwi otwarte i stop=false; nie jedź
{"observation_id":"obs-023062a8-18-20533","session_id":"023062a8","time_s":41.066,"rgb_path":"/home/pawel/Documents/Hom…
47,455
in 3 · out 63 · cR 47265 · cW 124
$0.0011
365.4s
toolUse
mission_memory_write
Zapisz obserwowane dowody fazy 1: g_office otwarte, postęp, retreat wykonany, ramię stowed, lift opuszczony; bez przejazdu
{"revision":1,"kind":"agent_mission_notes","notes":"Phase 1 evidence: floor house_ground_v4, door g_office. Fresh surve…
49,809
in 3 · out 259 · cR 7186 · cW 42361 · reason 44
$0.011
372.9s
stop
PHASE_COMPLETE — g_office otwarte (opening_progress_rad=-1.4546), ramię bezpiecznie wycofane i schowane, lift=0, chwyt pusty, bez jazdy. observation_id: obs-023062a8-18-20533
50,056
in 3 · out 93 · cR 49547 · cW 413 · reason 28
$0.0012
382.6s
toolUse
robot_observe
FAZA 2 start: sprawdź lift, TCP stowed, door_grip, stop, otwarte g_office i lidar przed CROSS
{"observation_id":"obs-023062a8-19-20533","session_id":"023062a8","time_s":41.066,"rgb_path":"/home/pawel/Documents/Hom…
50,620
in 3 · out 63 · cR 49960 · cW 594 · reason 12
$0.0012
394.3s
toolUse
robot_move_base
CROSS krok 1: lift=0, ramię stowed, chwyt pusty; krótki przejazd 0.20 m w osi otwartego przejścia, na podstawie świeżego lidaru
ok
52,885
in 3 · out 247 · cR 7186 · cW 45449 · reason 137
$0.012
402.4s
toolUse
robot_observe
CROSS po kroku 1: świeży lidar, signed-distance względem obserwowanego progu g_office i wyszukiwanie innych drzwi; bez ruchu w ciemno
{"observation_id":"obs-023062a8-20-21533","session_id":"023062a8","time_s":43.066,"rgb_path":"/home/pawel/Documents/Hom…
52,904
in 3 · out 60 · cR 52635 · cW 206
$0.0012
413.9s
toolUse
robot_move_base
CROSS krok 2: świeży lidar pokazuje przejście; kontynuuj krótko 0.20 m tym samym bezpiecznym kierunkiem, bez arm/door action
ok
55,319
in 3 · out 207 · cR 7186 · cW 47923 · reason 103
$0.012
422.4s
toolUse
robot_observe
VERIFY CROSS: świeża obserwacja progu g_office, stop/lift/TCP; potwierdź całkowite przekroczenie zanim ruszysz ku innym drzwiom
{"observation_id":"obs-023062a8-21-22533","session_id":"023062a8","time_s":45.066,"rgb_path":"/home/pawel/Documents/Hom…
55,370
in 3 · out 59 · cR 55109 · cW 199
$0.0012
435.2s
toolUse
robot_move_base
Podejście do innych drzwi g_wc: krótki krok w stronę świeżo widocznej klamki, ramię stowed/lift=0; bez door_action
ok
59,311
in 3 · out 297 · cR 7186 · cW 51825 · reason 191
$0.013
444.3s
toolUse
robot_observe
Podejście g_wc po kroku: świeży handle_candidate_m, odległość i geometria; zatrzymaj się bez chwytania
{"observation_id":"obs-023062a8-22-23723","session_id":"023062a8","time_s":47.446,"rgb_path":"/home/pawel/Documents/Hom…
59,266
in 3 · out 49 · cR 59011 · cW 203
$0.0013
455.1s
toolUse
robot_move_base
Podejdź bliżej do g_wc krótkim krokiem, utrzymując ramię stowed/lift=0; świeży lidar wskazuje wolny pas, bez door_action
ok
61,678
in 3 · out 268 · cR 7186 · cW 54221 · reason 163
$0.014
462.2s
toolUse
robot_observe
Końcowa obserwacja podejścia do innych drzwi: potwierdź g_wc jako kolejny door_id, świeży handle_candidate_m, stowed/lift=0; nie chwytaj
{"observation_id":"obs-023062a8-23-24806","session_id":"023062a8","time_s":49.612,"rgb_path":"/home/pawel/Documents/Hom…
61,674
in 3 · out 62 · cR 61407 · cW 202
$0.0014
478.3s
toolUse
robot_move_base
Dopasuj hinge-clear przy g_wc: krótki krok dy=-0.08 w stronę klamki, lift=0 i ramię stowed; nie chwytaj
ok
64,039
in 3 · out 442 · cR 7186 · cW 56408 · reason 338
$0.015
482.3s
toolUse
robot_observe
Final VERIFY fazy 2: potwierdź g_wc jako inne drzwi, świeży handle_candidate_m, pozycję hinge-clear, lift=0, stowed, bez door_action
{"observation_id":"obs-023062a8-24-25439","session_id":"023062a8","time_s":50.878,"rgb_path":"/home/pawel/Documents/Hom…
63,858
in 3 · out 59 · cR 63594 · cW 202
$0.0014
494.7s
toolUse
mission_memory_write
Zapisz dowody fazy 2: przekroczenie g_office, podejście do innego g_wc, końcowa pozycja stowed/lift=0, bez door_action
{"revision":2,"kind":"agent_mission_notes","notes":"Phase 2 evidence: from final phase1 pose, crossed the open g_office…
66,132
in 3 · out 295 · cR 7186 · cW 58648 · reason 44
$0.015
503.3s
stop
PHASE_COMPLETE — przekroczono próg przez g_office i podejście zakończone przy innych drzwiach. Kandydat drzwi 2: `g_wc`, `handle_candidate_m=[0.8593,-0.6544,1.0518]`; ramię schowane, lift=0, bez chwytu i bez `door_actio…
66,419
in 3 · out 99 · cR 65834 · cW 483
$0.0016
513.8s
toolUse
robot_observe
FAZA 3 start: świeża obserwacja g_wc, sprawdź lift=0, ramię stowed, stop, klamkę i skrzydło przed SWEEP_CHECK
{"observation_id":"obs-023062a8-25-25439","session_id":"023062a8","time_s":50.878,"rgb_path":"/home/pawel/Documents/Hom…
66,816
in 3 · out 125 · cR 66317 · cW 371 · reason 64
$0.0016
523.1s
toolUse
robot_move_base
SWEEP_CHECK/hinge-clear: wykonaj mały obrót bazy w stronę zawiasu g_wc, ramię stowed i lift=0; zachowaj bezpieczny standoff
ok
68,854
in 3 · out 105 · cR 7186 · cW 61560
$0.016
532.9s
toolUse
robot_observe
Po hinge-clear: świeże sprawdzenie skrzydła g_wc, klamki, standoffu i łuku przed podniesieniem liftu
{"observation_id":"obs-023062a8-26-26124","session_id":"023062a8","time_s":52.248,"rgb_path":"/home/pawel/Documents/Hom…
69,002
in 3 · out 52 · cR 68746 · cW 201
$0.0015
542.9s
toolUse
robot_move_lift
Podnieś pustą, stowed kolumnę do 0.40 m po potwierdzonym SWEEP_CHECK dla g_wc
ok
70,999
in 3 · out 79 · cR 7186 · cW 63731
$0.016
552.5s
toolUse
robot_observe
REACH: po podniesieniu liftu odczytaj świeży handle_candidate_m g_wc i potwierdź stop=false
{"observation_id":"obs-023062a8-27-29458","session_id":"023062a8","time_s":58.916,"rgb_path":"/home/pawel/Documents/Hom…
71,091
in 3 · out 46 · cR 70917 · cW 125
$0.0015
563.2s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego kandydata klamki g_wc w arm_carriage, pojedynczy ruch
rejected
73,135
in 3 · out 114 · cR 7186 · cW 65832 · reason 19
$0.017
574.2s
toolUse
robot_move_lift
REACH odrzucony przez workspace_limit; przerwij próbę, opuść pusty stowed lift przed korektą bazy
ok
73,360
in 3 · out 223 · cR 73018 · cW 116 · reason 140
$0.0018
584.5s
toolUse
robot_observe
Po odrzuceniu workspace_limit: świeża obserwacja po opuszczeniu liftu; zaplanuj korektę bazy bez chwytu drzwi
{"observation_id":"obs-023062a8-28-32792","session_id":"023062a8","time_s":65.584,"rgb_path":"/home/pawel/Documents/Hom…
73,468
in 3 · out 204 · cR 73134 · cW 127 · reason 149
$0.0017
594.8s
toolUse
robot_move_base
Korekta po workspace_limit: lift=0 i ramię stowed; przesuń bazę krótko w lokalnym ujemnym y, aby klamka g_wc weszła w zasięg TCP
ok
75,493
in 3 · out 250 · cR 7186 · cW 68054 · reason 140
$0.017
602.2s
toolUse
robot_observe
Po korekcie bazy: świeży handle_candidate_m g_wc i lidar, potwierdź bezpieczne podniesienie liftu
{"observation_id":"obs-023062a8-29-33659","session_id":"023062a8","time_s":67.318,"rgb_path":"/home/pawel/Documents/Hom…
75,500
in 3 · out 49 · cR 75240 · cW 208
$0.0016
612.5s
toolUse
robot_move_lift
Podnieś pustą stowed kolumnę do 0.40 m po korekcie bazy i świeżej obserwacji klamki
ok
77,567
in 3 · out 82 · cR 7186 · cW 70296
$0.018
623.0s
toolUse
robot_observe
Po lift=0.40: odczytaj ponownie aktualny kandydat g_wc przed REACH
{"observation_id":"obs-023062a8-30-36993","session_id":"023062a8","time_s":73.986,"rgb_path":"/home/pawel/Documents/Hom…
77,654
in 3 · out 41 · cR 77482 · cW 128
$0.0016
635.4s
toolUse
robot_move_lift
Kandydat nadal wymaga zbliżenia w osi y; opuść pustą stowed kolumnę przed kolejną korektą bazy
ok
79,898
in 3 · out 276 · cR 7186 · cW 72433 · reason 189
$0.019
642.7s
toolUse
robot_move_base
Korekta reach g_wc: lift=0, ramię stowed; krótki ruch bazy dy=-0.18 do wejścia klamki w workspace
rejected
79,851
in 3 · out 98 · cR 79619 · cW 131
$0.0017
654.4s
toolUse
robot_observe
Po odrzuceniu stale_observation: świeża obserwacja przed korektą bazy; potwierdź lift=0, stowed, stop=false
{"observation_id":"obs-023062a8-31-40327","session_id":"023062a8","time_s":80.654,"rgb_path":"/home/pawel/Documents/Hom…
79,955
in 3 · out 79 · cR 79750 · cW 123 · reason 24
$0.0017
662.9s
toolUse
robot_move_base
Korekta reach: po świeżej obserwacji lift=0, ramię stowed; przesuń bazę krótko dy=-0.18, z dala od skrzydła
ok
81,994
in 3 · out 104 · cR 7186 · cW 74701
$0.019
672.4s
toolUse
robot_observe
Po korekcie bazy: świeży kandydat g_wc oraz lidar; przygotuj REACH po lift=0.40
{"observation_id":"obs-023062a8-32-41276","session_id":"023062a8","time_s":82.552,"rgb_path":"/home/pawel/Documents/Hom…
82,140
in 3 · out 46 · cR 81887 · cW 204
$0.0017
684.8s
toolUse
robot_move_lift
Podnieś pustą stowed kolumnę do 0.40 m po świeżej korekcie bazy; przygotuj REACH g_wc
ok
84,328
in 3 · out 165 · cR 7186 · cW 76974 · reason 81
$0.020
692.4s
toolUse
robot_observe
Po lift: świeżo odczytaj handle_candidate_m g_wc przed ruchem TCP
{"observation_id":"obs-023062a8-33-44610","session_id":"023062a8","time_s":89.22,"rgb_path":"/home/pawel/Documents/Home…
84,328
in 3 · out 37 · cR 84160 · cW 128
$0.0018
703.3s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego, osiągalnego kandydata klamki g_wc; pojedynczy ruch TCP
ok · move_tcp · F=0.00N · grip=no
86,480
in 3 · out 121 · cR 7186 · cW 79170 · reason 25
$0.020
712.5s
toolUse
robot_observe
Po REACH g_wc: potwierdź TCP przy klamce, stop=false i brak kontaktu przed grasp
{"observation_id":"obs-023062a8-34-46970","session_id":"023062a8","time_s":93.94,"rgb_path":"/home/pawel/Documents/Home…
86,560
in 3 · out 43 · cR 86356 · cW 158
$0.0018
723.2s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_wc z aktualnego TCP
ok
88,711
in 3 · out 96 · cR 7186 · cW 81426 · reason 20
$0.021
732.5s
toolUse
robot_observe
Po grasp g_wc: potwierdź kontakt, TCP i stop=false przed press
{"observation_id":"obs-023062a8-35-47020","session_id":"023062a8","time_s":94.04,"rgb_path":"/home/pawel/Documents/Home…
88,897
in 3 · out 36 · cR 88612 · cW 246
$0.0019
742.6s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_wc przed otwarciem
ok
91,029
in 3 · out 73 · cR 7186 · cW 83767
$0.021
752.5s
toolUse
robot_observe
Po press g_wc: potwierdź uchwyt, zwolnienie zatrzasku i stop=false przed OPEN
{"observation_id":"obs-023062a8-36-47470","session_id":"023062a8","time_s":94.94,"rgb_path":"/home/pawel/Documents/Home…
91,246
in 3 · out 44 · cR 90953 · cW 246
$0.0019
763.3s
toolUse
robot_door_action
OPEN: po potwierdzonym press otwórz fizycznie drzwi g_wc; monitoruj postęp i stop
incomplete_motion
93,422
in 3 · out 80 · cR 7186 · cW 86153
$0.022
774.7s
toolUse
robot_observe
Po niepełnym OPEN: świeża obserwacja kontaktu, siły, TCP i skrzydła; postęp 0.256<1.0 nie spełnia kryterium mostly-open
{"observation_id":"obs-023062a8-37-51814","session_id":"023062a8","time_s":103.628,"rgb_path":"/home/pawel/Documents/Ho…
93,859
in 3 · out 270 · cR 93339 · cW 247 · reason 206
$0.0023
784.1s
toolUse
robot_door_action
OPEN ponownie po świeżej obserwacji: kontynuuj fizyczne otwieranie g_wc; postęp jest mały, ale stop_latched=false i kontakt utrzymany
incomplete_motion
95,873
in 3 · out 130 · cR 7186 · cW 88554 · reason 36
$0.022
793.6s
toolUse
robot_observe
Po drugim incomplete OPEN: sprawdź świeży postęp, kontakt, siłę i stop; nie akceptuj jako mostly-open przy 0.256 rad
{"observation_id":"obs-023062a8-38-55523","session_id":"023062a8","time_s":111.046,"rgb_path":"/home/pawel/Documents/Ho…
96,139
in 3 · out 136 · cR 95740 · cW 260 · reason 82
$0.0021
806.2s
toolUse
robot_door_action
OPEN pozostaje zablokowane na 0.256 rad po dwóch próbach, bez wzrostu postępu; nie forsuję. Zwolnij bezpiecznie chwyt g_wc przed odwrotem
ok
98,482
in 3 · out 328 · cR 7186 · cW 90965 · reason 227
$0.023
812.9s
toolUse
robot_observe
Po release: potwierdź chwyt puszczony i zachowaj suggested_retreat dla bezpiecznego wycofania; nie próbuj ponownie OPEN
{"observation_id":"obs-023062a8-39-55773","session_id":"023062a8","time_s":111.546,"rgb_path":"/home/pawel/Documents/Ho…
98,587
in 3 · out 54 · cR 98151 · cW 379
$0.0021
824.1s
toolUse
robot_execute_sequence
RETREAT g_wc 1/4: wykonaj pierwszy suggested_retreat waypoint po zablokowanym otwieraniu, jeden ruch TCP
ok · move_tcp · F=0.00N · grip=no
100,866
in 3 · out 162 · cR 7186 · cW 93515 · reason 65
$0.024
833.2s
toolUse
robot_observe
Po retreat g_wc 1: potwierdź TCP i stop=false przed kolejnym waypointem
{"observation_id":"obs-023062a8-40-55995","session_id":"023062a8","time_s":111.99,"rgb_path":"/home/pawel/Documents/Hom…
100,904
in 3 · out 40 · cR 100701 · cW 160
$0.0021
844.0s
toolUse
robot_execute_sequence
RETREAT g_wc 2/4: wykonaj drugi suggested_retreat waypoint po obserwacji, bez przechodzenia przez skrzydło
collision_guard · F=0.00N · grip=no · STOP
103,126
in 3 · out 141 · cR 7186 · cW 95796 · reason 44
$0.024
85—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981450374686536
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039765969692027725
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976131721649755
    }
  },
  "events": [],
  "sim_time_s": 111.9899999999204,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 3.3094336715454756e-38,
      "handle_angle_rad": -4.604555137381448e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -5.506836459545501e-09,
      "handle_angle_rad": -6.499921258855441e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -2.809366323365336e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3979494848183796,
      "handle_angle_rad": -2.774795311761476e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": 0.2560214127354218,
      "handle_angle_rad": -8.221561083335399e-05,
      "latch_active": false
    },
    "g_vestibule": {
      "hinge_angle_rad": -5.133781407689572e-09,
      "handle_angle_rad": -2.8988507095336075e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -5.506836459271241e-09,
      "handle_angle_rad": -3.054456885823191e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-phased-luna56-004

dom · homebot-dom · 2026-11-03 10:59 · homebot-dom/runs/omp-door-chain-phased-luna56-004
0/3 w koszu

MP4 · 1.4 MB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt79 calli · $0.574
ag. limity78 req · 36 seq · 77 tools
czas misji432.8s
status agentarobot_stop_latched
calle LLM
79
tool calls
77
koszt zadania
$0.574
tokeny (sum)
4,799,181
in / out
234 / 7,686
cache R/W
2,752,029 / 2,039,232
czas modelu
289.1s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.6s
toolUse
robot_capabilities
Discover v4 capabilities, lift, frames, limits, and supported door controls for phase 1
mode=SIMULATION_ONLY
mission_memory_read
Read prior mission notes; treat them as unverified context only
{"revision":0,"agent_notes":null}
7,851
in 3 · out 131 · cR 0 · cW 7717 · reason 47
$0.0021
21.8s
toolUse
robot_observe
Survey the visible office door at the starting pose; capture door id, handle candidate, leaf geometry, hinge/opening evidence, lidar, stop state, and odometry
{"observation_id":"obs-36eca40a-1-350","session_id":"36eca40a","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,617
in 3 · out 52 · cR 7717 · cW 845
$0.0004
33.2s
toolUse
robot_look
Survey the closed office leaf and handle from an additional head angle before sweep check
ok
11,214
in 3 · out 118 · cR 8562 · cW 2531 · reason 42
$0.0009
42.7s
toolUse
robot_observe
Reobserve after survey look; refine visible handle candidate, hinge/free-edge evidence, opening direction, and clearance for sweep check
{"observation_id":"obs-36eca40a-2-632","session_id":"36eca40a","time_s":1.264,"rgb_path":"/home/pawel/Documents/HomeBot…
11,271
in 3 · out 43 · cR 11093 · cW 132
$0.0003
53.1s
toolUse
robot_move_base
Hinge-clear reposition only: stowed arm, lift down, rotate base about +0.785 rad toward observed hinge side; do not cross threshold
ok
14,000
in 3 · out 130 · cR 11225 · cW 2642 · reason 37
$0.0010
62.2s
toolUse
robot_observe
Verify hinge-clear pose and sweep safety after base yaw; confirm lift 0, stowed TCP, clear lidar and no latch before raising carriage
{"observation_id":"obs-36eca40a-3-1846","session_id":"36eca40a","time_s":3.692,"rgb_path":"/home/pawel/Documents/HomeBo…
14,098
in 3 · out 47 · cR 13867 · cW 181
$0.0004
74.4s
toolUse
robot_look
Re-aim camera toward the office handle after hinge-clear yaw; obtain a visible handle candidate before lift and reach
ok
16,686
in 3 · out 166 · cR 14048 · cW 2469 · reason 81
$0.0011
82.2s
toolUse
robot_observe
Observe the handle after re-aim; update current arm-carriage handle coordinates and door state before lift
{"observation_id":"obs-36eca40a-4-2409","session_id":"36eca40a","time_s":4.818,"rgb_path":"/home/pawel/Documents/HomeBo…
16,701
in 3 · out 39 · cR 16517 · cW 142
$0.0004
92.4s
toolUse
robot_move_lift
Raise the empty stowed arm carriage to 0.40 m for the observed 1.053 m handle; do not drive
ok
19,330
in 3 · out 79 · cR 16659 · cW 2589
$0.0011
102.8s
toolUse
robot_observe
Verify lifted state and obtain the fresh handle candidate in arm-carriage coordinates before reaching
{"observation_id":"obs-36eca40a-5-5743","session_id":"36eca40a","time_s":11.486,"rgb_path":"/home/pawel/Documents/HomeB…
19,413
in 3 · out 35 · cR 19248 · cW 127
$0.0005
114.8s
toolUse
robot_execute_sequence
Reach the freshly observed g_office handle with one bounded TCP waypoint; keep the arm near the handle for grasp
ok · move_tcp · F=0.00N · grip=no
22,158
in 3 · out 143 · cR 19375 · cW 2637 · reason 52
$0.0012
122.6s
toolUse
robot_observe
Verify TCP proximity and contact safety after reaching the current handle candidate
{"observation_id":"obs-36eca40a-6-7871","session_id":"36eca40a","time_s":15.742,"rgb_path":"/home/pawel/Documents/HomeB…
22,201
in 3 · out 31 · cR 22012 · cW 155
$0.0005
132.6s
toolUse
robot_door_action
Grasp the visible g_office handle at the verified TCP contact pose
ok
24,375
in 3 · out 71 · cR 8562 · cW 15739
$0.0042
143.0s
toolUse
robot_observe
Verify g_office grasp contact, force, TCP, and unchanged closed-door state before pressing latch
{"observation_id":"obs-36eca40a-7-7921","session_id":"36eca40a","time_s":15.842,"rgb_path":"/home/pawel/Documents/HomeB…
24,584
in 3 · out 38 · cR 24301 · cW 242
$0.0006
152.7s
toolUse
robot_door_action
Press the g_office spring lever while maintaining verified door grip
ok
26,755
in 3 · out 82 · cR 8562 · cW 18108 · reason 12
$0.0048
162.2s
toolUse
robot_observe
Verify latch press and maintained g_office grip before opening; ensure no stop latch and current TCP state
{"observation_id":"obs-36eca40a-8-8371","session_id":"36eca40a","time_s":16.742,"rgb_path":"/home/pawel/Documents/HomeB…
26,954
in 3 · out 39 · cR 26670 · cW 242
$0.0006
174.1s
toolUse
robot_door_action
Open the latch-released g_office door while maintaining the verified grip; do not drive or plan later phases
ok
29,176
in 3 · out 99 · cR 8562 · cW 20512 · reason 20
$0.0054
182.6s
toolUse
robot_observe
Verify g_office opening progress, leaf clearance, grip and stop state before release; remain in phase 1 only
{"observation_id":"obs-36eca40a-9-12715","session_id":"36eca40a","time_s":25.43,"rgb_path":"/home/pawel/Documents/HomeB…
29,368
in 3 · out 42 · cR 29074 · cW 249
$0.0007
195.9s
toolUse
robot_door_action
Release g_office handle after verified successful opening; obtain controller-suggested retreat waypoints and do not stow yet
ok
32,377
in 3 · out 94 · cR 7185 · cW 25095 · reason 13
$0.0065
203.3s
toolUse
robot_observe
Observe immediately after release; confirm no grip, open leaf geometry, contact-side retreat safety, and stop state
{"observation_id":"obs-36eca40a-10-12965","session_id":"36eca40a","time_s":25.93,"rgb_path":"/home/pawel/Documents/Home…
32,707
in 3 · out 57 · cR 32280 · cW 367 · reason 15
$0.0008
214.5s
toolUse
robot_execute_sequence
Retreat waypoint 1 from release result, exactly one TCP move; do not stow or cross
ok · move_tcp · F=0.00N · grip=no
35,735
in 3 · out 146 · cR 7185 · cW 28401 · reason 58
$0.0074
222.3s
toolUse
robot_observe
Verify retreat waypoint 1 clearance and open-leaf geometry before continuing along suggested retreat sequence
{"observation_id":"obs-36eca40a-11-13187","session_id":"36eca40a","time_s":26.374,"rgb_path":"/home/pawel/Documents/Hom…
35,776
in 3 · out 36 · cR 35586 · cW 151
$0.0008
233.9s
toolUse
robot_execute_sequence
Retreat waypoint 2 from the release result, exactly one TCP move; keep clear of the open leaf
ok · move_tcp · F=0.00N · grip=no
38,813
in 3 · out 116 · cR 7185 · cW 31509 · reason 27
$0.0082
242.5s
toolUse
robot_observe
Verify retreat waypoint 2 and recheck open-leaf extent before the next suggested retreat point
{"observation_id":"obs-36eca40a-12-13988","session_id":"36eca40a","time_s":27.976,"rgb_path":"/home/pawel/Documents/Hom…
38,886
in 3 · out 37 · cR 38694 · cW 152
$0.0009
253.6s
toolUse
robot_execute_sequence
Retreat waypoint 3 from the release result, exactly one TCP move; leave final stow waypoint for a separate verified command
ok · move_tcp · F=0.00N · grip=no
41,916
in 3 · out 91 · cR 7185 · cW 34637
$0.0089
262.8s
toolUse
robot_observe
Verify retreat waypoint 3 and final stow corridor; confirm open hand, no door grip, and no stop latch
{"observation_id":"obs-36eca40a-13-14682","session_id":"36eca40a","time_s":29.364,"rgb_path":"/home/pawel/Documents/Hom…
42,023
in 3 · out 42 · cR 41822 · cW 156
$0.0009
273.0s
toolUse
robot_execute_sequence
Final suggested retreat/stow waypoint from release result; move TCP to centered stowed-safe pose without crossing the open leaf
ok · move_tcp · F=0.00N · grip=no
44,999
in 3 · out 82 · cR 7185 · cW 37729
$0.0097
282.8s
toolUse
robot_observe
Verify final TCP stow position, open hand, no door grip, open door progress, and stop state before lowering lift
{"observation_id":"obs-36eca40a-14-16136","session_id":"36eca40a","time_s":32.272,"rgb_path":"/home/pawel/Documents/Hom…
45,107
in 3 · out 43 · cR 44914 · cW 147
$0.0010
294.9s
toolUse
robot_move_lift
Lower the empty stowed arm carriage to lift 0 as required for phase completion; do not drive
ok
48,162
in 3 · out 83 · cR 7185 · cW 40891 · reason 11
$0.010
302.8s
toolUse
robot_observe
Final phase-1 verification: lift 0, stowed TCP within drive interlock, empty open gripper, no door grip, door open, and no stop latch
{"observation_id":"obs-36eca40a-15-19470","session_id":"36eca40a","time_s":38.94,"rgb_path":"/home/pawel/Documents/Home…
48,247
in 3 · out 53 · cR 48076 · cW 115
$0.0011
316.7s
toolUse
mission_memory_write
Save bounded phase-1 evidence: observed g_office on house_ground_v4, opened and safely retreated/stowed, no driving or later-door actions
{"revision":1,"kind":"agent_mission_notes","notes":"Phase 1 complete. Fresh evidence: g_office visible at start, frame …
51,495
in 3 · out 280 · cR 7185 · cW 44027 · reason 73
$0.011
323.2s
stop
PHASE_COMPLETE — Otwarto drzwi `g_office` (opening_progress_rad: `-1.4340`), ramię bezpiecznie wycofane i schowane, podnośnik opuszczony do `0 m`, robot gotowy do jazdy. Ostatnia obserwacja: `obs-36eca40a-15-19470`.
51,704
in 3 · out 83 · cR 51212 · cW 406
$0.0012
334.0s
toolUse
robot_observe
Freshly verify phase-2 starting state: lift, arm stow, door grip, open g_office, lidar and nearby crossing geometry
{"observation_id":"obs-36eca40a-16-19470","session_id":"36eca40a","time_s":38.94,"rgb_path":"/home/pawel/Documents/Home…
52,298
in 3 · out 61 · cR 51618 · cW 616 · reason 12
$0.0013
346.2s
toolUse
robot_move_base
Begin crossing through the already-open g_office doorway with a short forward step; lift 0, arm stowed, no door grip
ok
55,530
in 3 · out 331 · cR 7185 · cW 48011 · reason 242
$0.013
352.7s
toolUse
robot_observe
Observe after first crossing step; verify leaf clearance, signed progress toward and through original office doorway, and lidar for next short step
{"observation_id":"obs-36eca40a-17-20419","session_id":"36eca40a","time_s":40.838,"rgb_path":"/home/pawel/Documents/Hom…
55,426
in 3 · out 44 · cR 55196 · cW 183
$0.0012
364.5s
toolUse
robot_move_base
Continue crossing with a second short forward step, gated by the fresh lidar and open-hand stowed state
ok
58,530
in 3 · out 80 · cR 7185 · cW 51262
$0.013
373.0s
toolUse
robot_observe
Verify the robot footprint has crossed the original g_office doorway plane; survey the new room for other visible doors and handle candidates
{"observation_id":"obs-36eca40a-18-21368","session_id":"36eca40a","time_s":42.736,"rgb_path":"/home/pawel/Documents/Hom…
58,671
in 3 · out 44 · cR 58447 · cW 177
$0.0013
384.8s
toolUse
robot_look
Scan the new room from the crossed position toward the visible g_wc and utility door frames; seek a fresh handle candidate with a door_id different from g_office
ok
61,745
in 3 · out 180 · cR 7185 · cW 54377 · reason 86
$0.014
393.2s
toolUse
robot_observe
Observe after new-room scan and identify a different visible door handle candidate, with pose and frame evidence for approach planning
{"observation_id":"obs-36eca40a-19-21931","session_id":"36eca40a","time_s":43.862,"rgb_path":"/home/pawel/Documents/Hom…
61,756
in 3 · out 41 · cR 61562 · cW 150
$0.0013
404.9s
toolUse
robot_look
The scan only sees the already-used g_office handle on its open leaf. Look to the opposite side of the new room to search for another door, without manipulating or driving
ok
63,831
in 3 · out 169 · cR 7185 · cW 56474 · reason 71
$0.014
412.6s
toolUse
robot_observe
Observe the opposite side of the new room for a distinct door_id and handle candidate before approaching it
{"observation_id":"obs-36eca40a-20-22838","session_id":"36eca40a","time_s":45.676,"rgb_path":"/home/pawel/Documents/Hom…
63,851
in 3 · out 38 · cR 63659 · cW 151
$0.0014
424.7s
toolUse
robot_move_base
Approach the distinct g_wc door with a short stowed-arm base step toward its observed handle side; lift remains 0 and no door action
ok
67,178
in 3 · out 220 · cR 7185 · cW 59770 · reason 122
$0.015
432.7s
toolUse
robot_observe
Verify approach pose, fresh lidar clearance, and g_wc handle visibility/proximity; do not lift or manipulate in this phase
{"observation_id":"obs-36eca40a-21-24028","session_id":"36eca40a","time_s":48.056,"rgb_path":"/home/pawel/Documents/Hom…
67,199
in 3 · out 43 · cR 66955 · cW 198
$0.0014
447.3s
toolUse
robot_move_base
Approach g_wc further with a short stowed-arm step chosen from its fresh local handle offset; keep lift 0 and do not manipulate
ok
70,774
in 3 · out 278 · cR 7185 · cW 63308 · reason 181
$0.016
452.9s
toolUse
robot_observe
Final phase-2 verification at the next door: confirm g_wc is distinct from g_office, handle visible, approach safe, lift 0, arm stowed, and no door action/grip
{"observation_id":"obs-36eca40a-22-25147","session_id":"36eca40a","time_s":50.294,"rgb_path":"/home/pawel/Documents/Hom…
70,746
in 3 · out 59 · cR 70493 · cW 191
$0.0015
467.4s
toolUse
robot_move_base
Shorten and continue the stowed-arm approach toward the observed g_wc handle; keep lift 0 and avoid door manipulation
ok
74,218
in 3 · out 362 · cR 7185 · cW 66668 · reason 269
$0.017
473.6s
toolUse
robot_observe
Confirm final phase-2 pose near distinct g_wc door, with visible handle candidate, safe lidar, lift 0 and arm stowed; no door_action
{"observation_id":"obs-36eca40a-23-26128","session_id":"36eca40a","time_s":52.256,"rgb_path":"/home/pawel/Documents/Hom…
74,100
in 3 · out 50 · cR 73853 · cW 194
$0.0016
484.3s
toolUse
mission_memory_write
Save phase-2 evidence: crossed g_office without door manipulation, found distinct g_wc handle, and approached with lift down and arm stowed
{"revision":2,"kind":"agent_mission_notes","notes":"Phase 2 complete. Crossed open g_office via two short successful ba…
77,487
in 3 · out 199 · cR 7185 · cW 70100
$0.018
493.7s
stop
PHASE_COMPLETE — Przekroczono próg przez `g_office` i znaleziono oraz osiągnięto podejście do innych drzwi `g_wc`. Ramię schowane, podnośnik `0 m`, bez chwytu i bez manipulacji drzwiami. Ostatnia obserwacja: `obs-36eca4…
77,769
in 3 · out 85 · cR 77285 · cW 396
$0.0017
505.6s
toolUse
robot_observe
Fresh phase-3 start check and survey g_wc: verify lift 0, arm stowed, no grip, visible second-door handle, leaf and hinge/opening evidence
{"observation_id":"obs-36eca40a-24-26128","session_id":"36eca40a","time_s":52.256,"rgb_path":"/home/pawel/Documents/Hom…
78,372
in 3 · out 241 · cR 77681 · cW 447 · reason 186
$0.0020
513.4s
toolUse
robot_move_base
Hinge-clear for g_wc: rotate the stowed base a small positive amount toward the observed hinge side, with lift 0 and no door grip
ok
81,414
in 3 · out 93 · cR 7185 · cW 74133
$0.019
522.6s
toolUse
robot_observe
Verify g_wc hinge-clear pose and resurvey handle candidate after yaw; ensure lift 0, stowed arm, no latch
{"observation_id":"obs-36eca40a-25-27047","session_id":"36eca40a","time_s":54.094,"rgb_path":"/home/pawel/Documents/Hom…
81,560
in 3 · out 44 · cR 81318 · cW 195
$0.0017
533.6s
toolUse
robot_move_lift
Raise the empty stowed arm carriage to 0.40 m for the fresh g_wc handle candidate at world height about 1.052 m
ok
83,700
in 3 · out 82 · cR 7185 · cW 76430
$0.019
542.4s
toolUse
robot_observe
Verify lifted state and refresh the g_wc handle candidate in arm-carriage coordinates before reach
{"observation_id":"obs-36eca40a-26-30381","session_id":"36eca40a","time_s":60.762,"rgb_path":"/home/pawel/Documents/Hom…
83,784
in 3 · out 36 · cR 83615 · cW 130
$0.0017
553.7s
toolUse
robot_execute_sequence
Reach the freshly observed g_wc handle with one bounded TCP waypoint; keep arm near contact for the separate grasp action
rejected
85,990
in 3 · out 89 · cR 7185 · cW 78713
$0.020
564.3s
toolUse
robot_observe
After workspace-limit rejection, reobserve current safe state and handle geometry; do not repeat unreachable reach blindly
{"observation_id":"obs-36eca40a-27-30381","session_id":"36eca40a","time_s":60.762,"rgb_path":"/home/pawel/Documents/Hom…
86,117
in 3 · out 104 · cR 85898 · cW 112 · reason 63
$0.0019
576.5s
toolUse
robot_move_lift
Recover workspace-limit safely: lower empty stowed carriage to 0 before repositioning the base; no door grip or manipulation
ok
88,464
in 3 · out 266 · cR 7185 · cW 81010 · reason 187
$0.021
582.9s
toolUse
robot_observe
Verify safe lowered state and current g_wc position before a small base correction to bring the handle within TCP workspace
{"observation_id":"obs-36eca40a-28-33715","session_id":"36eca40a","time_s":67.43,"rgb_path":"/home/pawel/Documents/Home…
88,363
in 3 · out 40 · cR 88195 · cW 125
$0.0018
596.6s
toolUse
robot_move_base
Reposition the stowed base a short 0.15 m along base y toward the g_wc handle so its local y enters TCP workspace; lift remains 0, no door grip
ok
90,677
in 3 · out 229 · cR 7185 · cW 83260 · reason 126
$0.021
603.0s
toolUse
robot_observe
Verify repositioned safe base pose and obtain a fresh g_wc handle candidate before raising the lift again
{"observation_id":"obs-36eca40a-29-34582","session_id":"36eca40a","time_s":69.164,"rgb_path":"/home/pawel/Documents/Hom…
90,688
in 3 · out 38 · cR 90445 · cW 202
$0.0019
613.7s
toolUse
robot_move_lift
Raise empty stowed carriage to 0.40 m now that the base is repositioned and the g_wc handle is within workspace
ok
92,778
in 3 · out 81 · cR 7185 · cW 85509
$0.022
623.0s
toolUse
robot_observe
Verify lifted state and refresh g_wc handle candidate for the reachable TCP waypoint
{"observation_id":"obs-36eca40a-30-37916","session_id":"36eca40a","time_s":75.832,"rgb_path":"/home/pawel/Documents/Hom…
92,861
in 3 · out 33 · cR 92694 · cW 131
$0.0019
633.3s
toolUse
robot_execute_sequence
Reach the current fresh g_wc handle candidate with one bounded TCP waypoint, now within workspace after base reposition
rejected
94,953
in 3 · out 87 · cR 7185 · cW 87678
$0.022
646.6s
toolUse
robot_move_lift
Recover second workspace rejection safely: lower empty stowed carriage to 0 before a small base correction; do not manipulate door
ok
95,131
in 3 · out 155 · cR 94863 · cW 110 · reason 76
$0.0021
655.1s
toolUse
robot_observe
Verify lowered state after second reach rejection and refresh g_wc handle before the final small approach correction
{"observation_id":"obs-36eca40a-31-41250","session_id":"36eca40a","time_s":82.5,"rgb_path":"/home/pawel/Documents/HomeB…
95,266
in 3 · out 165 · cR 94973 · cW 125 · reason 126
$0.0021
663.8s
toolUse
robot_move_base
Final small stowed-base correction toward g_wc handle to reduce local x/y reach; lift 0, no grip, short safe step
ok
97,223
in 3 · out 92 · cR 7185 · cW 89943
$0.023
672.9s
toolUse
robot_observe
Verify final corrected pose and fresh g_wc handle candidate before raising lift; ensure no stop latch and door still closed
{"observation_id":"obs-36eca40a-32-42100","session_id":"36eca40a","time_s":84.2,"rgb_path":"/home/pawel/Documents/HomeB…
97,364
in 3 · out 41 · cR 97128 · cW 192
$0.0020
685.3s
toolUse
robot_move_base
Correct the stowed base laterally toward the g_wc handle so its fresh local y coordinate enters TCP workspace; lift 0, short step, no manipulation
ok
99,678
in 3 · out 214 · cR 7185 · cW 92276 · reason 117
$0.023
692.5s
toolUse
robot_observe
Verify the latest corrected approach and obtain the current g_wc handle candidate before lifting and reaching
{"observation_id":"obs-36eca40a-33-43100","session_id":"36eca40a","time_s":86.2,"rgb_path":"/home/pawel/Documents/HomeB…
99,696
in 3 · out 36 · cR 99461 · cW 196
$0.0021
703.6s
toolUse
robot_move_lift
Raise the empty stowed carriage to 0.40 m for the now closer g_wc handle candidate
ok
101,792
in 3 · out 102 · cR 7185 · cW 94502 · reason 25
$0.024
713.5s
toolUse
robot_observe
Verify lift and refresh g_wc handle candidate immediately before reach
{"observation_id":"obs-36eca40a-34-46434","session_id":"36eca40a","time_s":92.868,"rgb_path":"/home/pawel/Documents/Hom…
101,845
in 3 · out 30 · cR 101687 · cW 125
$0.0021
725.2s
toolUse
robot_execute_sequence
Reach the freshly observed g_wc handle at the now reachable arm-carriage waypoint; keep this as one short TCP move before grasp
ok · move_tcp · F=0.00N · grip=no
103,951
in 3 · out 131 · cR 7185 · cW 96632 · reason 37
$0.024
732.8s
toolUse
robot_observe
Verify TCP contact proximity and safe state after reaching g_wc handle
{"observation_id":"obs-36eca40a-35-48430","session_id":"36eca40a","time_s":96.86,"rgb_path":"/home/pawel/Documents/Home…
104,009
in 3 · out 31 · cR 103817 · cW 158
$0.0022
743.5s
toolUse
robot_door_action
Grasp the verified visible g_wc handle at the current TCP contact pose
ok
106,039
in 3 · out 88 · cR 7185 · cW 98763 · reason 15
$0.025
753.1s
toolUse
robot_observe
Verify g_wc grasp contact and unchanged closed-door state before pressing the latch
{"observation_id":"obs-36eca40a-36-48480","session_id":"36eca40a","time_s":96.96,"rgb_path":"/home/pawel/Documents/Home…
106,228
in 3 · out 33 · cR 105948 · cW 244
$0.0022
763.1s
toolUse
robot_door_action
Press the g_wc spring lever while maintaining verified door grip
ok
108,305
in 3 · out 67 · cR 7185 · cW 101050
$0.025
772.8s
toolUse
robot_observe
Verify g_wc latch press and maintained grip before opening
{"observation_id":"obs-36eca40a-37-48930","session_id":"36eca40a","time_s":97.86,"rgb_path":"/home/pawel/Documents/Home…
108,508
in 3 · out 29 · cR 108235 · cW 241
$0.0023
783.4s
toolUse
robot_door_action
Open the latch-released g_wc door while maintaining verified grip; remain in phase 3 and do not cross threshold
stopped
110,617
in 3 · out 97 · cR 7185 · cW 103332 · reason 17
$0.026
79—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981423142108927
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976833799761402
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976154337986145
    }
  },
  "events": [
    {
      "event": "door_reach_stop",
      "time_s": 98.54799999995173,
      "opening_progress_rad": 0.046677929633874904,
      "hard_stop": true,
      "tcp_arm_m": [
        0.3152486844121345,
        -0.6802143116814195,
        0.6191862184686147
      ]
    }
  ],
  "sim_time_s": 98.54799999995173,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": -4.1158721361929707e-38,
      "handle_angle_rad": -1.1245660206503022e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -9.015756937731693e-09,
      "handle_angle_rad": 3.099228423664234e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -3.719182541721122e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3980240208462855,
      "handle_angle_rad": -2.9966074784802545e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": 0.046677929633874904,
      "handle_angle_rad": -0.49389407026459153,
      "latch_active": false
    },
    "g_vestibule": {
      "hinge_angle_rad": -8.026163801345635e-09,
      "handle_angle_rad": -3.047064387636746e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -9.015756937346826e-09,
      "handle_angle_rad": -6.986170852587542e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-tests

dom · homebot-dom · 2026-11-03 10:38 · homebot-dom/runs/omp-tests
brak wyniku

Brak filmu w tym katalogu.

Brak evaluation/map memory.

Logi
brak logów

omp-door-chain-phased-luna56-002

dom · homebot-dom · 2026-11-03 10:28 · homebot-dom/runs/omp-door-chain-phased-luna56-002
0/3 w koszu

MP4 · 677.2 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt44 calli · $0.188
ag. limity43 req · 20 seq · 44 tools
czas misji225.2s
status agentarobot_stop_latched
calle LLM
44
tool calls
44
koszt zadania
$0.188
tokeny (sum)
1,624,676
in / out
129 / 5,041
cache R/W
968,945 / 650,561
czas modelu
148.0s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.8s
toolUse
robot_capabilities
DISCOVER: sprawdź wariant v4, lift, workspace, ramę i limity dla fazy otwarcia drzwi gabinetu
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć misji; traktuj notatki jako niezweryfikowane
{"revision":0,"agent_notes":null}
robot_observe
SURVEY: świeża obserwacja startu przy g_office; znajdź widoczne zamknięte drzwi gabinetu, klamkę, lidar, siły i stan stop
{"observation_id":"obs-0ce43362-1-350","session_id":"0ce43362","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
7,706
in 3 · out 206 · cR 0 · cW 7497 · reason 45
$0.0021
24.3s
toolUse
robot_look
SURVEY: zmień tilt, aby uzyskać świeży widok klamki g_office i geometrii zawiasu; bez ruchu podstawy
ok
11,041
in 3 · out 142 · cR 7497 · cW 3399 · reason 51
$0.0012
32.4s
toolUse
robot_observe
Świeża obserwacja po zmianie widoku: potwierdź klamkę, uchylenie/skrzydło, zawias i kandydat uchwytu g_office przed SWEEP_CHECK
{"observation_id":"obs-0ce43362-2-694","session_id":"0ce43362","time_s":1.388,"rgb_path":"/home/pawel/Documents/HomeBot…
11,107
in 3 · out 65 · cR 10896 · cW 143
$0.0003
43.8s
toolUse
robot_move_base
SWEEP_CHECK zakończony na podstawie dwóch widoków: klamka widoczna, pełne skrzydło i wolna przestrzeń ocenione; teraz hinge-clear zgodnie z fazą, ramię schowane/lift=0
ok
13,817
in 3 · out 153 · cR 11039 · cW 2622 · reason 38
$0.0011
53.4s
toolUse
robot_observe
Obserwacja po hinge-clear: potwierdź geometrię, stop, arm stowed/lift=0 i aktualnego kandydata klamki przed podniesieniem
{"observation_id":"obs-0ce43362-3-1908","session_id":"0ce43362","time_s":3.816,"rgb_path":"/home/pawel/Documents/HomeBo…
13,924
in 3 · out 58 · cR 13661 · cW 202
$0.0004
63.0s
toolUse
robot_move_lift
Podnieś pustą, schowaną kolumnę do 0.40 m zgodnie z fazą; obserwacja po hinge-clear jest świeża i stop nieaktywny
ok
16,364
in 3 · out 137 · cR 13863 · cW 2361 · reason 46
$0.0010
72.3s
toolUse
robot_observe
REACH: świeża obserwacja po lifcie; odczytaj aktualny handle_candidate_m względem arm_carriage i potwierdź zakres TCP
{"observation_id":"obs-0ce43362-4-5242","session_id":"0ce43362","time_s":10.484,"rgb_path":"/home/pawel/Documents/HomeB…
16,412
in 3 · out 51 · cR 16224 · cW 134
$0.0004
84.8s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego kandydata klamki g_office, bez chwytania; punkt mieści się w workspace arm_carriage
rejected
18,892
in 3 · out 139 · cR 16358 · cW 2392 · reason 38
$0.0011
93.5s
toolUse
robot_observe
Świeża obserwacja po odrzuceniu REACH; potwierdź lift=0.4 i aktualny kandydat klamki, bez resetowania stopu
{"observation_id":"obs-0ce43362-5-5242","session_id":"0ce43362","time_s":10.484,"rgb_path":"/home/pawel/Documents/HomeB…
18,973
in 3 · out 98 · cR 18750 · cW 122 · reason 39
$0.0005
104.5s
toolUse
robot_look
REACH korekta: klamka zniknęła po obrocie; skieruj kamerę w stronę skrzydła/zawiasu, aby uzyskać nowego widocznego kandydata po lifcie
ok
21,468
in 3 · out 228 · cR 18872 · cW 2365 · reason 116
$0.0012
112.2s
toolUse
robot_observe
Świeża korekcyjna obserwacja klamki g_office po zmianie pan/tilt; nie wykonuj ruchu bez nowego kandydata
{"observation_id":"obs-0ce43362-6-5461","session_id":"0ce43362","time_s":10.922,"rgb_path":"/home/pawel/Documents/HomeB…
21,464
in 3 · out 54 · cR 21237 · cW 170
$0.0005
122.5s
toolUse
robot_execute_sequence
REACH: przesuń TCP do aktualnego, widocznego kandydata klamki po korekcie widoku
ok · move_tcp · F=0.00N · grip=no
23,545
in 3 · out 90 · cR 7497 · cW 15955
$0.0042
132.1s
toolUse
robot_observe
Obserwacja po REACH: potwierdź TCP przy klamce i stan kontaktu przed GRASP
{"observation_id":"obs-0ce43362-7-7588","session_id":"0ce43362","time_s":15.176,"rgb_path":"/home/pawel/Documents/HomeB…
23,651
in 3 · out 43 · cR 23452 · cW 153
$0.0006
142.3s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_office przy aktualnym TCP i zachowaj sprzężenie drzwi
ok
25,733
in 3 · out 84 · cR 7497 · cW 18149
$0.0048
151.8s
toolUse
robot_observe
Obserwacja po GRASP: potwierdź door_grip, kontakt, siłę i brak stopu przed PRESS
{"observation_id":"obs-0ce43362-8-7638","session_id":"0ce43362","time_s":15.276,"rgb_path":"/home/pawel/Documents/HomeB…
25,949
in 3 · out 45 · cR 25646 · cW 255
$0.0006
163.4s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_office przed otwieraniem; użyj świeżej obserwacji po GRASP
ok
28,074
in 3 · out 85 · cR 7497 · cW 20489
$0.0054
172.2s
toolUse
robot_observe
Obserwacja po PRESS: potwierdź zatrzask zwolniony, grip i brak stopu przed OPEN
{"observation_id":"obs-0ce43362-9-8088","session_id":"0ce43362","time_s":16.176,"rgb_path":"/home/pawel/Documents/HomeB…
28,293
in 3 · out 45 · cR 27986 · cW 259
$0.0007
182.3s
toolUse
robot_door_action
OPEN: otwórz zwolnione drzwi g_office; monitoruj otwarcie i ewentualny bezpieczny clipped-leaf wynik
ok
30,388
in 3 · out 87 · cR 0 · cW 30298
$0.0077
192.8s
toolUse
robot_observe
Obserwacja po OPEN: potwierdź opening_progress, stop, kontakt i aktualny TCP przed RELEASE
{"observation_id":"obs-0ce43362-10-12432","session_id":"0ce43362","time_s":24.864,"rgb_path":"/home/pawel/Documents/Hom…
30,601
in 3 · out 42 · cR 30298 · cW 258
$0.0007
202.9s
toolUse
robot_door_action
RELEASE: po udanym otwarciu puść klamkę g_office; zachowaj wynik suggested_retreat
ok
33,710
in 3 · out 79 · cR 6964 · cW 26664
$0.0069
212.2s
toolUse
robot_observe
Po RELEASE: świeża obserwacja otwartego skrzydła i TCP; przygotuj pierwszy sugerowany punkt retreat, bez stowowania skokiem
{"observation_id":"obs-0ce43362-11-12682","session_id":"0ce43362","time_s":25.364,"rgb_path":"/home/pawel/Documents/Hom…
34,048
in 3 · out 52 · cR 33628 · cW 365
$0.0008
224.6s
toolUse
robot_execute_sequence
RETREAT punkt 1/4 z wyniku RELEASE, pojedynczy move_tcp; odchodzę po stronie kontaktu, bez skoku przez skrzydło
ok · move_tcp · F=0.00N · grip=no
37,245
in 3 · out 159 · cR 6964 · cW 30119 · reason 56
$0.0079
233.0s
toolUse
robot_observe
Obserwacja po retreat 1/4; sprawdź TCP, skrzydło, stop i czy kolejny sugerowany odcinek pozostaje bezpieczny
{"observation_id":"obs-0ce43362-12-12904","session_id":"0ce43362","time_s":25.808,"rgb_path":"/home/pawel/Documents/Hom…
37,308
in 3 · out 55 · cR 37083 · cW 167
$0.0009
243.9s
toolUse
robot_execute_sequence
RETREAT punkt 2/4 z wyniku RELEASE, pojedynczy move_tcp po obserwacji punktu 1
ok · move_tcp · F=0.00N · grip=no
40,428
in 3 · out 117 · cR 6964 · cW 33344 · reason 23
$0.0086
253.6s
toolUse
robot_observe
Obserwacja po retreat 2/4; sprawdź aktualny TCP i otwarte skrzydło przed punktem 3
{"observation_id":"obs-0ce43362-13-13705","session_id":"0ce43362","time_s":27.41,"rgb_path":"/home/pawel/Documents/Home…
40,517
in 3 · out 48 · cR 40308 · cW 158
$0.0009
262.8s
toolUse
robot_execute_sequence
RETREAT punkt 3/4 z wyniku RELEASE, pojedynczy move_tcp po obserwacji punktu 2
ok · move_tcp · F=0.00N · grip=no
43,657
in 3 · out 106 · cR 6964 · cW 36584 · reason 12
$0.0094
272.3s
toolUse
robot_observe
Obserwacja po retreat 3/4; sprawdź TCP i brak przeszkody przed ostatnim punktem sugerowanym
{"observation_id":"obs-0ce43362-14-14399","session_id":"0ce43362","time_s":28.798,"rgb_path":"/home/pawel/Documents/Hom…
43,756
in 3 · out 47 · cR 43548 · cW 158
$0.0010
282.6s
toolUse
robot_execute_sequence
RETREAT punkt 4/4: ostatni sugerowany punkt to bezpieczne schowanie TCP w workspace, pojedynczy move_tcp po obserwacji punktu 3
ok · move_tcp · F=0.00N · grip=no
46,860
in 3 · out 96 · cR 6964 · cW 39797
$0.010
292.3s
toolUse
robot_observe
Po pełnym RETREAT: potwierdź TCP stowed, pusty chwytak, door_grip=null i stop=false przed opuszczeniem liftu
{"observation_id":"obs-0ce43362-15-15853","session_id":"0ce43362","time_s":31.706,"rgb_path":"/home/pawel/Documents/Hom…
46,978
in 3 · out 52 · cR 46761 · cW 162
$0.0010
304.3s
toolUse
robot_move_lift
STOW spełnione: TCP=(0,0,0.55), pusty chwytak, door_grip=null. Opuść lift do 0 przed gotowością do jazdy; bez jazdy przez próg
ok
50,063
in 3 · out 131 · cR 6964 · cW 42965 · reason 32
$0.011
312.3s
toolUse
robot_observe
Końcowa obserwacja fazy 1: potwierdź lift=0, stowed arm, door_grip=null, stop=false oraz opening_progress g_office
{"observation_id":"obs-0ce43362-16-19187","session_id":"0ce43362","time_s":38.374,"rgb_path":"/home/pawel/Documents/Hom…
50,127
in 3 · out 55 · cR 49929 · cW 140
$0.0011
326.6s
toolUse
mission_memory_write
Zapisz zweryfikowany stan fazy 1: g_office otwarte, retreat wykonany wszystkimi 4 punktami, ramię stowed, lift opuszczony, bez jazdy przez próg
{"revision":1,"kind":"agent_mission_notes","notes":"Faza 1: DISCOVER v4 ground house_ground_v4, lift enabled. Door g_of…
53,515
in 3 · out 369 · cR 6964 · cW 46179 · reason 110
$0.012
336.1s
stop
Otwarto drzwi `g_office` (`opening_progress_rad=-1.4340`). Wykonano cały sugerowany retreat, ramię schowane, chwytak pusty, `lift_m=0`, `door_grip=null`, bez przejazdu przez próg. Końcowa obserwacja: `obs-0ce43362-16-19…
53,789
in 3 · out 147 · cR 53143 · cW 496 · reason 58
$0.0014
342.6s
toolUse
robot_observe
FAZA 2 start: sprawdź świeży stan liftu, stow, door_grip, stop, otwarte g_office i lidar przed CROSS
{"observation_id":"obs-0ce43362-17-19187","session_id":"0ce43362","time_s":38.374,"rgb_path":"/home/pawel/Documents/Hom…
54,224
in 3 · out 67 · cR 53639 · cW 515 · reason 13
$0.0013
355.5s
toolUse
robot_move_base
CROSS krok 1: stan spełnia lift=0, TCP stowed (xy=0,z=.55), pusty chwytak i brak chwytu. Przejdź krótko przez otwarte g_office wzdłuż lokalnego kierunku do otworu
ok
57,583
in 3 · out 294 · cR 6964 · cW 50322 · reason 170
$0.013
362.5s
toolUse
robot_observe
Świeży lidar po CROSS kroku 1; sprawdź położenie względem pierwotnej płaszczyzny g_office i możliwość następnego krótkiego kroku
{"observation_id":"obs-0ce43362-18-20187","session_id":"0ce43362","time_s":40.374,"rgb_path":"/home/pawel/Documents/Hom…
57,570
in 3 · out 59 · cR 57286 · cW 222
$0.0013
374.3s
toolUse
robot_move_base
CROSS krok 2: lidar po pierwszym kroku wskazuje wolną trasę; wykonaj kolejny krótki krok przez otwór, bez zmiany konfiguracji
ok
60,758
in 3 · out 140 · cR 6964 · cW 53651 · reason 39
$0.014
382.5s
toolUse
robot_observe
VERIFY CROSS: świeży lidar i detections po kroku 2; oceń przekroczenie pierwotnej płaszczyzny g_office i wyszukaj inne drzwi w nowym pokoju
{"observation_id":"obs-0ce43362-19-21187","session_id":"0ce43362","time_s":42.374,"rgb_path":"/home/pawel/Documents/Hom…
60,879
in 3 · out 63 · cR 60615 · cW 198
$0.0013
396.0s
toolUse
robot_look
Nowy pokój po CROSS: skieruj kamerę na inne drzwi g_wc, bez door_action i bez podnoszenia liftu; przygotuj świeży widok klamki
ok
64,242
in 3 · out 317 · cR 6964 · cW 56958 · reason 217
$0.015
402.5s
toolUse
robot_observe
Świeża obserwacja po look: potwierdź CROSS oraz widoczne inne drzwi z handle_candidate_m; wybierz door_id różne od g_office
{"observation_id":"obs-0ce43362-20-21469","session_id":"0ce43362","time_s":42.938,"rgb_path":"/home/pawel/Documents/Hom…
64,136
in 3 · out 55 · cR 63922 · cW 156
$0.0014
415.7s
toolUse
robot_move_base
Podejście do innych drzwi g_wc: ramię stowed/lift=0, chwytak pusty. Wykonaj krótki ruch bazy w stronę świeżego kandydata, pozostając poza skrzydłem
ok
67,542
in 3 · out 294 · cR 6964 · cW 60281 · reason 173
$0.016
422.6s
toolUse
robot_observe
Świeża obserwacja po podejściu: potwierdź inne drzwi g_wc, klamkę w zasięgu po podniesieniu oraz hinge-clear; nie chwytaj ani nie otwieraj
{"observation_id":"obs-0ce43362-21-22972","session_id":"0ce43362","time_s":45.944,"rgb_path":"/home/pawel/Documents/Hom…
67,534
in 3 · out 67 · cR 67245 · cW 219
$0.0015
436.9s
toolUse
robot_move_base
Dopasowanie pozycji przy g_wc: świeży lidar, lift=0 i ramię stowed. Krótki ruch dx=0.10 m, aby handle_candidate wejść w workspace po lifcie; bez door_action
collision_guard
70,805
in 3 · out 320 · cR 6964 · cW 63518 · reason 206
$0.016
44—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981232375490439
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976854960519853
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976096637735828
    }
  },
  "events": [],
  "sim_time_s": 45.944000000010185,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 2.5162261937984627e-38,
      "handle_angle_rad": -4.232907775122681e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -5.209199300195803e-09,
      "handle_angle_rad": -1.2693843830337576e-18,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -1.2753410996438061e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3983666977416627,
      "handle_angle_rad": 1.331330023482731e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -4.856313166621276e-09,
      "handle_angle_rad": -1.5273855017263382e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -4.856313166621276e-09,
      "handle_angle_rad": -1.5273855017263382e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -5.209199300085558e-09,
      "handle_angle_rad": -7.512263140747838e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-phased-luna56-001

dom · homebot-dom · 2026-11-03 10:21 · homebot-dom/runs/omp-door-chain-phased-luna56-001
0/3 w koszu

MP4 · 450.9 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-chain-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt25 calli · $0.061
ag. limity24 req · 12 seq · 26 tools
czas misji133.0s
status agentarobot_stop_latched
calle LLM
25
tool calls
26
koszt zadania
$0.061
tokeny (sum)
586,608
in / out
72 / 2,651
cache R/W
384,818 / 199,067
czas modelu
82.6s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.8s
toolUse
robot_capabilities
DISCOVER: sprawdź wariant v4, lift, workspace, ramę i limity dla fazy otwarcia drzwi gabinetu
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć misji; traktuj wcześniejsze notatki jako niezweryfikowane
{"revision":0,"agent_notes":null}
robot_observe
SURVEY: świeża obserwacja widocznych drzwi gabinetu przy g_office; zwróć RGB-D, lidar, handle/leaf candidates, odometrię, TCP, lift i stop
{"observation_id":"obs-8928e9d0-1-350","session_id":"8928e9d0","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
7,741
in 3 · out 216 · cR 0 · cW 7522 · reason 52
$0.0021
23.8s
toolUse
robot_move_base
Hinge-clear: ramię schowane, lift=0; obróć bazę o około +0.785 rad w stronę zawiasu, bez przejazdu przez próg
ok
11,075
in 3 · out 140 · cR 7522 · cW 3410 · reason 34
$0.0012
32.3s
toolUse
robot_observe
Po hinge-clear: potwierdź świeżą geometrię drzwi, zawias/klamkę, sweep feasibility i brak stopu przed podniesieniem liftu
{"observation_id":"obs-8928e9d0-2-1564","session_id":"8928e9d0","time_s":3.128,"rgb_path":"/home/pawel/Documents/HomeBo…
11,186
in 3 · out 55 · cR 10932 · cW 196
$0.0003
43.3s
toolUse
robot_move_lift
SWEEP_CHECK zaliczony w obserwowanym korytarzu: podnieś pustą, schowaną kolumnę do 0.40 m; nie jedź bazą
ok
13,855
in 3 · out 148 · cR 11128 · cW 2576 · reason 51
$0.0010
52.1s
toolUse
robot_observe
Po podniesieniu liftu: świeża obserwacja handle_candidate_m i TCP, przed REACH
{"observation_id":"obs-8928e9d0-3-4898","session_id":"8928e9d0","time_s":9.796,"rgb_path":"/home/pawel/Documents/HomeBo…
13,891
in 3 · out 41 · cR 13704 · cW 143
$0.0004
65.0s
toolUse
robot_look
SURVEY uzupełniający: zmień pan/tilt, aby uzyskać widoczną klamkę gabinetu i aktualny handle_candidate_m po lift=0.4
ok
16,555
in 3 · out 197 · cR 13847 · cW 2508 · reason 91
$0.0011
72.3s
toolUse
robot_observe
Odczytaj po zmianie widoku widoczną klamkę i handle_candidate_m; sprawdź kontakt oraz zasięg REACH
{"observation_id":"obs-8928e9d0-4-5180","session_id":"8928e9d0","time_s":10.36,"rgb_path":"/home/pawel/Documents/HomeBo…
16,571
in 3 · out 49 · cR 16355 · cW 164
$0.0004
84.2s
toolUse
robot_look
Klamka nadal nie jest jawnie wykryta; reorientuj kamerę na drugą stronę/wyższy obszar drzwi, bez ruchu bazy ani ramienia
ok
19,196
in 3 · out 167 · cR 16519 · cW 2507 · reason 60
$0.0012
92.4s
toolUse
robot_observe
Ponownie odczytaj obserwację drzwi gabinetu i sprawdź, czy pojawił się handle_candidate_m
{"observation_id":"obs-8928e9d0-5-5743","session_id":"8928e9d0","time_s":11.486,"rgb_path":"/home/pawel/Documents/HomeB…
19,240
in 3 · out 45 · cR 19026 · cW 166
$0.0005
103.3s
toolUse
robot_execute_sequence
REACH: przesuń TCP do świeżego handle_candidate_m w arm_carriage; jeden krótki skrypt, bez chwytu
ok · move_tcp · F=0.00N · grip=no
21,869
in 3 · out 128 · cR 19192 · cW 2546 · reason 28
$0.0012
112.8s
toolUse
robot_observe
Po REACH: potwierdź TCP przy klamce, kontakt, lift i brak stopu przed GRASP
{"observation_id":"obs-8928e9d0-6-7869","session_id":"8928e9d0","time_s":15.738,"rgb_path":"/home/pawel/Documents/HomeB…
21,948
in 3 · out 43 · cR 21738 · cW 164
$0.0005
122.6s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_office w aktualnym TCP
ok
24,047
in 3 · out 79 · cR 7522 · cW 16443
$0.0044
132.4s
toolUse
robot_observe
Po GRASP: potwierdź door_grip, kontakt i siłę przed PRESS
{"observation_id":"obs-8928e9d0-7-7919","session_id":"8928e9d0","time_s":15.838,"rgb_path":"/home/pawel/Documents/HomeB…
24,253
in 3 · out 37 · cR 23965 · cW 248
$0.0006
142.5s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_office przed otwarciem
ok
26,311
in 3 · out 79 · cR 7522 · cW 18707
$0.0049
152.3s
toolUse
robot_observe
Po PRESS: potwierdź zwolnienie zatrzasku i stan uchwytu przed OPEN
{"observation_id":"obs-8928e9d0-8-8369","session_id":"8928e9d0","time_s":16.738,"rgb_path":"/home/pawel/Documents/HomeB…
26,526
in 3 · out 40 · cR 26229 · cW 254
$0.0006
162.8s
toolUse
robot_door_action
OPEN: fizycznie otwórz g_office po zwolnieniu zatrzasku; bez dalszych faz
ok
28,627
in 3 · out 84 · cR 7522 · cW 21018
$0.0055
174.6s
toolUse
robot_observe
Po OPEN: potwierdź opening_progress, aktualną orientację kontaktu i powierzchnie skrzydła przed RELEASE
{"observation_id":"obs-8928e9d0-9-12713","session_id":"8928e9d0","time_s":25.426,"rgb_path":"/home/pawel/Documents/Home…
28,861
in 3 · out 61 · cR 28540 · cW 257 · reason 14
$0.0007
185.1s
toolUse
robot_door_action
RELEASE: otwarcie zakończone (progress -1.4546 rad); puść uchwyt g_office przed ostrożnym retreatem
ok
32,035
in 3 · out 154 · cR 6976 · cW 24902 · reason 60
$0.0066
192.5s
toolUse
robot_observe
Po RELEASE: obserwuj dryf skrzydła, zachowaj contact_frame i sprawdź widoczną wolną krawędź/korytarz retreatu
{"observation_id":"obs-8928e9d0-10-12963","session_id":"8928e9d0","time_s":25.926,"rgb_path":"/home/pawel/Documents/Hom…
32,194
in 3 · out 56 · cR 31878 · cW 257
$0.0008
205.0s
toolUse
robot_execute_sequence
RETREAT krok 1: odsuń TCP po aktualnej normalnej kontaktu o 4 cm, jeden waypoint; nie przechodź przez skrzydło
ok · move_tcp · F=0.00N · grip=no
35,411
in 3 · out 159 · cR 6976 · cW 28273 · reason 53
$0.0074
213.5s
toolUse
robot_observe
Po RETREAT normalnym: sprawdź TCP, otwarte skrzydło i wolną krawędź przed następnym waypointem
{"observation_id":"obs-8928e9d0-11-13074","session_id":"8928e9d0","time_s":26.148,"rgb_path":"/home/pawel/Documents/Hom…
35,473
in 3 · out 50 · cR 35249 · cW 171
$0.0008
226.0s
toolUse
robot_execute_sequence
RETREAT krok 2: po odsunięciu od skrzydła przejdź jednym waypointem 5 cm w stronę bazy, pozostając po stronie kontaktu i poza widoczną krawędzią
ok · move_tcp · F=0.00N · grip=no
38,815
in 3 · out 288 · cR 6976 · cW 31548 · reason 169
$0.0084
232.8s
toolUse
robot_observe
Po RETREAT kroku 2: potwierdź bezpieczny korytarz do stow, TCP i brak kontaktu z drzwiami
{"observation_id":"obs-8928e9d0-12-13270","session_id":"8928e9d0","time_s":26.54,"rgb_path":"/home/pawel/Documents/Home…
38,762
in 3 · out 51 · cR 38524 · cW 184
$0.0009
245.2s
toolUse
robot_execute_sequence
RETREAT krok 3: dodatkowe 5 cm w stronę bazy, nadal pojedynczy waypoint po zweryfikowanym korytarzu; nie stowuj jeszcze
collision_guard · F=0.00N · grip=no · STOP
42,166
in 3 · out 284 · cR 6976 · cW 34903 · reason 174
$0.0092
25—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981321881748656
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976753424695785
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976117387003347
    }
  },
  "events": [],
  "sim_time_s": 26.53999999999617,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 3.184604232138851e-38,
      "handle_angle_rad": -4.458395881737691e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -7.181653818485614e-09,
      "handle_angle_rad": 9.055909753752315e-20,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -3.170833463685776e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.4156996154328598,
      "handle_angle_rad": 1.7158544057972245e-05,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -6.776232536085622e-09,
      "handle_angle_rad": -1.8889144805279334e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.776232536085622e-09,
      "handle_angle_rad": -1.8889144805279334e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -7.1816538183999676e-09,
      "handle_angle_rad": -3.5484066709176526e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

_door-retreat-fix-001

dom · homebot-dom · 2026-11-03 10:21 · homebot-dom/runs/_door-retreat-fix-001
brak wyniku

Brak filmu w tym katalogu.

Brak evaluation/map memory.

omp-door-chain-luna56-001

dom · homebot-dom · 2026-11-03 10:07 · homebot-dom/runs/omp-door-chain-luna56-001
0/3 w koszu

MP4 · 163.7 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt13 calli · $0.014
ag. limity12 req · 6 seq · 14 tools
czas misji77.1s
status agentarobot_stop_latched
calle LLM
13
tool calls
14
koszt zadania
$0.014
tokeny (sum)
206,838
in / out
36 / 1,127
cache R/W
167,103 / 38,572
czas modelu
35.3s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.3s
toolUse
robot_capabilities
DISCOVER: sprawdź wariant v4, lift, ramę, limity i stan robota dla łańcucha wyjść
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj bieżące notatki misji; traktuj je jako niezweryfikowane
{"revision":0,"agent_notes":null}
robot_observe
SURVEY startu: świeży RGB-D, maski drzwi/klamki, lidar, siła, odometria i stan bezpieczeństwa
{"observation_id":"obs-c32060df-1-350","session_id":"c32060df","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,832
in 3 · out 180 · cR 0 · cW 8649 · reason 29
$0.0024
23.7s
toolUse
robot_look
SURVEY korekta: obecny kadr jest zasłonięty/bez handle_candidate; ustaw głowę poziomo dla g_office
ok
12,146
in 3 · out 112 · cR 8649 · cW 3382 · reason 29
$0.0012
33.1s
toolUse
robot_observe
Po look: ponów SURVEY g_office; pobierz handle_candidate, geometrię skrzydła, lidar i stan
{"observation_id":"obs-c32060df-2-913","session_id":"c32060df","time_s":1.826,"rgb_path":"/home/pawel/Documents/HomeBot…
12,213
in 3 · out 46 · cR 12031 · cW 133
$0.0003
44.0s
toolUse
robot_move_lift
REACH przygotowanie: po SURVEY handle jest widoczny, geometria skrzydła ma margines; podnieś pustą, schowaną kolumnę do 0.55 m
ok
14,707
in 3 · out 172 · cR 12164 · cW 2368 · reason 78
$0.0010
53.2s
toolUse
robot_observe
Po podniesieniu: świeża obserwacja handle_candidate_m w arm_carriage i kontrola stop/TCP/siły/lidar
{"observation_id":"obs-c32060df-3-5497","session_id":"c32060df","time_s":10.994,"rgb_path":"/home/pawel/Documents/HomeB…
14,722
in 3 · out 48 · cR 14532 · cW 139
$0.0004
64.1s
toolUse
robot_execute_sequence
REACH/SWEEP_CHECK: świeży kandydat po lift=0.55 jest w workspace z 3 cm rezerwą; wykonaj bezpieczne podejście TCP do aktualnej klamki
ok · move_tcp → move_tcp · F=0.00N · grip=no
17,270
in 3 · out 189 · cR 14671 · cW 2407 · reason 61
$0.0011
72.2s
toolUse
robot_observe
Po REACH: sprawdź TCP, klamkę, kontakt, siłę i stop przed GRASP
{"observation_id":"obs-c32060df-4-7558","session_id":"c32060df","time_s":15.116,"rgb_path":"/home/pawel/Documents/HomeB…
17,316
in 3 · out 41 · cR 17078 · cW 194
$0.0004
82.4s
toolUse
robot_door_action
GRASP drzwi 1: TCP potwierdzony przy świeżej klamce g_office; chwyć widoczną klamkę
ok
19,796
in 3 · out 87 · cR 17272 · cW 2434
$0.0011
92.3s
toolUse
robot_observe
Po GRASP: potwierdź kontakt, uchwyt drzwi, siłę i stop przed PRESS
{"observation_id":"obs-c32060df-5-7608","session_id":"c32060df","time_s":15.216,"rgb_path":"/home/pawel/Documents/HomeB…
20,013
in 3 · out 41 · cR 19706 · cW 263
$0.0005
102.6s
toolUse
robot_door_action
PRESS drzwi 1: świeży kontakt g_office potwierdzony; naciśnij sprężynową klamkę przed otwarciem
ok
22,472
in 3 · out 87 · cR 19969 · cW 2413
$0.0011
112.1s
toolUse
robot_observe
Po PRESS: sprawdź zwolnienie zatrzasku, siłę, kontakt i stop przed OPEN
{"observation_id":"obs-c32060df-6-8058","session_id":"c32060df","time_s":16.116,"rgb_path":"/home/pawel/Documents/HomeB…
22,695
in 3 · out 41 · cR 22382 · cW 269
$0.0006
122.3s
toolUse
robot_door_action
OPEN drzwi 1: zatrzask zwolniony po PRESS; otwieraj g_office kontrolowanym sprzężeniem
stopped
24,656
in 3 · out 83 · cR 8649 · cW 15921
$0.0043
13—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.00398151645807774
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976706392148879
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976171278154264
    }
  },
  "events": [
    {
      "event": "door_reach_stop",
      "time_s": 23.32599999999795
    }
  ],
  "sim_time_s": 23.32599999999795,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 2.0088545303819928e-38,
      "handle_angle_rad": -3.856680226469455e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -8.353573010511844e-09,
      "handle_angle_rad": -5.505615915214494e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -1.4503019654729022e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3960589265223267,
      "handle_angle_rad": -0.5188990722020863,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -7.907056884229741e-09,
      "handle_angle_rad": -9.69017822534257e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -7.907056884229741e-09,
      "handle_angle_rad": -9.69017822534257e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -8.353573010426365e-09,
      "handle_angle_rad": -4.008315104089053e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-chain-luna56-002

dom · homebot-dom · 2026-11-03 10:07 · homebot-dom/runs/omp-door-chain-luna56-002
0/3 w koszu

MP4 · 444.1 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt24 calli · $0.048
ag. limity23 req · 11 seq · 24 tools
czas misji120.3s
status agentarobot_stop_latched
calle LLM
24
tool calls
24
koszt zadania
$0.048
tokeny (sum)
504,905
in / out
69 / 2,209
cache R/W
349,145 / 153,482
czas modelu
70.2s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.2s
toolUse
robot_capabilities
DISCOVER: pobierz pełne możliwości MCPv4, lift, workspace, floor/frame i limity
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj notatki misji; traktuj je wyłącznie jako niezweryfikowane
{"revision":0,"agent_notes":null}
8,128
in 3 · out 126 · cR 0 · cW 7999 · reason 30
$0.0022
21.7s
toolUse
robot_observe
SURVEY: świeża obserwacja startu przy g_office; wykryj widoczne drzwi, klamki, hinge/free-edge, lidar, odometrię i stop
{"observation_id":"obs-2923688a-1-350","session_id":"2923688a","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,927
in 3 · out 68 · cR 7999 · cW 857 · reason 8
$0.0005
33.9s
toolUse
robot_look
SURVEY korekta: obróć kamerę ku skrzydłu g_office, aby odsłonić klamkę i ocenić zawias/free edge; bez ruchu bazy
ok
11,538
in 3 · out 146 · cR 8856 · cW 2533 · reason 43
$0.0010
42.1s
toolUse
robot_observe
SWEEP_CHECK: po nowym widoku zmierz klamkę, geometrię skrzydła i przeszkody; potwierdź stop oraz feasibility łuku z rezerwą 3 cm
{"observation_id":"obs-2923688a-2-757","session_id":"2923688a","time_s":1.514,"rgb_path":"/home/pawel/Documents/HomeBot…
11,614
in 3 · out 62 · cR 11389 · cW 160
$0.0003
55.6s
toolUse
robot_move_base
HINGE_CLEAR drzwi 1: przy ramieniu schowanym, lift=0 wykonaj wymagany offset yaw w stronę obserwowanego zawiasu; krótki ruch bez jazdy
ok
14,290
in 3 · out 161 · cR 11549 · cW 2577 · reason 53
$0.0011
62.3s
toolUse
robot_observe
REACH: po hinge-clear odśwież widok i potwierdź aktualną klamkę g_office, przeszkody oraz stop przed podniesieniem liftu
{"observation_id":"obs-2923688a-3-1971","session_id":"2923688a","time_s":3.942,"rgb_path":"/home/pawel/Documents/HomeBo…
14,385
in 3 · out 57 · cR 14126 · cW 199
$0.0004
74.8s
toolUse
robot_look
Korekta widoku drzwi 1 po yaw: skieruj kamerę na drugą stronę otworu, aby odzyskać widoczną klamkę; bez zmiany bazy
ok
16,050
in 3 · out 143 · cR 14325 · cW 1579 · reason 37
$0.0009
82.3s
toolUse
robot_observe
REACH korekta: pobierz świeżą obserwację po zmianie kamery, sprawdź door_handle g_office i aktualny punkt TCP
{"observation_id":"obs-2923688a-4-2784","session_id":"2923688a","time_s":5.568,"rgb_path":"/home/pawel/Documents/HomeBo…
16,122
in 3 · out 50 · cR 15904 · cW 165
$0.0004
94.1s
toolUse
robot_move_lift
REACH: podnieś pusty, stowed carriage do 0.40 m po hinge-clear; obserwacja wymagana przed TCP
ok
18,642
in 3 · out 101 · cR 16069 · cW 2469 · reason 16
$0.0011
102.3s
toolUse
robot_observe
Po lift: potwierdź aktualny handle_candidate_m względem carriage i stop przed podejściem TCP
{"observation_id":"obs-2923688a-5-6118","session_id":"2923688a","time_s":12.236,"rgb_path":"/home/pawel/Documents/HomeB…
18,715
in 3 · out 42 · cR 18538 · cW 132
$0.0005
113.1s
toolUse
robot_execute_sequence
REACH: ustaw TCP dokładnie na świeżej klamce g_office w arm_carriage; tylko literalny ruch, bez chwytu
ok · move_tcp · F=0.00N · grip=no
21,203
in 3 · out 94 · cR 18670 · cW 2436
$0.0011
122.1s
toolUse
robot_observe
GRASP gate: potwierdź TCP/contact i świeży stan przed uchwyceniem g_office
{"observation_id":"obs-2923688a-6-8246","session_id":"2923688a","time_s":16.492,"rgb_path":"/home/pawel/Documents/HomeB…
21,312
in 3 · out 42 · cR 21106 · cW 161
$0.0005
132.4s
toolUse
robot_door_action
GRASP drzwi 1: uchwyć widoczną klamkę g_office przy potwierdzonym TCP i aktualnej obserwacji
ok
23,320
in 3 · out 88 · cR 8856 · cW 14373
$0.0039
141.9s
toolUse
robot_observe
Po GRASP: sprawdź kontakt, siłę, TCP i stop przed PRESS
{"observation_id":"obs-2923688a-7-8296","session_id":"2923688a","time_s":16.592,"rgb_path":"/home/pawel/Documents/HomeB…
23,527
in 3 · out 36 · cR 23229 · cW 259
$0.0006
152.5s
toolUse
robot_door_action
PRESS gate: naciśnij sprężynową klamkę g_office przed otwieraniem
ok
25,592
in 3 · out 77 · cR 8856 · cW 16656
$0.0044
162.0s
toolUse
robot_observe
Po PRESS: potwierdź zwolnienie zatrzasku, kontakt i stop przed OPEN
{"observation_id":"obs-2923688a-8-8746","session_id":"2923688a","time_s":17.492,"rgb_path":"/home/pawel/Documents/HomeB…
25,807
in 3 · out 39 · cR 25512 · cW 253
$0.0006
172.6s
toolUse
robot_door_action
OPEN gate drzwi 1: po potwierdzonym PRESS otwórz g_office; monitoruj postęp i ewentualne clipped leaf bez resetu
ok
27,853
in 3 · out 105 · cR 8856 · cW 18889 · reason 13
$0.0050
183.1s
toolUse
robot_observe
Po OPEN: zmierz opening_progress, widoczną powierzchnię i wolną krawędź; przygotuj bezpieczny RETREAT przed release
{"observation_id":"obs-2923688a-9-13090","session_id":"2923688a","time_s":26.18,"rgb_path":"/home/pawel/Documents/HomeB…
28,081
in 3 · out 73 · cR 27745 · cW 260 · reason 21
$0.0007
194.3s
toolUse
robot_door_action
RELEASE: opening 1.455 rad jest wystarczające i bez stopu; zwolnij chwyt g_office przed ostrożnym odwrotem
ok
31,226
in 3 · out 172 · cR 7365 · cW 23686 · reason 80
$0.0063
202.3s
toolUse
robot_observe
RELEASE verify: potwierdź pusty chwyt, aktualne skrzydło i korytarz odwrotu; zaplanuj pojedynczy waypoint w workspace
{"observation_id":"obs-2923688a-10-13340","session_id":"2923688a","time_s":26.68,"rgb_path":"/home/pawel/Documents/Home…
31,367
in 3 · out 57 · cR 31051 · cW 256
$0.0008
214.4s
toolUse
robot_execute_sequence
RETREAT krok 1: odsuń TCP 5 cm po aktualnej normalnej kontaktu od widocznej powierzchni skrzydła; pojedynczy waypoint, bez batchu
ok · move_tcp · F=0.00N · grip=no
34,657
in 3 · out 240 · cR 7365 · cW 27049 · reason 133
$0.0072
222.2s
toolUse
robot_observe
Po retreat waypoint: sprawdź TCP, powierzchnię skrzydła, wolną krawędź i czy można bezpiecznie schować ramię
{"observation_id":"obs-2923688a-11-13478","session_id":"2923688a","time_s":26.956,"rgb_path":"/home/pawel/Documents/Hom…
34,641
in 3 · out 52 · cR 34414 · cW 172
$0.0008
235.0s
toolUse
robot_execute_sequence
STOW: po zweryfikowanym odwrocie i pustym chwycie schowaj ramię do pozycji centralnej; nie łącz z jazdą
collision_guard · F=0.00N · grip=no · STOP
37,908
in 3 · out 178 · cR 7365 · cW 30362 · reason 81
$0.0080
24—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981179761645033
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976685926196724
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976303366659072
    }
  },
  "events": [],
  "sim_time_s": 26.95599999999594,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": -1.0509337455288646e-38,
      "handle_angle_rad": -2.4759872750816632e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -4.89310851978414e-09,
      "handle_angle_rad": -1.4401021503756104e-18,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -3.398281465236448e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.424900788786617,
      "handle_angle_rad": -0.0005749136359420521,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -4.561630147315148e-09,
      "handle_angle_rad": -1.6505529347195503e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -4.561630147315148e-09,
      "handle_angle_rad": -1.6505529347195503e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -4.893108519724438e-09,
      "handle_angle_rad": -3.114091550088233e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

_door-reach-fix-001

dom · homebot-dom · 2026-11-03 10:02 · homebot-dom/runs/_door-reach-fix-001
brak wyniku

Brak filmu w tym katalogu.

Brak evaluation/map memory.

omp-door-exit-luna56-001

dom · homebot-dom · 2026-11-03 09:07 · homebot-dom/runs/omp-door-exit-luna56-001
0/3 w koszu

MP4 · 263.0 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt19 calli · $0.029
ag. limity18 req · 8 seq · 19 tools
czas misji102.0s
status agentarobot_stop_latched
calle LLM
19
tool calls
19
koszt zadania
$0.029
tokeny (sum)
347,591
in / out
54 / 2,907
cache R/W
262,200 / 82,430
czas modelu
58.1s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.1s
toolUse
robot_capabilities
DISCOVER: pobierz pełne możliwości v4, ramy, limity, lift i stan bezpieczeństwa
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć misji jako niezweryfikowane notatki; nie używaj jej do współrzędnych
{"revision":0,"agent_notes":null}
8,166
in 3 · out 132 · cR 0 · cW 8031 · reason 29
$0.0022
21.8s
toolUse
robot_observe
SURVEY: świeża obserwacja RGB-D, lidar, drzwi/klamki, odometria i stan stopu; wybór wyłącznie z obrazu
{"observation_id":"obs-b8325fb8-1-350","session_id":"b8325fb8","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,962
in 3 · out 64 · cR 8031 · cW 864 · reason 7
$0.0005
34.7s
toolUse
robot_look
SURVEY: skieruj kamerę wyżej na aktualnie widoczne zamknięte drzwi, aby potwierdzić klamkę, zawias i portal; bez ruchu bazy
ok
Stan operacyjny — etap SURVEY; observation_id=obs-b8325fb8-1-350; ostatnia komenda=obserwacja OK, stop_latched=false; kontrola geometryczna: widoczne zamknięte skrzydło `g_office` i ościeżnica, portal częściowo ujęty, k…
11,757
in 3 · out 326 · cR 8895 · cW 2533 · reason 63
$0.0012
42.1s
toolUse
robot_observe
SURVEY: odczytaj świeży obraz po zmianie widoku, potwierdź klamkę, geometrię portalu, łuk i lidar przed dalszą decyzją
{"observation_id":"obs-b8325fb8-2-757","session_id":"b8325fb8","time_s":1.514,"rgb_path":"/home/pawel/Documents/HomeBot…
11,805
in 3 · out 57 · cR 11428 · cW 317
$0.0004
56.7s
toolUse
mission_memory_write
Zapisz stan SURVEY i pierwotny pomiar zamkniętego portalu bez używania mapy historycznej
{"revision":1,"kind":"agent_mission_notes","notes":"Mission 0ecd25da-5518-44b5-a806-b8358f8d7068. SURVEY: wybrane z bie…
Stan operacyjny — etap SURVEY zakończony; observation_id=obs-b8325fb8-2-757; ostatnia komenda=look+obserwacja OK; kontrola geometryczna: `g_office` zamknięte, klamka `g_office_handle` widoczna, kandydat `[0.7361,0.0620,…
14,795
in 3 · out 527 · cR 11745 · cW 2520 · reason 111
$0.0015
62.9s
toolUse
robot_look
SURVEY/SWEEP_CHECK: uzyskaj boczny widok aktualnych drzwi dla zawiasu, krawędzi i kierunku łuku; bez ruchu bazy
ok
15,012
in 3 · out 97 · cR 14265 · cW 647
$0.0006
72.4s
toolUse
robot_observe
SWEEP_CHECK: świeży odczyt po bocznym widoku; zweryfikuj łuk klamki, zawias, wolną krawędź i margines workspace
{"observation_id":"obs-b8325fb8-3-976","session_id":"b8325fb8","time_s":1.952,"rgb_path":"/home/pawel/Documents/HomeBot…
15,127
in 3 · out 57 · cR 14912 · cW 155
$0.0004
85.3s
toolUse
robot_execute_sequence
REACH przygotowanie: schowaj pusty otwarty chwytak w bezpiecznej pozycji centralnej; bez kontaktu z drzwiami
ok · move_tcp → open_gripper · F=0.00N · grip=no
Stan operacyjny — etap SWEEP_CHECK; observation_id=obs-b8325fb8-3-976; ostatnia komenda=look+obserwacja OK; kontrola geometryczna: pełny widoczny portal i klamka potwierdzone z dwóch kątów, kandydat klamki stabilny (róż…
17,983
in 3 · out 393 · cR 15067 · cW 2520 · reason 130
$0.0014
92.0s
toolUse
robot_observe
REACH: potwierdź pozycję stowed, pusty chwytak, stop i aktualne lidar przed podniesieniem liftu
{"observation_id":"obs-b8325fb8-4-1101","session_id":"b8325fb8","time_s":2.202,"rgb_path":"/home/pawel/Documents/HomeBo…
17,971
in 3 · out 50 · cR 17587 · cW 331
$0.0005
102.6s
toolUse
robot_move_lift
REACH: podnieś pusty, schowany carriage do 0,55 m, aby osiągnąć obserwowaną klamkę około 1,05 m; arm pozostaje stowed
ok
20,523
in 3 · out 94 · cR 17918 · cW 2508
$0.0011
112.4s
toolUse
robot_observe
REACH/SWEEP_CHECK: po podniesieniu liftu pobierz świeży kandydat klamki i potwierdź niezmieniony portal, kontakt oraz stop
{"observation_id":"obs-b8325fb8-5-5685","session_id":"b8325fb8","time_s":11.37,"rgb_path":"/home/pawel/Documents/HomeBo…
20,638
in 3 · out 68 · cR 20426 · cW 141 · reason 9
$0.0005
124.4s
toolUse
robot_execute_sequence
REACH: przesuń TCP jednym krótkim ruchem do świeżo zmierzonej klamki; bez chwytu w tym skrypcie
ok · move_tcp · F=0.00N · grip=no
Stan operacyjny — etap REACH; observation_id=obs-b8325fb8-5-5685; ostatnia komenda=lift 0,55 m OK; kontrola geometryczna: aktualna klamka `[0.7357,0.0582,0.5026]` arm_carriage, world z≈1,0526 m, mieści się w workspace z…
23,341
in 3 · out 303 · cR 20567 · cW 2468 · reason 59
$0.0014
132.7s
toolUse
robot_observe
GRASP gate: sprawdź faktyczną TCP, kontakt, siłę, skrzydło i stop po dojściu do klamki
{"observation_id":"obs-b8325fb8-6-7740","session_id":"b8325fb8","time_s":15.48,"rgb_path":"/home/pawel/Documents/HomeBo…
23,397
in 3 · out 51 · cR 23035 · cW 308
$0.0006
144.0s
toolUse
robot_door_action
GRASP: chwyć widoczną klamkę g_office przy aktualnym TCP; bez ruchu bazy
ok
Stan operacyjny — etap REACH zakończony; observation_id=obs-b8325fb8-6-7740; ostatnia komenda=TCP reach OK; kontrola geometryczna: TCP `[0.735724,0.058157,0.502614]`, świeży kandydat `[0.736187,0.058469,0.502853]`, różn…
25,603
in 3 · out 215 · cR 8895 · cW 16490 · reason 14
$0.0046
152.0s
toolUse
robot_observe
GRASP: potwierdź kontakt po chwycie, brak ruchu skrzydła, siłę i stop
{"observation_id":"obs-b8325fb8-7-7790","session_id":"b8325fb8","time_s":15.58,"rgb_path":"/home/pawel/Documents/HomeBo…
25,806
in 3 · out 44 · cR 25385 · cW 374
$0.0007
163.4s
toolUse
robot_door_action
PRESS: naciśnij sprężynową klamkę g_office przed próbą otwarcia; monitoruj siłę i zatrzask
ok
Stan operacyjny — etap GRASP zakończony; observation_id=obs-b8325fb8-7-7790; ostatnia komenda=grasp OK, kontakt=true, door_grip=`g_office`; kontrola geometryczna: TCP sprzężony przy klamce, skrzydło bez postępu, force=0…
28,013
in 3 · out 178 · cR 8895 · cW 18937
$0.0051
172.2s
toolUse
robot_observe
PRESS: potwierdź zwolnienie zatrzasku, brak ruchu skrzydła przed OPEN, siłę i stop
{"observation_id":"obs-b8325fb8-8-8240","session_id":"b8325fb8","time_s":16.48,"rgb_path":"/home/pawel/Documents/HomeBo…
28,241
in 3 · out 47 · cR 27832 · cW 359
$0.0007
183.6s
toolUse
robot_door_action
OPEN: otwórz zwolnione skrzydło g_office przez sprzężenie z trzymaną klamką; bez ruchu bazy
stopped
Stan operacyjny — etap PRESS zakończony; observation_id=obs-b8325fb8-8-8240; ostatnia komenda=press OK, obrót klamki −0,519 rad, peak_force=1,222 N<3 N, skrzydło bez postępu, stop=false; kontrola geometryczna: zatrzask …
30,451
in 3 · out 204 · cR 7317 · cW 22927 · reason 13
$0.0061
19—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981380690748389
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039768692311981935
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976069837750611
    }
  },
  "events": [
    {
      "event": "door_reach_stop",
      "time_s": 23.68999999999775
    }
  ],
  "sim_time_s": 23.68999999999775,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 1.6313657288692208e-38,
      "handle_angle_rad": -3.68705843007067e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.750254580038996e-09,
      "handle_angle_rad": 1.6786174184838932e-18,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -1.085384840183563e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3960589230022025,
      "handle_angle_rad": -0.518899072202824,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -6.293047321352432e-09,
      "handle_angle_rad": -4.098191617900958e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -6.293047321352432e-09,
      "handle_angle_rad": -4.098191617900958e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.75025457996929e-09,
      "handle_angle_rad": -3.755336285012435e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-exit-luna6-001

dom · homebot-dom · 2026-11-03 09:07 · homebot-dom/runs/omp-door-exit-luna6-001
0/3 w koszu

MP4 · 106.9 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-6-luna
profilgpu
LLM / koszt5 calli · $0.0025
ag. limity5 req · 1 seq · 5 tools
czas misji20.3s
calle LLM
5
tool calls
5
koszt zadania
$0.0025
tokeny (sum)
54,496
in / out
15 / 781
cache R/W
39,729 / 13,971
czas modelu
15.2s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
11.5s
toolUse
robot_capabilities
DISCOVER: retrieve current robot capabilities and calibration
mode=SIMULATION_ONLY
8,066
in 3 · out 28 · cR 0 · cW 8035
$0.0010
22.6s
toolUse
mission_memory_read
Read configured mission memory for context; historical notes are unverified
{"revision":0,"agent_notes":null}
robot_observe
SURVEY: observe current RGB-D, visible door/handle masks, sensors and candidates
{"observation_id":"obs-3eba713c-1-350","session_id":"3eba713c","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
8,888
in 3 · out 80 · cR 8035 · cW 770
$0.0002
32.1s
toolUse
robot_look
Survey visible door and handle; aim camera toward candidate for direct visual confirmation
ok
11,455
in 3 · out 69 · cR 8805 · cW 2578
$0.0004
41.7s
toolUse
robot_observe
SURVEY: inspect updated RGB-D door and handle from raised camera gaze
{"observation_id":"obs-3eba713c-2-1163","session_id":"3eba713c","time_s":2.326,"rgb_path":"/home/pawel/Documents/HomeBo…
11,542
in 3 · out 33 · cR 11383 · cW 123
$0.0001
57.2s
stop
**Status: blocked** — nie potwierdzono otwarcia ani przekroczenia progu. | Etap | observation_id | Wynik ostatniej komendy | Kontrola geometryczna | Następne działanie | |---|---|---|---|---| | DISCOVER | — | Możliwośc…
14,545
in 3 · out 571 · cR 11506 · cW 2465
$0.0007

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981342801044341
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976715024182752
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976084453050983
    }
  },
  "events": [],
  "sim_time_s": 2.3259999999999654,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 7.852686214675603e-38,
      "handle_angle_rad": -4.467852909247484e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -8.548120597307296e-09,
      "handle_angle_rad": 9.868709782741706e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.590678439863688e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -8.548120597294193e-09,
      "handle_angle_rad": 7.800437227746091e-19,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -8.539104001282694e-09,
      "handle_angle_rad": -1.7218714501310728e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -8.539104001282694e-09,
      "handle_angle_rad": -1.7218714501310728e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -8.548120597297659e-09,
      "handle_angle_rad": -6.87372542231557e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-exit-luna6-002

dom · homebot-dom · 2026-11-03 09:07 · homebot-dom/runs/omp-door-exit-luna6-002
0/3 w koszu

MP4 · 145.9 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-6-luna
profilgpu
LLM / koszt14 calli · $0.0081
ag. limity14 req · 5 seq · 14 tools
czas misji58.7s
calle LLM
14
tool calls
14
koszt zadania
$0.0081
tokeny (sum)
242,723
in / out
42 / 2,357
cache R/W
200,849 / 39,475
czas modelu
49.4s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.2s
toolUse
robot_capabilities
DISCOVER: sprawdź możliwości, ramę, podnośnik i limity robota
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj poprzednie notatki misji; traktuj je jako niezweryfikowane
{"revision":0,"agent_notes":null}
8,380
in 3 · out 93 · cR 0 · cW 8284
$0.0011
21.8s
toolUse
robot_observe
SURVEY: wykonaj świeży obraz RGB-D i sensory; ustal widoczne drzwi/klamkę, lidar i portal w ramie
{"observation_id":"obs-8168b573-1-350","session_id":"8168b573","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
9,193
in 3 · out 50 · cR 8284 · cW 856
$0.0002
32.3s
toolUse
robot_look
Kadr pokazuje skrzydło bez uchwytu; zgodnie z operatorem podnieś tilt bliżej 0 i mały pan, bez ruchu bazy
ok
11,763
in 3 · out 93 · cR 9140 · cW 2527
$0.0005
42.8s
toolUse
robot_observe
Obserwuj ponownie po ruchu kamery; szukaj g_office i handle_candidate_m
{"observation_id":"obs-8168b573-2-694","session_id":"8168b573","time_s":1.388,"rgb_path":"/home/pawel/Documents/HomeBot…
11,864
in 3 · out 41 · cR 11667 · cW 153
$0.0002
55.1s
toolUse
robot_look
SURVEY: zmień widok małym pan w lewo przy tilt bliskim 0, aby pokryć portal i stronę zawiasu
ok
Etap SURVEY, obs-8168b573-2-694: operator wskazał g_office; świeży obraz pokazuje skrzydło i handle_candidate_m [0.7361,0.0608,1.0527] w arm_carriage. Komendy look zakończone ok; lift=0, TCP=[0,0,0.45], stowed/empty, st…
14,520
in 3 · out 260 · cR 11820 · cW 2437
$0.0006
62.5s
toolUse
robot_observe
Zbierz świeży RGB-D, widoczne wierzchołki skrzydła, klamkę, portal i lidar po look
{"observation_id":"obs-8168b573-3-882","session_id":"8168b573","time_s":1.764,"rgb_path":"/home/pawel/Documents/HomeBot…
14,629
in 3 · out 49 · cR 14257 · cW 320
$0.0002
74.3s
toolUse
robot_look
SURVEY: szerzej odchyl widok pan ku portalowi; tilt neutralny, bez ruchu bazy
ok
SURVEY, obs-8168b573-3-882: g_office nadal widoczny, handle_candidate_m=(0.7359,0.0647,1.0525), σfloor=0.02m; obraz pokazuje klamkę na prawym wolnym brzegu skrzydła, rama widoczna, lecz nie oba końce portalu/cała szerok…
17,366
in 3 · out 283 · cR 14577 · cW 2503
$0.0006
81.9s
toolUse
robot_observe
Świeża obserwacja po look: pomiar ramy/otworu i lidar, nie używać układu planu
{"observation_id":"obs-8168b573-4-1007","session_id":"8168b573","time_s":2.014,"rgb_path":"/home/pawel/Documents/HomeBo…
17,468
in 3 · out 47 · cR 17080 · cW 338
$0.0002
93.0s
toolUse
robot_move_base
Operator directs retreat if obscured; current frame clips edge and no whole opening. Small reverse step, stowed arm/lift down; lidar fresh obs
ok
20,049
in 3 · out 92 · cR 17418 · cW 2536
$0.0005
102.7s
toolUse
robot_observe
SURVEY: świeżo sprawdź cały otwór/portal, klamkę, pozycję i lidar po cofnięciu
{"observation_id":"obs-8168b573-5-1782","session_id":"8168b573","time_s":3.564,"rgb_path":"/home/pawel/Documents/HomeBo…
20,180
in 3 · out 48 · cR 19954 · cW 175
$0.0002
112.4s
toolUse
robot_look
SURVEY: mały pan na przeciwną stronę, tilt bliżej horyzontu; sprawdź widoczność całej ramy
ok
22,733
in 3 · out 87 · cR 20129 · cW 2514
$0.0006
121.9s
toolUse
robot_observe
Po zmianie spojrzenia zmierz aktualną widoczną ramę, klamkę i lidar
{"observation_id":"obs-8168b573-6-2157","session_id":"8168b573","time_s":4.314,"rgb_path":"/home/pawel/Documents/HomeBo…
22,832
in 3 · out 40 · cR 22643 · cW 146
$0.0003
137.5s
toolUse
mission_memory_write
Zapisz tylko obserwowane notatki bieżącej misji: g_office, częściowa geometria i blokada przed SWEEP_CHECK; nie twierdź że drzwi otwarte
{"revision":1,"kind":"agent_mission_notes","notes":"Mission 8700aaee-59c3-4470-affd-15fc00904db0, ground frame house_gr…
SURVEY, obs-8168b573-6-2157: obraz pokazuje zamknięte skrzydło g_office z obiema pionowymi krawędziami ramy; klamka po prawej stronie kadru, handle_candidate_m=(0.8560,0.0605,1.0522), σ=0.02m. Po cofnięciu -0.12m kamera…
25,434
in 3 · out 691 · cR 9140 · cW 15600
$0.0024
149.0s
stop
**Status: blocked** — zatrzymano na etapie SURVEY, przed SWEEP_CHECK. Nie wykonano chwytu ani nie otwarto drzwi. - **Wybór drzwi:** `g_office`, zgodnie z poleceniem operatora; świeży obraz pokazał zamknięte skrzydło i …
26,312
in 3 · out 483 · cR 24740 · cW 1086
$0.0006

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981446188776418
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039767975788159785
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976194812044184
    }
  },
  "events": [],
  "sim_time_s": 4.313999999999747,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 5.233419132788961e-38,
      "handle_angle_rad": -3.766922525665287e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -6.361194277520085e-09,
      "handle_angle_rad": -8.074294753541548e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -2.7713324962472723e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -6.361194277501247e-09,
      "handle_angle_rad": -1.0567706122206305e-17,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -5.930265093726754e-09,
      "handle_angle_rad": -3.793830901966707e-17,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -5.930265093726754e-09,
      "handle_angle_rad": -3.793830901966707e-17,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -6.361194277505743e-09,
      "handle_angle_rad": -4.683166079702133e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

omp-door-exit-luna-001

dom · homebot-dom · 2026-11-03 07:17 · homebot-dom/runs/omp-door-exit-luna-001
0/3 w koszu

MP4 · 516.5 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
skilldoor-exit-ground
modelopenai/gpt-5.6-luna
profilgpu
LLM / koszt24 calli · $0.052
ag. limity23 req · 12 seq · 25 tools
czas misji128.8s
status agentarobot_stop_latched
calle LLM
24
tool calls
25
koszt zadania
$0.052
tokeny (sum)
521,257
in / out
69 / 2,192
cache R/W
349,185 / 169,811
czas modelu
70.2s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.3s
toolUse
robot_capabilities
Odkryj pełne możliwości robota v4, lift, ramy i limity
mode=SIMULATION_ONLY
mission_memory_read
Odczytaj pamięć bieżącej misji i poprzednie notatki
{"revision":0,"agent_notes":null}
robot_observe
Wykonaj świeżą obserwację RGB-D, lidar, siły i odometrii; szukaj door_handle i door_leaf
{"observation_id":"obs-6ab04f36-1-350","session_id":"6ab04f36","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P…
6,624
in 3 · out 157 · cR 0 · cW 6464 · reason 23
$0.0018
23.8s
toolUse
robot_look
Unieś widok kamery, aby znaleźć klamkę drzwi g_office; ramię pozostaje schowane, lift=0
ok
9,992
in 3 · out 153 · cR 6464 · cW 3372 · reason 61
$0.0012
32.0s
toolUse
robot_observe
Po zmianie widoku wykonaj świeżą obserwację i odczytaj klamkę oraz geometrię skrzydła g_office
{"observation_id":"obs-6ab04f36-2-788","session_id":"6ab04f36","time_s":1.576,"rgb_path":"/home/pawel/Documents/HomeBot…
10,042
in 3 · out 49 · cR 9836 · cW 154
$0.0003
45.9s
toolUse
robot_move_base
Ustaw bazę po stronie zawiasu, poza łukiem skrzydła; mały ruch w lewo (+y), ramię schowane, lift=0
ok
12,742
in 3 · out 221 · cR 9990 · cW 2528 · reason 116
$0.0011
51.7s
toolUse
robot_observe
Sprawdź świeżą geometrię po ustawieniu bazy przed podniesieniem ramienia
{"observation_id":"obs-6ab04f36-3-1972","session_id":"6ab04f36","time_s":3.944,"rgb_path":"/home/pawel/Documents/HomeBo…
12,757
in 3 · out 39 · cR 12518 · cW 197
$0.0003
64.0s
toolUse
robot_move_lift
Podnieś pusty, schowany chwytak do 0,40 m, aby dosięgnąć klamki
ok
15,177
in 3 · out 123 · cR 12715 · cW 2336 · reason 39
$0.0010
72.2s
toolUse
robot_observe
Po podniesieniu wykonaj świeżą obserwację; użyj nowego handle_candidate_m względem aktualnego liftu
{"observation_id":"obs-6ab04f36-4-5306","session_id":"6ab04f36","time_s":10.612,"rgb_path":"/home/pawel/Documents/HomeB…
15,231
in 3 · out 45 · cR 15051 · cW 132
$0.0004
83.6s
toolUse
robot_execute_sequence
Przenieś TCP dokładnie do świeżej, widocznej klamki; bez chwytania w tej sekwencji
ok · move_tcp · F=0.00N · grip=no
17,726
in 3 · out 143 · cR 15183 · cW 2397 · reason 41
$0.0011
92.5s
toolUse
robot_observe
Potwierdź świeżą pozycję TCP i widoczność klamki przed chwytem
{"observation_id":"obs-6ab04f36-5-7509","session_id":"6ab04f36","time_s":15.018,"rgb_path":"/home/pawel/Documents/HomeB…
17,793
in 3 · out 40 · cR 17580 · cW 170
$0.0004
103.0s
toolUse
robot_door_action
Chwyć widoczną klamkę g_office w aktualnym punkcie TCP
ok
20,182
in 3 · out 76 · cR 17750 · cW 2353
$0.0010
111.8s
toolUse
robot_observe
Potwierdź chwyt i stan klamki przed naciśnięciem
{"observation_id":"obs-6ab04f36-6-7559","session_id":"6ab04f36","time_s":15.118,"rgb_path":"/home/pawel/Documents/HomeB…
20,392
in 3 · out 36 · cR 20103 · cW 250
$0.0005
122.3s
toolUse
robot_door_action
Naciśnij sprężynową dźwignię klamki g_office przed otwarciem
ok
22,312
in 3 · out 79 · cR 6464 · cW 15766
$0.0042
133.1s
toolUse
robot_observe
Potwierdź zwolnienie zatrzasku po naciśnięciu, bez zmiany chwytu
{"observation_id":"obs-6ab04f36-7-8009","session_id":"6ab04f36","time_s":16.018,"rgb_path":"/home/pawel/Documents/HomeB…
22,533
in 3 · out 42 · cR 22230 · cW 258
$0.0006
142.6s
toolUse
robot_door_action
Otwórz zwolnione skrzydło g_office ostrożnym ruchem, aby sklasyfikować kierunek
incomplete_motion
24,478
in 3 · out 101 · cR 6464 · cW 17910 · reason 14
$0.0047
153.3s
toolUse
robot_observe
Sprawdź świeżo po próbie otwarcia: ruch skrzydła, prześwit i ewentualną blokadę
{"observation_id":"obs-6ab04f36-8-12353","session_id":"6ab04f36","time_s":24.706,"rgb_path":"/home/pawel/Documents/Home…
24,707
in 3 · out 75 · cR 24374 · cW 255 · reason 24
$0.0006
163.1s
toolUse
robot_door_action
Zwolnij chwyt klamki po zaobserwowanym otwarciu skrzydła; nie poruszaj bazą
ok
28,730
in 3 · out 120 · cR 6464 · cW 22143 · reason 33
$0.0058
172.8s
toolUse
robot_execute_sequence
Po zwolnieniu wycofaj TCP od skrzydła i schowaj ramię, omijając widoczną wolną krawędź
rejected
28,977
in 3 · out 116 · cR 28607 · cW 251
$0.0008
183.5s
toolUse
robot_observe
Po zwolnieniu pobierz świeżą obserwację skrzydła i TCP przed wycofaniem oraz schowaniem ramienia
{"observation_id":"obs-6ab04f36-9-12603","session_id":"6ab04f36","time_s":25.206,"rgb_path":"/home/pawel/Documents/Home…
29,063
in 3 · out 61 · cR 28858 · cW 141 · reason 11
$0.0007
192.7s
toolUse
robot_execute_sequence
Wycofaj TCP na stronę wolnej krawędzi i ustaw ramię w pozycji stowed, bez przechodzenia przez skrzydło
ok · move_tcp → move_tcp · F=0.00N · grip=no
33,043
in 3 · out 115 · cR 6198 · cW 26727
$0.0069
202.5s
toolUse
robot_observe
Zweryfikuj świeżo pozycję stowed, wolny otwór i lidar przed opuszczeniem liftu
{"observation_id":"obs-6ab04f36-10-13452","session_id":"6ab04f36","time_s":26.904,"rgb_path":"/home/pawel/Documents/Hom…
33,158
in 3 · out 45 · cR 32925 · cW 185
$0.0008
212.6s
toolUse
robot_move_lift
Opuść kolumnę do 0 po potwierdzeniu pustego, schowanego ramienia
ok
37,091
in 3 · out 73 · cR 6198 · cW 30817
$0.0079
222.3s
toolUse
robot_observe
Sprawdź świeży przejazd przez otwór: lift=0, ramię schowane, skrzydło i lidar
{"observation_id":"obs-6ab04f36-11-16786","session_id":"6ab04f36","time_s":33.572,"rgb_path":"/home/pawel/Documents/Hom…
37,183
in 3 · out 47 · cR 37015 · cW 118
$0.0008
235.4s
toolUse
robot_move_base
Przejedź krótkim krokiem przez zweryfikowany, otwarty otwór; lift=0 i ramię stowed
collision_guard
41,324
in 3 · out 236 · cR 6198 · cW 34887 · reason 142
$0.0091
24—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981280146128419
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976640387731947
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976187773667362
    }
  },
  "events": [],
  "sim_time_s": 33.571999999995064,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 4.6681310130427247e-39,
      "handle_angle_rad": -3.3082569052034526e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": 9.580950624306587e-09,
      "handle_angle_rad": -3.8652308750660634e-18,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.367204671350822e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -0.9425326793649349,
      "handle_angle_rad": -4.951549702642632e-18,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": 6.013440024407683e-09,
      "handle_angle_rad": -2.7582335435104956e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": 6.013440024407683e-09,
      "handle_angle_rad": -2.7582335435104956e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": 9.580950624184113e-09,
      "handle_angle_rad": 1.5295813173854338e-18,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

door-exit-demo-001

dom · homebot-dom · 2026-11-03 07:12 · homebot-dom/runs/door-exit-demo-001
0/3 w koszu

MP4 · 961.5 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
shirt_rednie0%
towel_greennie0%
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.0039813252899641716
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976779931606757
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976159218065878
    }
  },
  "events": [],
  "sim_time_s": 54.380000000020495,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 5.08842505789936e-39,
      "handle_angle_rad": -3.2897125035720993e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -8.476856318842214e-09,
      "handle_angle_rad": 3.572897573357644e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -4.557005200356637e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -1.3983158459889171,
      "handle_angle_rad": 5.831928264128926e-16,
      "latch_active": false
    },
    "g_wc": {
      "hinge_angle_rad": -7.903080958621409e-09,
      "handle_angle_rad": -7.606343295616982e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -7.903080958621409e-09,
      "handle_angle_rad": -7.606343295616982e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -8.47685631863399e-09,
      "handle_angle_rad": -7.595675901057842e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}

house-preview-smoke

dom · homebot-dom · 2026-11-02 19:07 · homebot-dom/runs/house-preview-smoke
archiwum

MP4 · 2.9 MB · pełny ekran w playerze

Brak evaluation/map memory.

Logi
brak logów
Laundry / live runs

omp-laundry-sonnet55-002

live run · 2026-11-02 17:57 · homebot-lab/runs/omp-laundry-sonnet55-002
częściowo 1/3

MP4 · 162.8 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluetak100%
shirt_rednie0%
towel_greennie0%
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt7 calli · $0.081
ag. limity6 req · 3 seq · 9 tools
czas misji39.0s
status agentarobot_stop_latched
calle LLM
7
tool calls
9
koszt zadania
$0.081
tokeny (sum)
90,487
in / out
1,589 / 2,490
cache R/W
67,822 / 18,586
czas modelu
29.1s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
11.9s
toolUse
robot_capabilities
discover
mode=SIMULATION_ONLY
mission_memory_read
read memory
{"revision":0,"agent_notes":null}
robot_observe
initial observe
{"observation_id":"obs-2ad28cbe-1-350","session_id":"2ad28cbe","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
9,608
in 4 · out 151 · cR 0 · cW 9453
$0.025
26.9s
toolUse
robot_execute_sequence
grasp sock and test lift
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.78N · grip=yes
13,856
in 527 · out 654 · cR 9453 · cW 3222 · reason 416
$0.017
31.8s
toolUse
robot_observe
verify lift
{"observation_id":"obs-2ad28cbe-2-3169","session_id":"2ad28cbe","time_s":6.338,"rgb_path":"/home/pawel/Documents/homebo…
13,599
in 2 · out 52 · cR 12675 · cW 870
$0.0040
46.3s
toolUse
robot_execute_sequence
carry sock over bin and release
ok · move_tcp → move_tcp → move_tcp → open_gripper → wait · F=0.31N · grip=no
16,722
in 527 · out 555 · cR 13545 · cW 2095 · reason 318
$0.013
55.1s
toolUse
robot_observe
verify sock in bin
{"observation_id":"obs-2ad28cbe-3-6352","session_id":"2ad28cbe","time_s":12.704,"rgb_path":"/home/pawel/Documents/homeb…
16,784
in 2 · out 273 · cR 15640 · cW 869 · reason 217
$0.0065
67.3s
toolUse
mission_memory_write
progress
{"revision":1,"kind":"agent_mission_notes","notes":"Mission 920f474b: sock_blue grasped (1 grasp) and released over bin…
robot_execute_sequence
grasp shirt, test lift
collision_guard · F=0.00N · grip=no · STOP
19,918
in 527 · out 805 · cR 16509 · cW 2077 · reason 384
$0.016
7—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07947989592302881
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976656708832238
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976074608248684
    }
  },
  "events": [],
  "sim_time_s": 12.704000000000912,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

omp-laundry-sonnet55-003

live run · 2026-11-02 17:57 · homebot-lab/runs/omp-laundry-sonnet55-003
częściowo 2/3

MP4 · 717.1 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluetak100%
shirt_redtak98%
towel_greennie0%
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt21 calli · $0.509
ag. limity20 req · 11 seq · 24 tools
czas misji143.9s
status agentarobot_stop_latched
calle LLM
21
tool calls
24
koszt zadania
$0.509
tokeny (sum)
495,930
in / out
4,767 / 8,255
cache R/W
329,285 / 153,623
czas modelu
112.4s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.0s
toolUse
robot_capabilities
discover
mode=SIMULATION_ONLY
mission_memory_read
read notes
{"revision":0,"agent_notes":null}
robot_observe
initial observation
{"observation_id":"obs-cc02f55e-1-350","session_id":"cc02f55e","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
9,688
in 4 · out 151 · cR 0 · cW 9533
$0.025
26.2s
toolUse
robot_execute_sequence
grasp sock, test lift
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.94N · grip=yes
13,858
in 527 · out 580 · cR 9533 · cW 3218 · reason 340
$0.016
31.8s
toolUse
robot_observe
verify sock lift
{"observation_id":"obs-cc02f55e-2-2938","session_id":"cc02f55e","time_s":5.876,"rgb_path":"/home/pawel/Documents/homebo…
13,679
in 2 · out 54 · cR 12751 · cW 872
$0.0040
48.5s
toolUse
robot_execute_sequence
raise sock and move toward bin
ok · move_tcp → move_tcp → wait · F=0.29N · grip=yes
17,025
in 527 · out 742 · cR 13623 · cW 2133 · reason 534
$0.015
57.4s
toolUse
robot_observe
check sock
{"observation_id":"obs-cc02f55e-3-5230","session_id":"cc02f55e","time_s":10.46,"rgb_path":"/home/pawel/Documents/homebo…
16,942
in 2 · out 356 · cR 15756 · cW 828 · reason 304
$0.0072
66.8s
toolUse
robot_execute_sequence
drop sock in bin
ok · move_tcp → move_tcp → open_gripper → wait → move_tcp · F=0.30N · grip=no
19,816
in 527 · out 613 · cR 16584 · cW 2092 · reason 374
$0.014
74.3s
toolUse
robot_observe
verify sock in bin
{"observation_id":"obs-cc02f55e-4-6730","session_id":"cc02f55e","time_s":13.46,"rgb_path":"/home/pawel/Documents/homebo…
19,722
in 2 · out 175 · cR 18676 · cW 869 · reason 119
$0.0058
86.5s
toolUse
mission_memory_write
progress
{"revision":1,"kind":"agent_mission_notes","notes":"sock_blue: grasp1 ok, lifted, dropped in bin, visible in bin (parti…
robot_execute_sequence
grasp shirt, test lift
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=1.08N · grip=yes
22,857
in 527 · out 698 · cR 19545 · cW 2087 · reason 304
$0.015
92.2s
toolUse
robot_observe
verify shirt lift
{"observation_id":"obs-cc02f55e-5-10610","session_id":"cc02f55e","time_s":21.22,"rgb_path":"/home/pawel/Documents/homeb…
22,916
in 2 · out 55 · cR 21632 · cW 1227
$0.0058
106.9s
toolUse
robot_execute_sequence
lift shirt high, shift toward bin
ok · move_tcp → move_tcp → wait · F=1.48N · grip=yes
26,109
in 527 · out 625 · cR 22859 · cW 2098 · reason 413
$0.015
112.7s
toolUse
robot_observe
check shirt
{"observation_id":"obs-cc02f55e-6-13977","session_id":"cc02f55e","time_s":27.954,"rgb_path":"/home/pawel/Documents/home…
25,844
in 2 · out 52 · cR 24957 · cW 833
$0.0051
1212.2s
toolUse
robot_execute_sequence
shift shirt toward bin
ok · move_tcp → wait · F=1.47N · grip=yes
29,081
in 527 · out 1191 · cR 0 · cW 27363 · reason 1007
$0.081
132.8s
toolUse
robot_observe
check
{"observation_id":"obs-cc02f55e-7-15074","session_id":"cc02f55e","time_s":30.148,"rgb_path":"/home/pawel/Documents/home…
28,213
in 2 · out 49 · cR 27363 · cW 799
$0.0052
146.9s
toolUse
robot_execute_sequence
move shirt over bin center and release
ok · move_tcp → move_tcp → open_gripper → wait · F=1.49N · grip=no
30,794
in 527 · out 566 · cR 0 · cW 29701 · reason 347
$0.081
153.7s
toolUse
robot_execute_sequence
retract arm up
rejected
30,728
in 2 · out 179 · cR 29701 · cW 846
$0.0069
162.3s
toolUse
robot_observe
verify shirt in bin
{"observation_id":"obs-cc02f55e-8-16844","session_id":"cc02f55e","time_s":33.688,"rgb_path":"/home/pawel/Documents/home…
30,809
in 2 · out 56 · cR 30547 · cW 204
$0.0041
1712.1s
toolUse
robot_execute_sequence
stow arm before driving
ok · move_tcp → move_tcp · F=0.00N · grip=no
mission_memory_write
progress
{"revision":2,"kind":"agent_mission_notes","notes":"sock_blue and shirt_red released in bin, visible in bin image (part…
33,796
in 527 · out 991 · cR 0 · cW 32278 · reason 625
$0.092
187.0s
toolUse
robot_move_base
approach towel
rejected
34,062
in 2 · out 580 · cR 32278 · cW 1202 · reason 384
$0.012
193.1s
toolUse
robot_observe
post-stow
{"observation_id":"obs-cc02f55e-9-19030","session_id":"cc02f55e","time_s":38.06,"rgb_path":"/home/pawel/Documents/homeb…
33,754
in 2 · out 52 · cR 33480 · cW 220
$0.0044
207.0s
toolUse
robot_move_base
approach towel forward
collision_guard
36,237
in 527 · out 490 · cR 0 · cW 35220 · reason 295
$0.094
21—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.0672215530967116
    },
    "shirt_red": {
      "fraction_in_bin": 0.984,
      "delivered": true,
      "max_z_m": 0.10447377161489912
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976073452433393
    }
  },
  "events": [],
  "sim_time_s": 38.06000000000055,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

omp-laundry-sonnet55-towel-001

live run · 2026-11-02 17:57 · homebot-lab/runs/omp-laundry-sonnet55-towel-001
częściowo 2/3

MP4 · 698.4 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluetak100%
shirt_redtak93%
towel_greennie0%
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt11 calli · $0.123
ag. limity10 req · 5 seq · 13 tools
czas misji79.8s
status agentarobot_stop_latched
calle LLM
11
tool calls
13
koszt zadania
$0.123
tokeny (sum)
182,023
in / out
2,647 / 4,050
cache R/W
150,667 / 24,659
czas modelu
50.6s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
11.9s
toolUse
robot_capabilities
discover
mode=SIMULATION_ONLY
mission_memory_read
read notes
{"revision":0,"agent_notes":null}
robot_observe
initial observation
{"observation_id":"obs-e879853c-1-350","session_id":"e879853c","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
9,706
in 4 · out 151 · cR 0 · cW 9551
$0.025
26.6s
toolUse
robot_execute_sequence
grasp sock
ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.84N · grip=yes
13,927
in 527 · out 633 · cR 9551 · cW 3216 · reason 392
$0.016
31.8s
toolUse
robot_observe
verify sock lift
{"observation_id":"obs-e879853c-2-3135","session_id":"e879853c","time_s":6.27,"rgb_path":"/home/pawel/Documents/homebot…
13,702
in 2 · out 54 · cR 12767 · cW 879
$0.0040
47.7s
toolUse
robot_execute_sequence
sock to bin
ok · move_tcp → move_tcp → open_gripper → wait → move_tcp · F=0.29N · grip=no
16,938
in 527 · out 671 · cR 13646 · cW 2094 · reason 442
$0.014
54.3s
toolUse
robot_observe
verify sock delivery
{"observation_id":"obs-e879853c-3-8034","session_id":"e879853c","time_s":16.068,"rgb_path":"/home/pawel/Documents/homeb…
16,810
in 2 · out 208 · cR 15740 · cW 860 · reason 152
$0.0058
66.9s
toolUse
robot_execute_sequence
grasp shirt test lift
ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.78N · grip=yes
19,814
in 527 · out 621 · cR 16600 · cW 2066 · reason 374
$0.014
72.6s
toolUse
robot_observe
verify shirt lift
{"observation_id":"obs-e879853c-4-11839","session_id":"e879853c","time_s":23.678,"rgb_path":"/home/pawel/Documents/home…
19,609
in 2 · out 55 · cR 18666 · cW 886
$0.0046
86.5s
toolUse
robot_execute_sequence
shirt to bin
ok · move_tcp → move_tcp → move_tcp → open_gripper → wait → move_tcp · F=1.57N · grip=no
22,712
in 527 · out 558 · cR 19552 · cW 2075 · reason 305
$0.014
92.2s
toolUse
robot_observe
verify shirt delivery
{"observation_id":"obs-e879853c-5-19653","session_id":"e879853c","time_s":39.306,"rgb_path":"/home/pawel/Documents/home…
22,576
in 2 · out 56 · cR 21627 · cW 891
$0.0050
1010.1s
toolUse
mission_memory_write
progress
{"revision":1,"kind":"agent_mission_notes","notes":"Mission 7fb945b0: sock_blue wlozona do kosza (widoczna w koszu), sh…
robot_move_base
approach towel, TCP stowed
collision_guard
26,229
in 527 · out 1043 · cR 22518 · cW 2141 · reason 623
$0.019
11—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07711928977352428
    },
    "shirt_red": {
      "fraction_in_bin": 0.934,
      "delivered": true,
      "max_z_m": 0.2636439652320441
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976073846444057
    }
  },
  "events": [],
  "sim_time_s": 39.30600000000207,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

omp-laundry-sonnet55-001

live run · 2026-11-02 17:41 · homebot-lab/runs/omp-laundry-sonnet55-001
częściowo 2/3

MP4 · 987.9 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluetak100%
shirt_redtak93%
towel_greennie0%
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt26 calli · $0.831
ag. limity26 req · 12 seq · 30 tools
czas misji183.7s
calle LLM
26
tool calls
30
koszt zadania
$0.831
tokeny (sum)
734,697
in / out
6,354 / 9,059
cache R/W
446,068 / 273,216
czas modelu
135.8s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.2s
toolUse
robot_capabilities
discover
mode=SIMULATION_ONLY
mission_memory_read
read memory
{"revision":0,"agent_notes":null}
robot_observe
initial observation
{"observation_id":"obs-a6b0cf03-1-350","session_id":"a6b0cf03","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
9,582
in 4 · out 151 · cR 0 · cW 9427
$0.025
26.5s
toolUse
robot_execute_sequence
grasp sock, test lift
ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.79N · grip=yes
13,704
in 527 · out 528 · cR 9427 · cW 3222 · reason 280
$0.015
32.4s
toolUse
robot_observe
verify lift
{"observation_id":"obs-a6b0cf03-2-3227","session_id":"a6b0cf03","time_s":6.454,"rgb_path":"/home/pawel/Documents/homebo…
13,586
in 2 · out 52 · cR 12649 · cW 883
$0.0040
47.2s
toolUse
robot_execute_sequence
move sock over bin
ok · move_tcp → move_tcp · F=0.28N · grip=yes
16,725
in 527 · out 569 · cR 13532 · cW 2097 · reason 382
$0.013
54.9s
toolUse
robot_observe
check position
{"observation_id":"obs-a6b0cf03-3-5090","session_id":"a6b0cf03","time_s":10.18,"rgb_path":"/home/pawel/Documents/homebo…
16,703
in 2 · out 271 · cR 15629 · cW 801 · reason 220
$0.0063
64.5s
toolUse
robot_execute_sequence
lower slightly and release sock
ok · move_tcp → open_gripper → wait → move_tcp · F=0.29N · grip=no
19,389
in 527 · out 340 · cR 16430 · cW 2092 · reason 129
$0.011
72.1s
toolUse
robot_observe
verify sock in bin
{"observation_id":"obs-a6b0cf03-4-6575","session_id":"a6b0cf03","time_s":13.15,"rgb_path":"/home/pawel/Documents/homebo…
19,413
in 2 · out 55 · cR 18522 · cW 834
$0.0045
88.4s
toolUse
mission_memory_write
progress
{"revision":1,"kind":"agent_mission_notes","notes":"Mission 41592555. sock_blue: 1 grasp, lifted, released over bin; vi…
robot_execute_sequence
grasp shirt, test lift
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.81N · grip=yes
22,858
in 527 · out 882 · cR 19356 · cW 2093 · reason 467
$0.017
92.0s
toolUse
robot_observe
verify shirt lift
{"observation_id":"obs-a6b0cf03-5-9974","session_id":"a6b0cf03","time_s":19.948,"rgb_path":"/home/pawel/Documents/homeb…
22,772
in 2 · out 55 · cR 21449 · cW 1266
$0.0059
105.8s
toolUse
robot_execute_sequence
raise shirt and move above bin
ok · move_tcp → move_tcp → move_tcp · F=1.56N · grip=yes
25,745
in 527 · out 408 · cR 22715 · cW 2095 · reason 193
$0.013
113.7s
toolUse
robot_observe
check shirt over bin
{"observation_id":"obs-a6b0cf03-6-13958","session_id":"a6b0cf03","time_s":27.916,"rgb_path":"/home/pawel/Documents/home…
25,703
in 2 · out 55 · cR 24810 · cW 836
$0.0051
126.2s
toolUse
robot_execute_sequence
lower, release shirt, retract
ok · move_tcp → open_gripper → wait → move_tcp · F=1.54N · grip=no
28,230
in 527 · out 439 · cR 0 · cW 27264 · reason 226
$0.074
133.0s
toolUse
robot_observe
verify shirt in bin
{"observation_id":"obs-a6b0cf03-7-15803","session_id":"a6b0cf03","time_s":31.606,"rgb_path":"/home/pawel/Documents/home…
28,159
in 2 · out 56 · cR 27264 · cW 837
$0.0054
147.9s
toolUse
mission_memory_write
progress
{"revision":2,"kind":"agent_mission_notes","notes":"sock and shirt released over bin, both visible in bin in RGB (not h…
robot_execute_sequence
stow arm
ok · move_tcp · F=0.00N · grip=no
30,816
in 527 · out 638 · cR 0 · cW 29651 · reason 314
$0.082
156.8s
toolUse
robot_move_base
approach towel
rejected
31,351
in 2 · out 557 · cR 29651 · cW 1141 · reason 361
$0.011
163.1s
toolUse
robot_observe
fresh obs
{"observation_id":"obs-a6b0cf03-8-17452","session_id":"a6b0cf03","time_s":34.904,"rgb_path":"/home/pawel/Documents/home…
31,067
in 2 · out 53 · cR 30792 · cW 220
$0.0042
177.0s
toolUse
robot_move_base
approach towel
ok
33,598
in 527 · out 525 · cR 0 · cW 32546 · reason 329
$0.088
185.7s
toolUse
robot_observe
observe after move
{"observation_id":"obs-a6b0cf03-9-19667","session_id":"a6b0cf03","time_s":39.334,"rgb_path":"/home/pawel/Documents/home…
33,513
in 2 · out 141 · cR 32546 · cW 824 · reason 88
$0.0067
196.4s
toolUse
robot_execute_sequence
towel grasp attempt 1, small test lift
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.85N · grip=yes
35,601
in 527 · out 432 · cR 0 · cW 34642 · reason 184
$0.092
202.2s
toolUse
robot_observe
verify towel lift
{"observation_id":"obs-a6b0cf03-10-23019","session_id":"a6b0cf03","time_s":46.038,"rgb_path":"/home/pawel/Documents/hom…
35,575
in 2 · out 54 · cR 34642 · cW 877
$0.0062
215.9s
toolUse
robot_execute_sequence
higher lift test, check snag
ok · move_tcp → wait · F=1.08N · grip=yes
37,632
in 527 · out 302 · cR 0 · cW 36803 · reason 119
$0.096
222.6s
toolUse
robot_observe
check towel rise
{"observation_id":"obs-a6b0cf03-11-23725","session_id":"a6b0cf03","time_s":47.45,"rgb_path":"/home/pawel/Documents/home…
37,653
in 2 · out 53 · cR 36803 · cW 795
$0.0062
2311.3s
toolUse
robot_execute_sequence
lift towel higher, check for snag via force/geometry
ok · move_tcp → wait · F=1.46N · grip=yes
40,259
in 527 · out 849 · cR 0 · cW 38883 · reason 658
$0.107
242.1s
toolUse
robot_observe
check towel
{"observation_id":"obs-a6b0cf03-12-24431","session_id":"a6b0cf03","time_s":48.862,"rgb_path":"/home/pawel/Documents/hom…
39,739
in 2 · out 51 · cR 38883 · cW 803
$0.0064
257.9s
toolUse
mission_memory_write
final notes
{"revision":3,"kind":"agent_mission_notes","notes":"Mission 41592555 final. sock_blue: 1 grasp, delivered - visible in …
robot_stop
Suspected towel snag: stop attempt, preserve load
stopped
42,260
in 527 · out 765 · cR 0 · cW 40968 · reason 380
$0.111
267.9s
stop
Zebrałem do pojemnika skarpetę i koszulkę. Ręcznika nie udało się dostarczyć, więc wynik jest częściowy. **Skarpeta (`sock_blue`)** - Jeden chwyt, test podniesienia potwierdził kontakt i wzrost skarpety. - Przeniosłem …
43,064
in 2 · out 778 · cR 40968 · cW 1316
$0.015

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07434399081902064
    },
    "shirt_red": {
      "fraction_in_bin": 0.934,
      "delivered": true,
      "max_z_m": 0.26365402367562407
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.4751748183374354
    }
  },
  "events": [],
  "sim_time_s": 48.86200000001375,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

omp-laundry-openrouter-002

live run · 2026-11-02 14:02 · homebot-lab/runs/omp-laundry-openrouter-002
mapa częściowa · 0 ścian · 4 obj

MP4 · 1.5 MB · pełny ekran w playerze

room room_A · rev 3
wymiarwartośćstatus
width—opposing_planes_not_observed
length—opposing_planes_not_observed
height—floor_or_ceiling_not_observed

ściany: —
obiekty: desk01, cabinet01, chair01, collection_bin

skilllaundry
modelopenai/gpt-6-astra
profilgpu
LLM / koszt36 calli · $2.363
ag. limity36 req · 10 seq · 35 tools
czas misji208.0s
status agentaError: 402 This request would exceed your available credits given your current in-flight requests. Retry after in-flight requests settle, or add credits. retry-after-ms=120000
calle LLM
36
tool calls
35
koszt zadania
$2.363
tokeny (sum)
589,244
in / out
105 / 3,759
cache R/W
447,205 / 138,175
czas modelu
159.9s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
12.6s
toolUse
robot_capabilities
Odkryj aktualny kontrakt robota, ograniczenia i pojemnik
mode=SIMULATION_ONLY
4,941
in 3 · out 36 · cR 0 · cW 4902
$0.063
22.7s
toolUse
mission_memory_read
Odczytaj mapę i niezweryfikowane notatki misji
{"revision":0,"agent_notes":null}
5,542
in 3 · out 37 · cR 4902 · cW 600
$0.014
32.3s
toolUse
robot_observe
Sprawdź obraz RGB-D, ubrania, kontakt, bazę i przeszkody
{"observation_id":"obs-54027867-1-350","session_id":"54027867","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
5,602
in 3 · out 37 · cR 5502 · cW 60
$0.0081
44.4s
toolUse
room_measure
Zapisz pierwszy pomiar widocznego obszaru bez zgadywania niewidocznych wymiarów
{"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
Widzę skarpetę, koszulkę i częściowo widoczny ręcznik. Zbieram je pojedynczo, sprawdzając chwyt krótkim podniesieniem. Przy oznakach zaczepienia przerwę pracę.
7,653
in 3 · out 127 · cR 5562 · cW 1961 · reason 18
$0.036
55.9s
toolUse
mission_memory_write
Zapisz plan i pierwszy skrypt przed próbą
{"revision":1,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea; SIM v3 unified-rgbd-v…
7,996
in 3 · out 210 · cR 7523 · cW 260
$0.021
63.9s
toolUse
robot_execute_sequence
Chwyć skarpetę i wykonaj test podniesienia o 8 cm
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.79N · grip=yes
8,347
in 3 · out 127 · cR 7783 · cW 434
$0.020
73.5s
toolUse
robot_observe
Potwierdź kontakt i uniesienie skarpety po próbie
{"observation_id":"obs-54027867-2-3013","session_id":"54027867","time_s":6.026,"rgb_path":"/home/pawel/Documents/homebo…
8,456
in 3 · out 34 · cR 8217 · cW 202
$0.012
83.0s
toolUse
room_measure
Drugi pomiar z nowej obserwacji, zachowaj niepewne wymiary
{"memory_revision":2,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
10,422
in 3 · out 43 · cR 8419 · cW 1957
$0.035
95.8s
toolUse
mission_memory_write
Zapisz potwierdzony test i plan odłożenia skarpety
{"revision":2,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea. sock_blue attempt1 ap…
10,793
in 3 · out 218 · cR 10376 · cW 196
$0.024
103.8s
toolUse
robot_execute_sequence
Przenieś skarpetę nad rant, odłóż i schowaj pusty chwytak
ok · move_tcp → move_tcp → move_tcp → open_gripper → wait → move_tcp · F=0.29N · grip=no
11,163
in 3 · out 142 · cR 10572 · cW 446
$0.023
112.7s
toolUse
robot_observe
Sprawdź skarpetę w pojemniku i stan po odłożeniu
{"observation_id":"obs-54027867-3-8606","session_id":"54027867","time_s":17.212,"rgb_path":"/home/pawel/Documents/homeb…
11,277
in 3 · out 36 · cR 11018 · cW 220
$0.016
124.2s
toolUse
room_measure
Trzeci pomiar unikalnej obserwacji z właściwą rewizją mapy
{"memory_revision":3,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
13,229
in 3 · out 42 · cR 11238 · cW 1946
$0.038
139.9s
toolUse
mission_memory_write
Zapisz wynik skarpety i plan podejścia do koszulki
{"revision":3,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea. sock_blue 1 grasp/1 a…
13,671
in 3 · out 289 · cR 13184 · cW 195 · reason 108
$0.030
143.5s
toolUse
robot_move_base
Podejdź krótkim ruchem do koszulki ze schowanym ramieniem
ok
13,828
in 3 · out 78 · cR 13379 · cW 368
$0.022
154.2s
toolUse
robot_observe
Zaktualizuj punkty chwytu koszulki i wolną przestrzeń po dojeździe
{"observation_id":"obs-54027867-4-10004","session_id":"54027867","time_s":20.008,"rgb_path":"/home/pawel/Documents/home…
13,960
in 3 · out 41 · cR 13747 · cW 169
$0.018
167.2s
toolUse
mission_memory_write
Zapisz skrypt pierwszego testu koszulki
{"revision":4,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea. sock_blue delivery su…
16,040
in 3 · out 247 · cR 13916 · cW 1874 · reason 54
$0.050
174.1s
toolUse
robot_execute_sequence
Chwyć koszulkę i unieś testowo
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.81N · grip=yes
16,314
in 3 · out 125 · cR 15790 · cW 396
$0.027
183.9s
toolUse
robot_observe
Sprawdź testowe uniesienie koszulki
{"observation_id":"obs-54027867-5-13212","session_id":"54027867","time_s":26.424,"rgb_path":"/home/pawel/Documents/home…
16,419
in 3 · out 30 · cR 16186 · cW 200
$0.020
195.9s
toolUse
mission_memory_write
Zapisz wynik testu koszulki i pionowe podniesienie
{"revision":5,"kind":"agent_mission_notes","notes":"sock_blue delivered observationally obs3, 1 attempt. shirt_red atte…
18,534
in 3 · out 177 · cR 16386 · cW 1968 · reason 27
$0.050
203.4s
toolUse
robot_execute_sequence
Podnieś koszulkę pionowo dla prześwitu nad rantem
ok · move_tcp → wait · F=1.44N · grip=yes
18,748
in 3 · out 85 · cR 18354 · cW 306
$0.026
213.3s
toolUse
robot_observe
Sprawdź swobodny zwis koszulki i utrzymanie kontaktu
{"observation_id":"obs-54027867-6-15251","session_id":"54027867","time_s":30.502,"rgb_path":"/home/pawel/Documents/home…
18,849
in 3 · out 36 · cR 18660 · cW 150
$0.022
226.5s
toolUse
mission_memory_write
Zapisz przeniesienie nad pojemnik po poprawnym podniesieniu
{"revision":6,"kind":"agent_mission_notes","notes":"sock_blue delivery supported obs3. shirt_red attempt1 lifted freely…
20,469
in 3 · out 163 · cR 4778 · cW 15525 · reason 18
$0.207
233.3s
toolUse
robot_execute_sequence
Przenieś wiszącą koszulkę nad środek pojemnika
ok · move_tcp → wait · F=1.55N · grip=yes
20,683
in 3 · out 83 · cR 20303 · cW 294
$0.028
243.2s
toolUse
robot_observe
Sprawdź położenie koszulki nad pojemnikiem przed puszczeniem
{"observation_id":"obs-54027867-7-18648","session_id":"54027867","time_s":37.296,"rgb_path":"/home/pawel/Documents/home…
20,785
in 3 · out 37 · cR 20597 · cW 148
$0.024
255.4s
toolUse
robot_look
Skieruj kamerę na trzymaną koszulkę nad koszem; brak detekcji nie oznacza dostawy
ok
22,070
in 3 · out 82 · cR 4778 · cW 17207
$0.224
263.2s
toolUse
robot_observe
Obejrzyj koszulkę i kosz w nowym kierunku kamery
{"observation_id":"obs-54027867-8-19373","session_id":"54027867","time_s":38.746,"rgb_path":"/home/pawel/Documents/home…
22,162
in 3 · out 38 · cR 21985 · cW 136
$0.026
274.8s
toolUse
mission_memory_write
Zapisz widoczne ustawienie nad koszem i skrypt odłożenia
{"revision":7,"kind":"agent_mission_notes","notes":"sock_blue delivery supported obs3 and8. shirt_red attempt1, obs8 co…
23,569
in 3 · out 151 · cR 4778 · cW 18637
$0.245
283.3s
toolUse
robot_execute_sequence
Opuść koszulkę do pojemnika, puść i wycofaj ramię
ok · move_tcp → open_gripper → wait → move_tcp · F=1.62N · grip=no
23,835
in 3 · out 106 · cR 23415 · cW 311
$0.033
294.4s
toolUse
robot_observe
Zweryfikuj koszulkę po zwolnieniu chwytu i osiadaniu
{"observation_id":"obs-54027867-9-22828","session_id":"54027867","time_s":45.656,"rgb_path":"/home/pawel/Documents/home…
23,945
in 3 · out 38 · cR 23726 · cW 178
$0.028
3011.0s
toolUse
mission_memory_write
Utrwal dwie zaobserwowane dostawy i plan dojazdu do ręcznika
{"revision":8,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea. sock_blue 1 grasp and…
Skarpeta i koszulka są widoczne wewnątrz pojemnika po puszczeniu chwytaka. Pozostał ręcznik — podejdę bliżej i sprawdzę go krótkim podniesieniem.
25,517
in 3 · out 330 · cR 4778 · cW 20406 · reason 77
$0.276
315.4s
toolUse
robot_look
Obejrzyj kierunek dojazdu do ręcznika
ok
25,704
in 3 · out 70 · cR 25184 · cW 447
$0.034
322.9s
toolUse
robot_observe
Sprawdź ręcznik, meble i drogę podejścia
{"observation_id":"obs-54027867-10-23960","session_id":"54027867","time_s":47.92,"rgb_path":"/home/pawel/Documents/home…
25,798
in 3 · out 34 · cR 25631 · cW 130
$0.029
333.8s
toolUse
robot_move_base
Podejdź do ręcznika po widocznej wolnej podłodze
ok
27,062
in 3 · out 77 · cR 4778 · cW 22204
$0.286
343.2s
toolUse
robot_observe
Wyznacz aktualny dostępny punkt ręcznika po dojeździe
{"observation_id":"obs-54027867-11-25753","session_id":"54027867","time_s":51.506,"rgb_path":"/home/pawel/Documents/hom…
27,183
in 3 · out 35 · cR 26982 · cW 163
$0.031
358.6s
toolUse
mission_memory_write
Zapisz częściowy wynik i ostrożny test ręcznika przed wykonaniem
{"revision":9,"kind":"agent_mission_notes","notes":"Mission bf4778d4-6f32-4fe4-be37-57909e127fea. Collected observation…
28,678
in 3 · out 318 · cR 4778 · cW 23579 · reason 45
$0.315
36693ms
error
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.0729402655264473
    },
    "shirt_red": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.10479193141223803
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976073828077041
    }
  },
  "events": [],
  "sim_time_s": 51.50600000001698,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

omp-laundry-openrouter-001

live run · 2026-11-02 14:02 · homebot-lab/runs/omp-laundry-openrouter-001
mapa częściowa · 0 ścian · 4 obj

MP4 · 1.0 MB · pełny ekran w playerze

room room_A · rev 3
wymiarwartośćstatus
width—opposing_planes_not_observed
length—opposing_planes_not_observed
height—floor_or_ceiling_not_observed

ściany: —
obiekty: desk01, cabinet01, chair01, collection_bin

skilllaundry
modelopenai/gpt-6-astra
profilgpu
LLM / koszt31 calli · $1.673
ag. limity30 req · 9 seq · 30 tools
czas misji182.5s
status agentarequest_budget_exceeded
calle LLM
31
tool calls
30
koszt zadania
$1.673
tokeny (sum)
464,597
in / out
90 / 3,082
cache R/W
369,565 / 91,860
czas modelu
146.5s
Calle LLM na zadanie
#czasco zrobił (tool + wynik)tokenykoszt
13.4s
toolUse
robot_capabilities
Odkryj aktualny kontrakt robota i limity bezpiecznego zbierania ubrań
mode=SIMULATION_ONLY
4,939
in 3 · out 42 · cR 0 · cW 4894
$0.063
24.1s
toolUse
mission_memory_read
Odczytaj mapę i niezweryfikowane notatki misji
{"revision":0,"agent_notes":null}
5,540
in 3 · out 37 · cR 4894 · cW 606
$0.014
32.2s
toolUse
robot_observe
Obejrzyj ubrania, pojemnik, kontakt i otoczenie przed pierwszym ruchem
{"observation_id":"obs-e46a2d2e-1-350","session_id":"e46a2d2e","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l…
5,604
in 3 · out 41 · cR 5500 · cW 60
$0.0083
44.8s
toolUse
room_measure
Zapisz pierwszy pomiar widocznego otoczenia, bez wnioskowania o niewidocznych wymiarach
{"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
7,589
in 3 · out 48 · cR 5560 · cW 1978
$0.033
58.5s
toolUse
mission_memory_write
Zapisz plan i skrypt pierwszego testu chwytu
{"revision":1,"kind":"agent_mission_notes","notes":"Mission af1c961c-95e3-4637-8897-9400c45dea6e; SIMULATION v3, calibr…
Zacznę od odsłoniętej skarpety. Każde ubranie najpierw lekko uniosę; przy oznakach zaczepienia przerwę zbieranie.
8,073
in 3 · out 331 · cR 7538 · cW 201 · reason 13
$0.027
63.4s
toolUse
robot_execute_sequence
Chwyć środek skarpety i wykonaj test podniesienia o 8 cm
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.79N · grip=yes
8,472
in 3 · out 132 · cR 7739 · cW 598
$0.022
72.9s
toolUse
robot_observe
Sprawdź kontakt i rzeczywiste uniesienie skarpety po teście
{"observation_id":"obs-e46a2d2e-2-3013","session_id":"e46a2d2e","time_s":6.026,"rgb_path":"/home/pawel/Documents/homebo…
8,583
in 3 · out 36 · cR 8337 · cW 207
$0.013
84.0s
toolUse
room_measure
Drugi pomiar z nowej obserwacji; zachowaj nieznane wymiary
{"memory_revision":2,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
10,561
in 3 · out 42 · cR 8544 · cW 1972
$0.035
98.8s
toolUse
mission_memory_write
Zapisz udany test i plan odłożenia skarpety
{"revision":2,"kind":"agent_mission_notes","notes":"Mission af1c961c-95e3-4637-8897-9400c45dea6e v3. Bin world(-.48,-.9…
10,977
in 3 · out 263 · cR 10516 · cW 195 · reason 51
$0.026
103.3s
toolUse
robot_execute_sequence
Przenieś sprawdzoną skarpetę nad pojemnik i odłóż
ok · move_tcp → move_tcp → move_tcp → open_gripper → wait · F=0.29N · grip=no
11,278
in 3 · out 129 · cR 10711 · cW 435
$0.023
113.2s
toolUse
robot_observe
Potwierdź położenie skarpety po zwolnieniu chwytu
{"observation_id":"obs-e46a2d2e-3-6663","session_id":"e46a2d2e","time_s":13.326,"rgb_path":"/home/pawel/Documents/homeb…
11,389
in 3 · out 36 · cR 11146 · cW 204
$0.016
123.1s
toolUse
room_measure
Trzeci pomiar unikalnej obserwacji z właściwą rewizją mapy
{"memory_revision":3,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"…
13,363
in 3 · out 42 · cR 11350 · cW 1968
$0.038
136.7s
toolUse
mission_memory_write
Zapisz dostawę skarpety oraz przygotowanie do podjazdu po koszulkę
{"revision":3,"kind":"agent_mission_notes","notes":"Mission af1c961c-95e3-4637-8897-9400c45dea6e. Observed delivery soc…
13,751
in 3 · out 235 · cR 13318 · cW 195 · reason 31
$0.028
143.7s
toolUse
robot_execute_sequence
Wycofaj puste ramię i schowaj je przed jazdą
ok · move_tcp → move_tcp · F=0.00N · grip=no
14,019
in 3 · out 91 · cR 13513 · cW 412
$0.023
153.2s
toolUse
robot_observe
Sprawdź schowanie ramienia i wolny korytarz jazdy
{"observation_id":"obs-e46a2d2e-4-9127","session_id":"e46a2d2e","time_s":18.254,"rgb_path":"/home/pawel/Documents/homeb…
14,118
in 3 · out 35 · cR 13925 · cW 155
$0.018
163.5s
toolUse
robot_move_base
Podjedź wolnym korytarzem bliżej środka koszulki
ok
16,124
in 3 · out 79 · cR 14080 · cW 1962
$0.043
178.7s
toolUse
robot_observe
Odśwież punkty chwytu po przesunięciu bazy
{"observation_id":"obs-e46a2d2e-5-10714","session_id":"e46a2d2e","time_s":21.428,"rgb_path":"/home/pawel/Documents/home…
16,243
in 3 · out 34 · cR 16042 · cW 164
$0.020
186.9s
toolUse
mission_memory_write
Zapisz test chwytu koszulki i dotychczasowy wynik
{"revision":4,"kind":"agent_mission_notes","notes":"Mission af1c961c-95e3-4637-8897-9400c45dea6e. Sock_blue delivery se…
18,325
in 3 · out 252 · cR 16206 · cW 1864 · reason 20
$0.052
193.9s
toolUse
robot_execute_sequence
Wykonaj pierwszy chwyt koszulki i niewielkie podniesienie testowe
ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.83N · grip=yes
18,679
in 3 · out 132 · cR 18070 · cW 474
$0.031
207.2s
toolUse
robot_observe
Sprawdź, czy uniosła się właściwa koszulka i czy nie jest zaczepiona
{"observation_id":"obs-e46a2d2e-6-14053","session_id":"e46a2d2e","time_s":28.106,"rgb_path":"/home/pawel/Documents/home…
18,794
in 3 · out 40 · cR 18544 · cW 207
$0.023
217.0s
toolUse
mission_memory_write
Zapisz potwierdzone podniesienie i skrypt schowania z ładunkiem
{"revision":5,"kind":"agent_mission_notes","notes":"Sock delivered sensor-supported1; sock attempts1 shirt attempts1 to…
20,326
in 3 · out 176 · cR 4773 · cW 15374 · reason 9
$0.206
224.0s
toolUse
robot_execute_sequence
Unieś koszulkę i schowaj zamknięty chwytak do transportu
ok · move_tcp → move_tcp · F=1.50N · grip=yes
20,584
in 3 · out 96 · cR 20147 · cW 338
$0.029
233.1s
toolUse
robot_observe
Sprawdź utrzymanie koszulki i prześwit przed transportem
{"observation_id":"obs-e46a2d2e-7-17958","session_id":"e46a2d2e","time_s":35.916,"rgb_path":"/home/pawel/Documents/home…
20,685
in 3 · out 35 · cR 20485 · cW 162
$0.024
245.5s
toolUse
robot_move_base
Przewieź trzymaną koszulkę znanym wolnym korytarzem bliżej pojemnika
ok
22,001
in 3 · out 119 · cR 4773 · cW 17106 · reason 29
$0.225
253.3s
toolUse
robot_observe
Sprawdź kontakt po transporcie i przelicz pojemnik względem bazy
{"observation_id":"obs-e46a2d2e-8-19545","session_id":"e46a2d2e","time_s":39.09,"rgb_path":"/home/pawel/Documents/homeb…
22,091
in 3 · out 38 · cR 21879 · cW 171
$0.026
267.6s
toolUse
mission_memory_write
Zapisz skrypt ustawienia koszulki nad pojemnikiem przed zwolnieniem
{"revision":6,"kind":"agent_mission_notes","notes":"Sock delivery1 confirmed visually in bin obs8. Shirt attempt1 held …
23,535
in 3 · out 153 · cR 4773 · cW 18606
$0.245
275.2s
toolUse
robot_execute_sequence
Ustaw koszulkę wysoko nad wnętrzem pojemnika bez puszczania
ok · move_tcp → move_tcp → wait · F=1.56N · grip=yes
23,797
in 3 · out 100 · cR 23379 · cW 315
$0.032
283.5s
toolUse
robot_observe
Obejrzyj wiszącą koszulkę względem rantu i środka pojemnika
{"observation_id":"obs-e46a2d2e-9-22084","session_id":"e46a2d2e","time_s":44.168,"rgb_path":"/home/pawel/Documents/home…
23,906
in 3 · out 41 · cR 23694 · cW 168
$0.028
297.2s
toolUse
mission_memory_write
Zapisz plan kontrolowanego odłożenia koszulki
{"revision":7,"kind":"agent_mission_notes","notes":"Sock delivered1. Shirt held above bin obs9 centroid(.571,.491,.466)…
25,494
in 3 · out 135 · cR 4773 · cW 20583
$0.269
304.5s
toolUse
robot_execute_sequence
Opuść koszulkę do pojemnika, puść i wycofaj chwytak
ok · move_tcp → open_gripper → wait → move_tcp · F=1.59N · grip=no
25,757
in 3 · out 112 · cR 25356 · cW 286
$0.035
31—
aborted
—0
in 0 · out 0
—

Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).

evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.06718195200638405
    },
    "shirt_red": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.1146455579371122
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.00397607217800006
    }
  },
  "events": [],
  "sim_time_s": 47.430000000012,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}

laundry-replay-demo

live run · 2026-11-02 13:05 · homebot-lab/runs/laundry-replay-demo
częściowo 3/4

MP4 · 836.2 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluetak100%
sock_yellowtak100%
shirt_redtak100%
towel_greennie0%
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07
    },
    "sock_yellow": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.104
    },
    "shirt_red": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.105
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.283
    }
  },
  "events": [
    {
      "event": "force_stop",
      "time": 60.190000000027595,
      "N": 3.035127693440576
    }
  ],
  "sim_time_s": 60.19,
  "sequences": 11,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "limitations": [
    "ideal Cartesian TCP: no calibrated arm IK, actuator torque or wheel dynamics",
    "external calibrated RGB-D camera; segmentation and vertex association from simulator",
    "force-limited spring pinch, not finger/cloth friction",
    "towel corner pinned to model a furniture snag"
  ]
}
Archiwum eksperymentów

free_towel_agent

towel attempt · 2026-11-02 13:03 · homebot-lab/experiments/laundry/original_runs/free_towel_agent
0/4 w koszu

MP4 · 155.9 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie0%
sock_yellownie0%
shirt_rednie0%
towel_greennie0%
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.004
    },
    "sock_yellow": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.004
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.019
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.479
    }
  },
  "events": [
    {
      "event": "force_stop",
      "time": 12.262000000000764,
      "N": 3.0330240580641883
    }
  ],
  "sim_time_s": 12.262,
  "sequences": 2,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "limitations": [
    "ideal Cartesian TCP: no calibrated arm IK, actuator torque or wheel dynamics",
    "external calibrated RGB-D camera; segmentation and vertex association from simulator",
    "force-limited spring pinch, not finger/cloth friction",
    "towel corner pinned to model a furniture snag"
  ]
}

live_final

laundry live_final · 2026-11-02 13:03 · homebot-lab/experiments/laundry/original_runs/live_final
archiwum

MP4 · 46.7 KB · pełny ekran w playerze

Brak evaluation/map memory.

Logi
brak logów

agent_demo

laundry agent_demo · 2026-11-02 13:03 · homebot-lab/experiments/laundry/original_runs/agent_demo
0/4 w koszu

MP4 · 834.7 KB · pełny ekran w playerze

obiektdostarczonyw koszu
sock_bluenie100%
sock_yellownie100%
shirt_rednie90%
towel_greennie0%
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": false,
      "max_z_m": 0.074
    },
    "sock_yellow": {
      "fraction_in_bin": 1.0,
      "delivered": false,
      "max_z_m": 0.104
    },
    "shirt_red": {
      "fraction_in_bin": 0.902,
      "delivered": false,
      "max_z_m": 0.092
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.283
    }
  },
  "events": [
    {
      "event": "force_stop",
      "time": 60.190000000027595,
      "N": 3.035128689845997
    }
  ],
  "sim_time_s": 60.19,
  "sequences": 11,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "limitations": [
    "ideal Cartesian TCP: no calibrated arm IK, actuator torque or wheel dynamics",
    "external calibrated RGB-D camera; segmentation and vertex association from simulator",
    "force-limited spring pinch, not finger/cloth friction",
    "towel corner pinned to model a furniture snag"
  ]
}

HomeBot_Room_Mapping

mapping evidence · 2026-11-02 11:42 · homebot-lab/experiments/mapping/evidence/HomeBot_Room_Mapping.mp4
archiwum

MP4 · 244.9 KB · pełny ekran w playerze

Brak evaluation/map memory.

Logi
brak logów

HomeBot_Laundry_MuJoCo

laundry evidence · 2026-11-02 11:42 · homebot-lab/experiments/laundry/evidence/HomeBot_Laundry_MuJoCo.mp4
archiwum

MP4 · 834.7 KB · pełny ekran w playerze

Brak evaluation/map memory.

Logi
brak logów