omp-laundry-sonnet55-001
live run · 2026-11-02 17:41 ·
homebot-lab/runs/omp-laundry-sonnet55-001MP4 · 987.9 KB · pełny ekran w playerze
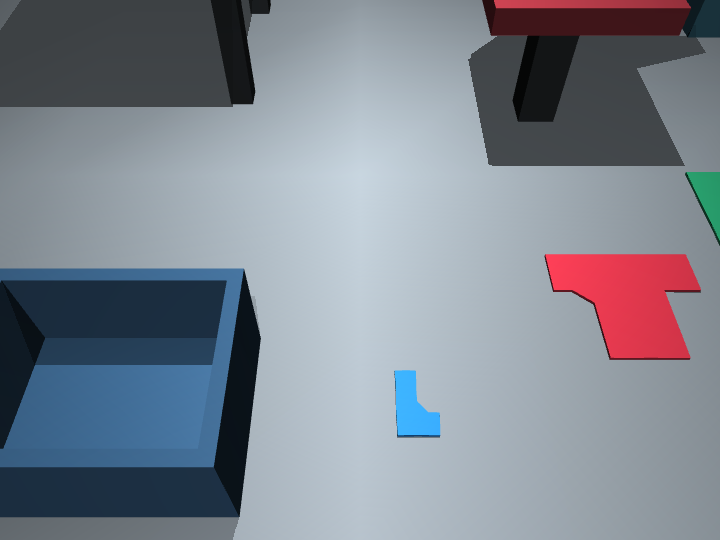
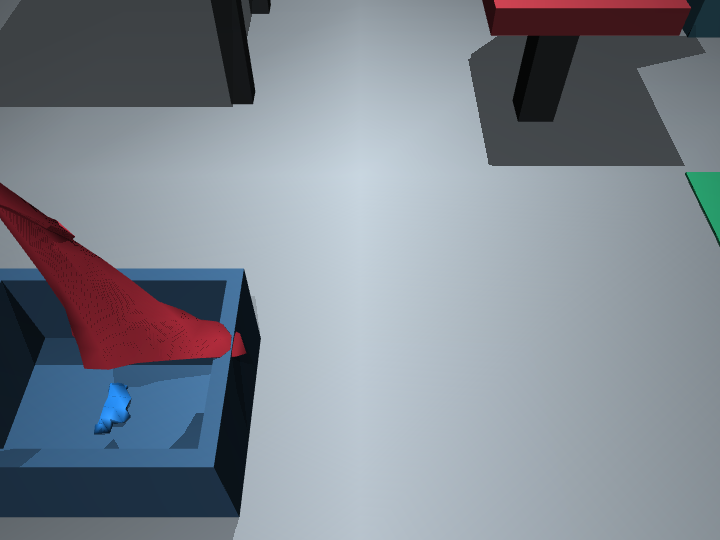
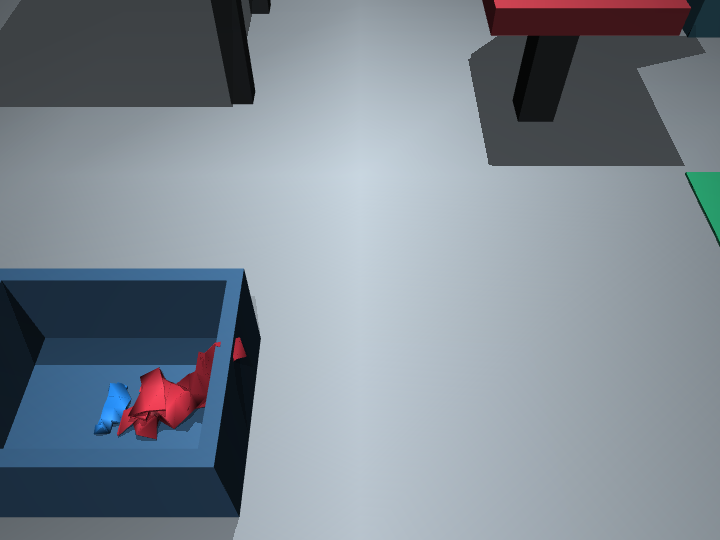
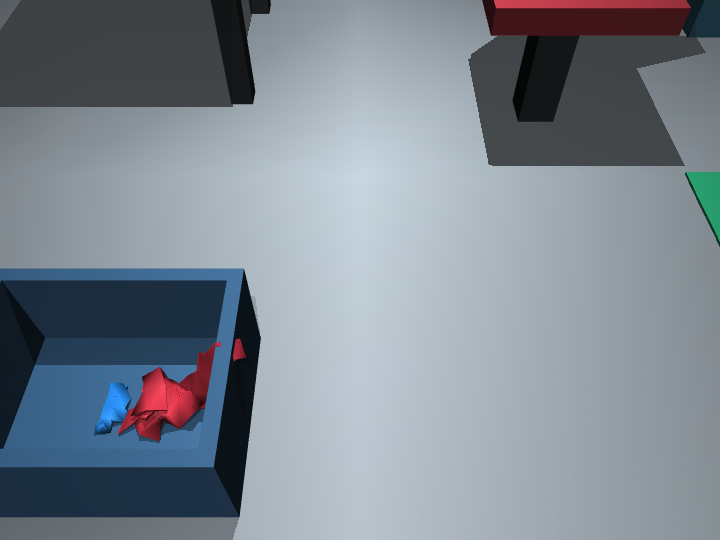
| obiekt | dostarczony | w koszu |
|---|---|---|
| sock_blue | tak | 100% |
| shirt_red | tak | 93% |
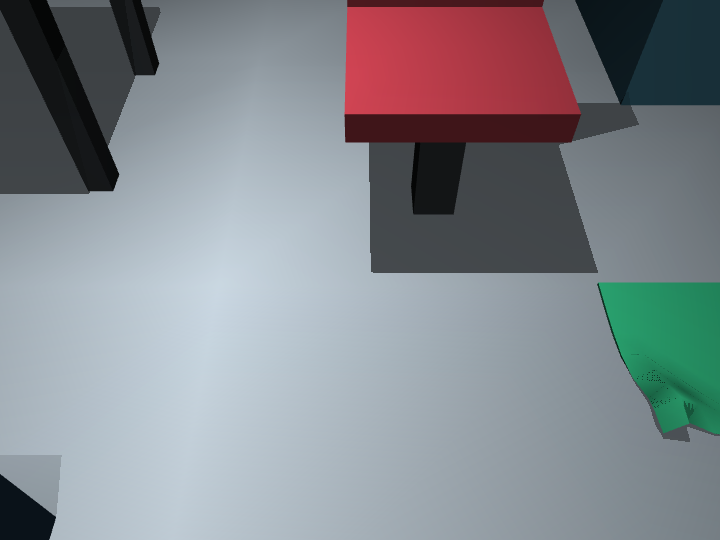
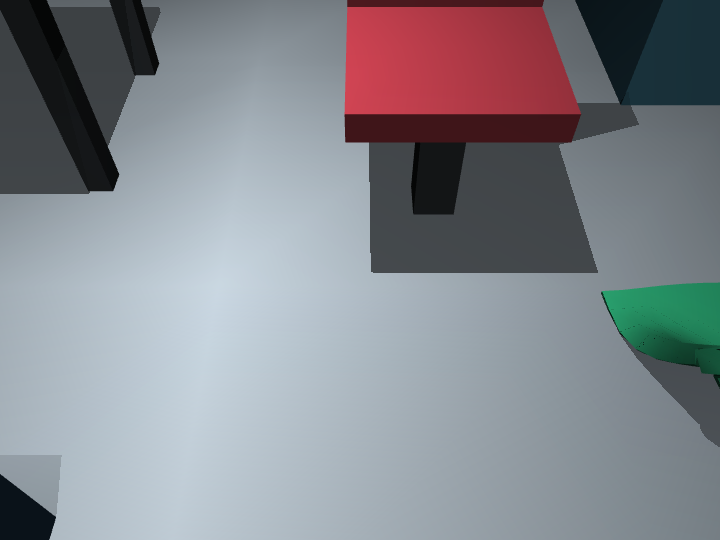
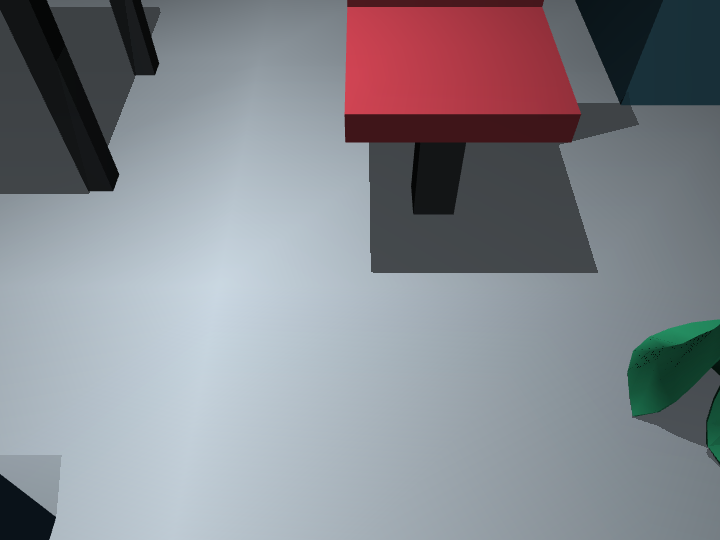
| towel_green | nie | 0% |
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt26 calli · $0.831
ag. limity26 req · 12 seq · 30 tools
czas misji183.7s
calle LLM
26
tool calls
30
koszt zadania
$0.831
tokeny (sum)
734,697
in / out
6,354 / 9,059
cache R/W
446,068 / 273,216
czas modelu
135.8s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 2.2s toolUse | robot_capabilities discover mode=SIMULATION_ONLY mission_memory_read read memory {"revision":0,"agent_notes":null} robot_observe initial observation {"observation_id":"obs-a6b0cf03-1-350","session_id":"a6b0cf03","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l… | 9,582 in 4 · out 151 · cR 0 · cW 9427 | $0.025 |
| 2 | 6.5s toolUse | robot_execute_sequence grasp sock, test lift ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.79N · grip=yes | 13,704 in 527 · out 528 · cR 9427 · cW 3222 · reason 280 | $0.015 |
| 3 | 2.4s toolUse | robot_observe verify lift {"observation_id":"obs-a6b0cf03-2-3227","session_id":"a6b0cf03","time_s":6.454,"rgb_path":"/home/pawel/Documents/homebo… | 13,586 in 2 · out 52 · cR 12649 · cW 883 | $0.0040 |
| 4 | 7.2s toolUse | robot_execute_sequence move sock over bin ok · move_tcp → move_tcp · F=0.28N · grip=yes | 16,725 in 527 · out 569 · cR 13532 · cW 2097 · reason 382 | $0.013 |
| 5 | 4.9s toolUse | robot_observe check position {"observation_id":"obs-a6b0cf03-3-5090","session_id":"a6b0cf03","time_s":10.18,"rgb_path":"/home/pawel/Documents/homebo… | 16,703 in 2 · out 271 · cR 15629 · cW 801 · reason 220 | $0.0063 |
| 6 | 4.5s toolUse | robot_execute_sequence lower slightly and release sock ok · move_tcp → open_gripper → wait → move_tcp · F=0.29N · grip=no | 19,389 in 527 · out 340 · cR 16430 · cW 2092 · reason 129 | $0.011 |
| 7 | 2.1s toolUse | robot_observe verify sock in bin {"observation_id":"obs-a6b0cf03-4-6575","session_id":"a6b0cf03","time_s":13.15,"rgb_path":"/home/pawel/Documents/homebo… | 19,413 in 2 · out 55 · cR 18522 · cW 834 | $0.0045 |
| 8 | 8.4s toolUse | mission_memory_write progress {"revision":1,"kind":"agent_mission_notes","notes":"Mission 41592555. sock_blue: 1 grasp, lifted, released over bin; vi… robot_execute_sequence grasp shirt, test lift ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.81N · grip=yes | 22,858 in 527 · out 882 · cR 19356 · cW 2093 · reason 467 | $0.017 |
| 9 | 2.0s toolUse | robot_observe verify shirt lift {"observation_id":"obs-a6b0cf03-5-9974","session_id":"a6b0cf03","time_s":19.948,"rgb_path":"/home/pawel/Documents/homeb… | 22,772 in 2 · out 55 · cR 21449 · cW 1266 | $0.0059 |
| 10 | 5.8s toolUse | robot_execute_sequence raise shirt and move above bin ok · move_tcp → move_tcp → move_tcp · F=1.56N · grip=yes | 25,745 in 527 · out 408 · cR 22715 · cW 2095 · reason 193 | $0.013 |
| 11 | 3.7s toolUse | robot_observe check shirt over bin {"observation_id":"obs-a6b0cf03-6-13958","session_id":"a6b0cf03","time_s":27.916,"rgb_path":"/home/pawel/Documents/home… | 25,703 in 2 · out 55 · cR 24810 · cW 836 | $0.0051 |
| 12 | 6.2s toolUse | robot_execute_sequence lower, release shirt, retract ok · move_tcp → open_gripper → wait → move_tcp · F=1.54N · grip=no | 28,230 in 527 · out 439 · cR 0 · cW 27264 · reason 226 | $0.074 |
| 13 | 3.0s toolUse | robot_observe verify shirt in bin {"observation_id":"obs-a6b0cf03-7-15803","session_id":"a6b0cf03","time_s":31.606,"rgb_path":"/home/pawel/Documents/home… | 28,159 in 2 · out 56 · cR 27264 · cW 837 | $0.0054 |
| 14 | 7.9s toolUse | mission_memory_write progress {"revision":2,"kind":"agent_mission_notes","notes":"sock and shirt released over bin, both visible in bin in RGB (not h… robot_execute_sequence stow arm ok · move_tcp · F=0.00N · grip=no | 30,816 in 527 · out 638 · cR 0 · cW 29651 · reason 314 | $0.082 |
| 15 | 6.8s toolUse | robot_move_base approach towel rejected | 31,351 in 2 · out 557 · cR 29651 · cW 1141 · reason 361 | $0.011 |
| 16 | 3.1s toolUse | robot_observe fresh obs {"observation_id":"obs-a6b0cf03-8-17452","session_id":"a6b0cf03","time_s":34.904,"rgb_path":"/home/pawel/Documents/home… | 31,067 in 2 · out 53 · cR 30792 · cW 220 | $0.0042 |
| 17 | 7.0s toolUse | robot_move_base approach towel ok | 33,598 in 527 · out 525 · cR 0 · cW 32546 · reason 329 | $0.088 |
| 18 | 5.7s toolUse | robot_observe observe after move {"observation_id":"obs-a6b0cf03-9-19667","session_id":"a6b0cf03","time_s":39.334,"rgb_path":"/home/pawel/Documents/home… | 33,513 in 2 · out 141 · cR 32546 · cW 824 · reason 88 | $0.0067 |
| 19 | 6.4s toolUse | robot_execute_sequence towel grasp attempt 1, small test lift ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.85N · grip=yes | 35,601 in 527 · out 432 · cR 0 · cW 34642 · reason 184 | $0.092 |
| 20 | 2.2s toolUse | robot_observe verify towel lift {"observation_id":"obs-a6b0cf03-10-23019","session_id":"a6b0cf03","time_s":46.038,"rgb_path":"/home/pawel/Documents/hom… | 35,575 in 2 · out 54 · cR 34642 · cW 877 | $0.0062 |
| 21 | 5.9s toolUse | robot_execute_sequence higher lift test, check snag ok · move_tcp → wait · F=1.08N · grip=yes | 37,632 in 527 · out 302 · cR 0 · cW 36803 · reason 119 | $0.096 |
| 22 | 2.6s toolUse | robot_observe check towel rise {"observation_id":"obs-a6b0cf03-11-23725","session_id":"a6b0cf03","time_s":47.45,"rgb_path":"/home/pawel/Documents/home… | 37,653 in 2 · out 53 · cR 36803 · cW 795 | $0.0062 |
| 23 | 11.3s toolUse | robot_execute_sequence lift towel higher, check for snag via force/geometry ok · move_tcp → wait · F=1.46N · grip=yes | 40,259 in 527 · out 849 · cR 0 · cW 38883 · reason 658 | $0.107 |
| 24 | 2.1s toolUse | robot_observe check towel {"observation_id":"obs-a6b0cf03-12-24431","session_id":"a6b0cf03","time_s":48.862,"rgb_path":"/home/pawel/Documents/hom… | 39,739 in 2 · out 51 · cR 38883 · cW 803 | $0.0064 |
| 25 | 7.9s toolUse | mission_memory_write final notes {"revision":3,"kind":"agent_mission_notes","notes":"Mission 41592555 final. sock_blue: 1 grasp, delivered - visible in … robot_stop Suspected towel snag: stop attempt, preserve load stopped | 42,260 in 527 · out 765 · cR 0 · cW 40968 · reason 380 | $0.111 |
| 26 | 7.9s stop | Zebrałem do pojemnika skarpetę i koszulkę. Ręcznika nie udało się dostarczyć, więc wynik jest częściowy. **Skarpeta (`sock_blue`)** - Jeden chwyt, test podniesienia potwierdził kontakt i wzrost skarpety. - Przeniosłem … | 43,064 in 2 · out 778 · cR 40968 · cW 1316 | $0.015 |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
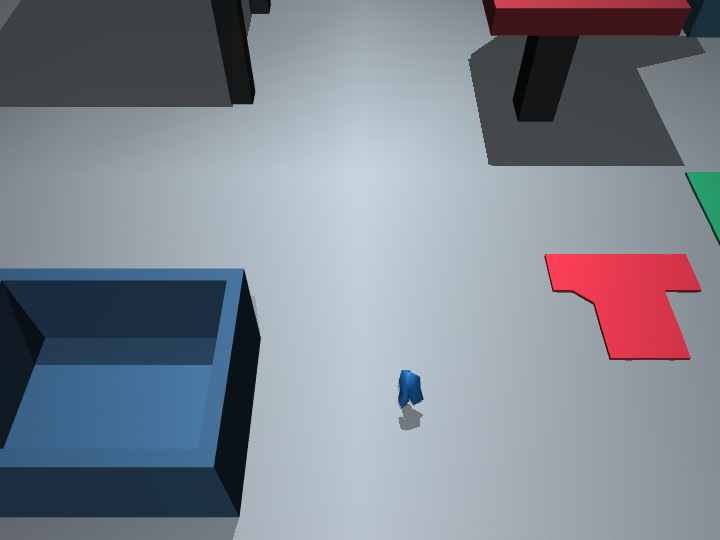
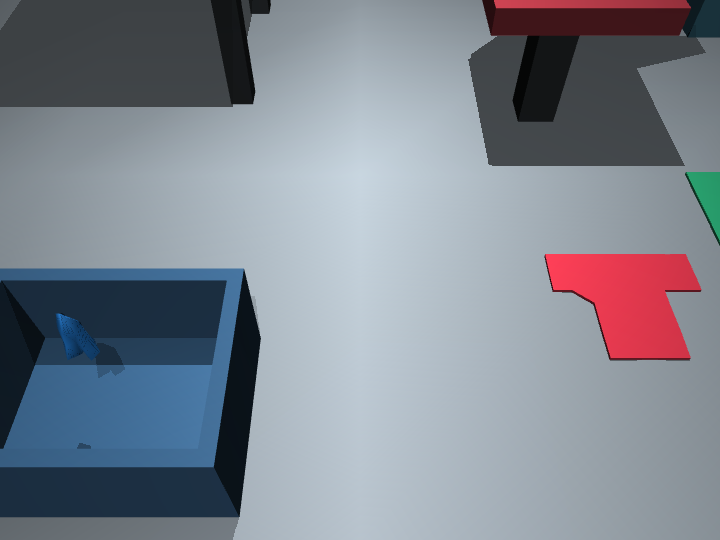
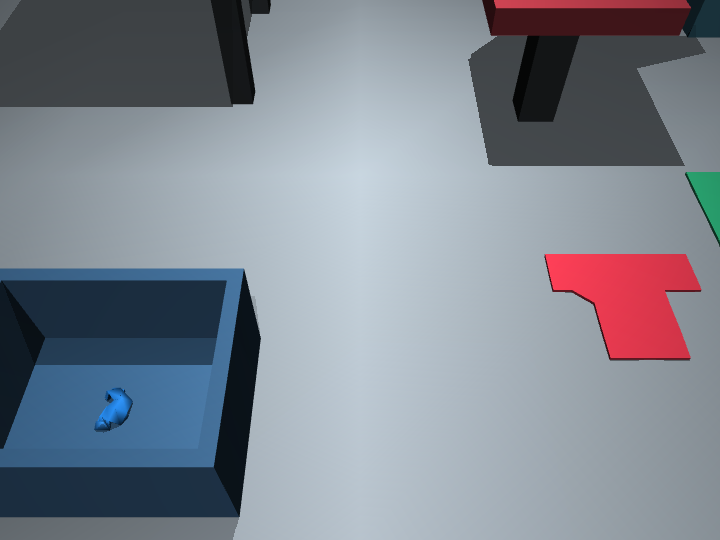
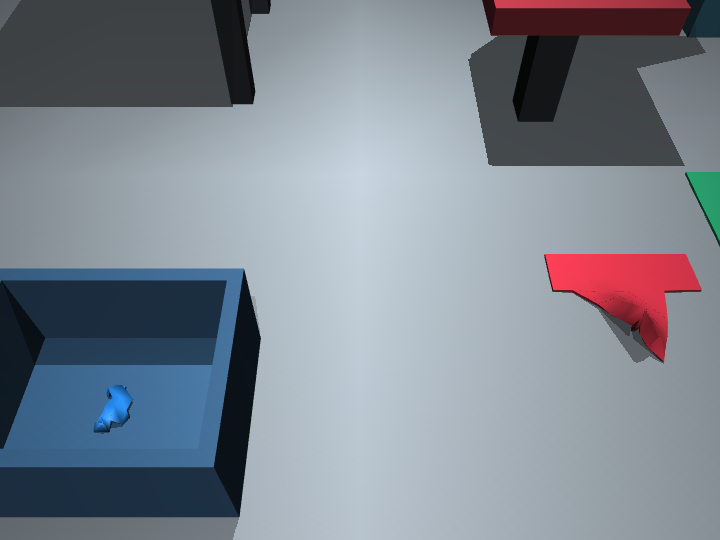
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07434399081902064
    },
    "shirt_red": {
      "fraction_in_bin": 0.934,
      "delivered": true,
      "max_z_m": 0.26365402367562407
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.4751748183374354
    }
  },
  "events": [],
  "sim_time_s": 48.86200000001375,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}