omp-map-gpt4o-ground-002
dom · homebot-dom · 2026-11-02 19:10 ·
homebot-dom/runs/omp-map-gpt4o-ground-002MP4 · 183.0 KB · pełny ekran w playerze
room
living_ground · rev 1| wymiar | wartość | status |
|---|---|---|
| width | — | opposing_planes_not_observed |
| length | — | opposing_planes_not_observed |
| height | — | floor_or_ceiling_not_observed |
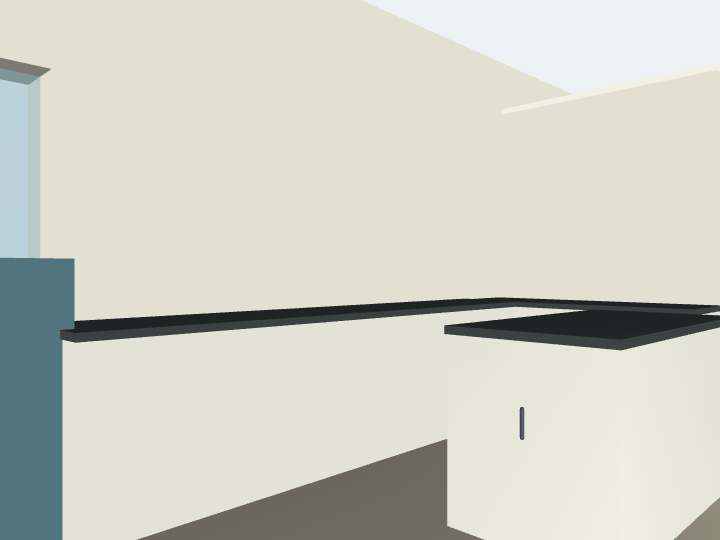
ściany: wall_main_w, wall_vest_s
obiekty: g_tv, g_kitchen_w, g_kitchen_n, g_island
skillhouse-ground
modelopenai/gpt-4o
profilgpu
LLM / koszt8 calli · $0.108
ag. limity7 req · 2 seq · 8 tools
czas misji20.2s
status agentarobot_stop_latched
calle LLM
8
tool calls
8
koszt zadania
$0.108
tokeny (sum)
65,282
in / out
18,775 / 299
cache R/W
46,208 / 0
czas modelu
16.3s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 1.8s toolUse | robot_capabilities Discover capabilities of the robot mode=SIMULATION_ONLY mission_memory_read Read previous mission memory, if available {"revision":0,"agent_notes":null} | 5,890 in 5831 · out 59 | $0.015 |
| 2 | 1.5s toolUse | robot_observe Gather initial observation of the room {"observation_id":"obs-332a92a6-1-350","session_id":"332a92a6","time_s":0.7,"rgb_path":"/home/pawel/Documents/HomeBot_P… | 6,796 in 1015 · out 21 · cR 5760 · cW 0 | $0.0099 |
| 3 | 4.2s toolUse | robot_look Pan and tilt to get a better view ok | 9,050 in 8992 · out 58 | $0.023 |
| 4 | 2.1s toolUse | robot_observe Gather observation after camera movement {"observation_id":"obs-332a92a6-2-913","session_id":"332a92a6","time_s":1.826,"rgb_path":"/home/pawel/Documents/HomeBot… | 9,119 in 139 · out 20 · cR 8960 · cW 0 | $0.012 |
| 5 | 2.3s toolUse | room_measure Measure room dimensions after new observation {"memory_revision":1,"dimensions":{"width":{"value_m":null,"status":"opposing_planes_not_observed"},"length":{"value_m"… | 11,283 in 2299 · out 24 · cR 8960 · cW 0 | $0.017 |
| 6 | 2.4s toolUse | mission_memory_write Write notes about visible room elements after observation {"revision":1,"kind":"agent_mission_notes","notes":"Observed walls: wall_main_w, wall_vest_s. Visible furniture: TV, ki… | 11,504 in 319 · out 49 · cR 11136 · cW 0 | $0.015 |
| 7 | 2.1s toolUse | robot_move_base Move base slightly to gain a better perspective on room dimensions collision_guard | 11,640 in 180 · out 68 · cR 11392 · cW 0 | $0.015 |
| 8 | — aborted | — | 0 in 0 · out 0 | — |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
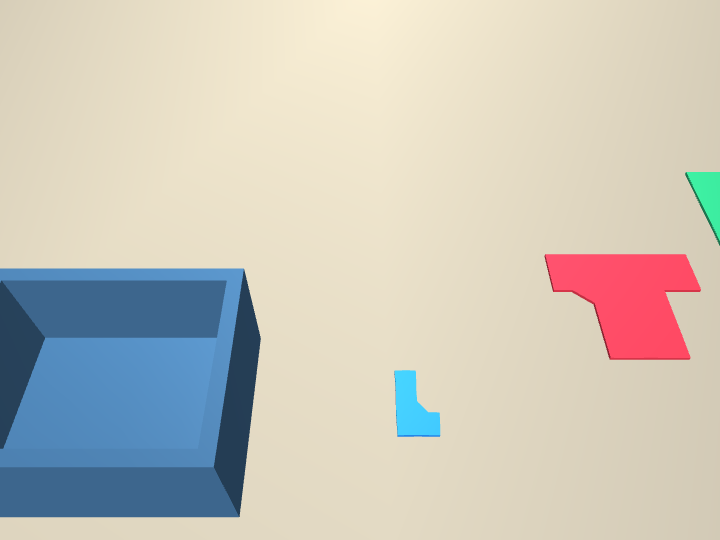
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003981167881223428
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976830550232652
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976194567067097
    }
  },
  "events": [],
  "sim_time_s": 1.8260000000000014,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor",
  "doors": {
    "g_entrance": {
      "hinge_angle_rad": 1.7954173729684502e-38,
      "handle_angle_rad": -1.4801365655551515e-18,
      "latch_active": true
    },
    "g_garage_utility": {
      "hinge_angle_rad": -9.115101869203954e-09,
      "handle_angle_rad": -7.134280375091383e-19,
      "latch_active": true
    },
    "g_utility_hall": {
      "hinge_angle_rad": 0.0,
      "handle_angle_rad": -1.4800792036491003e-18,
      "latch_active": true
    },
    "g_office": {
      "hinge_angle_rad": -9.115101869192668e-09,
      "handle_angle_rad": -2.303831533336789e-18,
      "latch_active": true
    },
    "g_wc": {
      "hinge_angle_rad": -9.105487218718805e-09,
      "handle_angle_rad": -3.474846430570292e-18,
      "latch_active": true
    },
    "g_vestibule": {
      "hinge_angle_rad": -9.105487218718805e-09,
      "handle_angle_rad": -3.474846430570292e-18,
      "latch_active": true
    },
    "g_fitness": {
      "hinge_angle_rad": -9.115101869195405e-09,
      "handle_angle_rad": -6.926040406684193e-17,
      "latch_active": true
    }
  },
  "floor_id": "ground"
}