omp-laundry-sonnet55-towel-001
live run · 2026-11-02 17:57 ·
homebot-lab/runs/omp-laundry-sonnet55-towel-001MP4 · 698.4 KB · pełny ekran w playerze
| obiekt | dostarczony | w koszu |
|---|---|---|
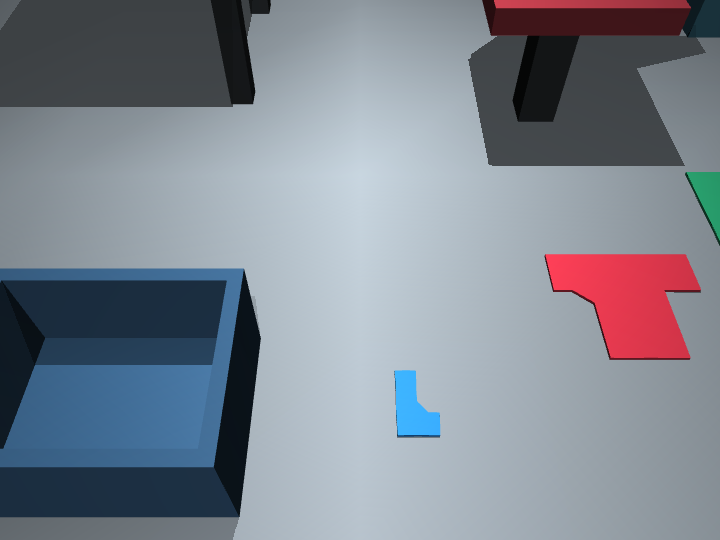
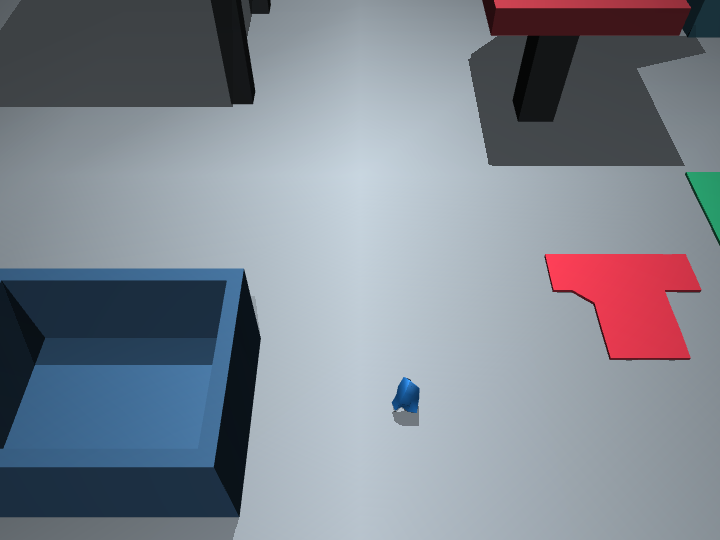
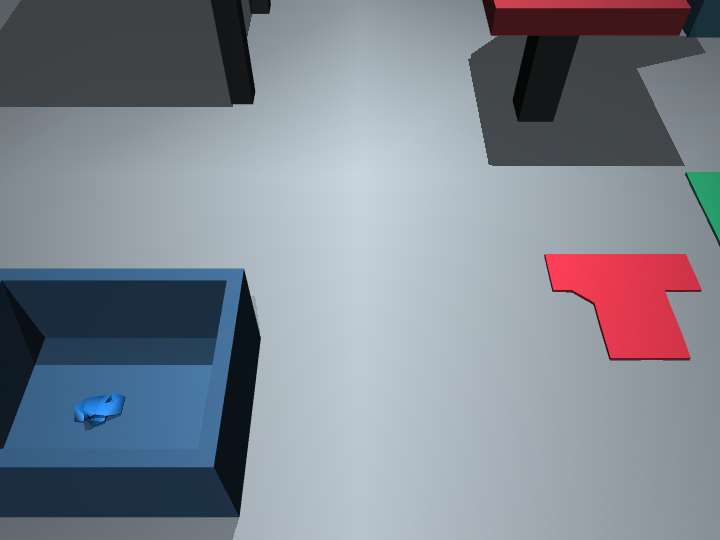
| sock_blue | tak | 100% |
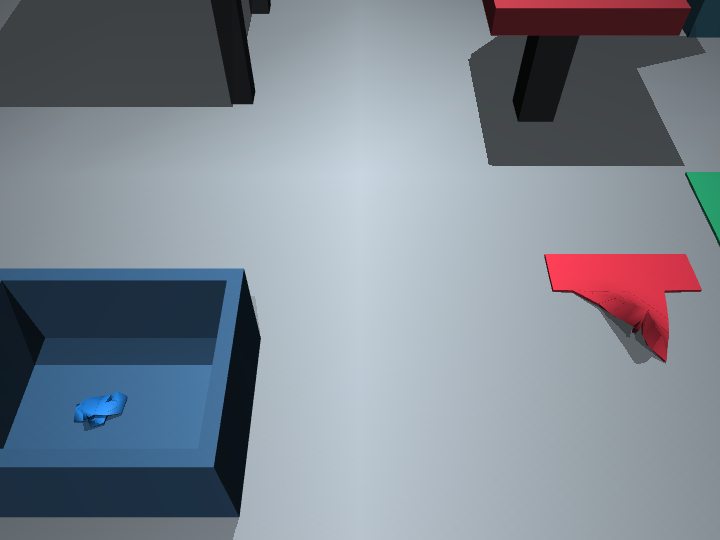
| shirt_red | tak | 93% |
| towel_green | nie | 0% |
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt11 calli · $0.123
ag. limity10 req · 5 seq · 13 tools
czas misji79.8s
status agentarobot_stop_latched
calle LLM
11
tool calls
13
koszt zadania
$0.123
tokeny (sum)
182,023
in / out
2,647 / 4,050
cache R/W
150,667 / 24,659
czas modelu
50.6s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 1.9s toolUse | robot_capabilities discover mode=SIMULATION_ONLY mission_memory_read read notes {"revision":0,"agent_notes":null} robot_observe initial observation {"observation_id":"obs-e879853c-1-350","session_id":"e879853c","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l… | 9,706 in 4 · out 151 · cR 0 · cW 9551 | $0.025 |
| 2 | 6.6s toolUse | robot_execute_sequence grasp sock ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.84N · grip=yes | 13,927 in 527 · out 633 · cR 9551 · cW 3216 · reason 392 | $0.016 |
| 3 | 1.8s toolUse | robot_observe verify sock lift {"observation_id":"obs-e879853c-2-3135","session_id":"e879853c","time_s":6.27,"rgb_path":"/home/pawel/Documents/homebot… | 13,702 in 2 · out 54 · cR 12767 · cW 879 | $0.0040 |
| 4 | 7.7s toolUse | robot_execute_sequence sock to bin ok · move_tcp → move_tcp → open_gripper → wait → move_tcp · F=0.29N · grip=no | 16,938 in 527 · out 671 · cR 13646 · cW 2094 · reason 442 | $0.014 |
| 5 | 4.3s toolUse | robot_observe verify sock delivery {"observation_id":"obs-e879853c-3-8034","session_id":"e879853c","time_s":16.068,"rgb_path":"/home/pawel/Documents/homeb… | 16,810 in 2 · out 208 · cR 15740 · cW 860 · reason 152 | $0.0058 |
| 6 | 6.9s toolUse | robot_execute_sequence grasp shirt test lift ok · open_gripper → move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.78N · grip=yes | 19,814 in 527 · out 621 · cR 16600 · cW 2066 · reason 374 | $0.014 |
| 7 | 2.6s toolUse | robot_observe verify shirt lift {"observation_id":"obs-e879853c-4-11839","session_id":"e879853c","time_s":23.678,"rgb_path":"/home/pawel/Documents/home… | 19,609 in 2 · out 55 · cR 18666 · cW 886 | $0.0046 |
| 8 | 6.5s toolUse | robot_execute_sequence shirt to bin ok · move_tcp → move_tcp → move_tcp → open_gripper → wait → move_tcp · F=1.57N · grip=no | 22,712 in 527 · out 558 · cR 19552 · cW 2075 · reason 305 | $0.014 |
| 9 | 2.2s toolUse | robot_observe verify shirt delivery {"observation_id":"obs-e879853c-5-19653","session_id":"e879853c","time_s":39.306,"rgb_path":"/home/pawel/Documents/home… | 22,576 in 2 · out 56 · cR 21627 · cW 891 | $0.0050 |
| 10 | 10.1s toolUse | mission_memory_write progress {"revision":1,"kind":"agent_mission_notes","notes":"Mission 7fb945b0: sock_blue wlozona do kosza (widoczna w koszu), sh… robot_move_base approach towel, TCP stowed collision_guard | 26,229 in 527 · out 1043 · cR 22518 · cW 2141 · reason 623 | $0.019 |
| 11 | — aborted | — | 0 in 0 · out 0 | — |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
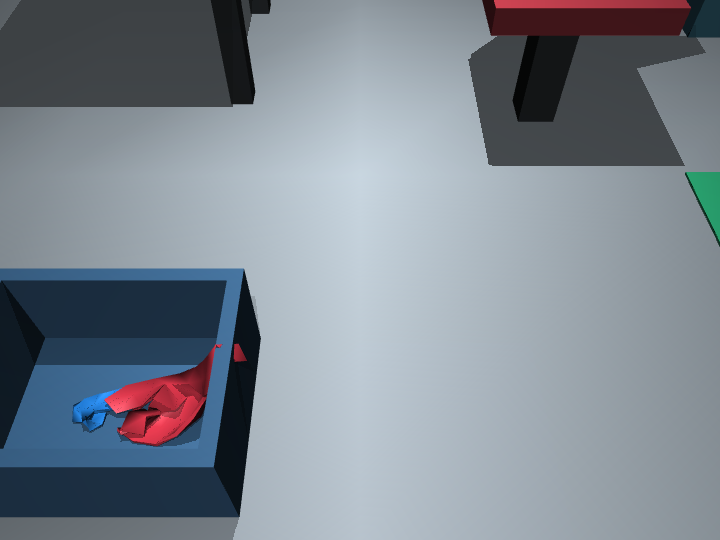
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07711928977352428
    },
    "shirt_red": {
      "fraction_in_bin": 0.934,
      "delivered": true,
      "max_z_m": 0.2636439652320441
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976073846444057
    }
  },
  "events": [],
  "sim_time_s": 39.30600000000207,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}