omp-laundry-sonnet55-002
live run · 2026-11-02 17:57 ·
homebot-lab/runs/omp-laundry-sonnet55-002MP4 · 162.8 KB · pełny ekran w playerze
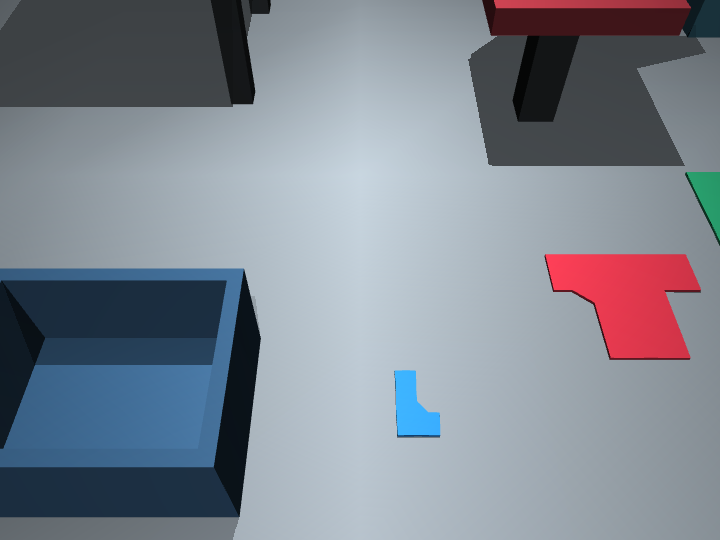
| obiekt | dostarczony | w koszu |
|---|---|---|
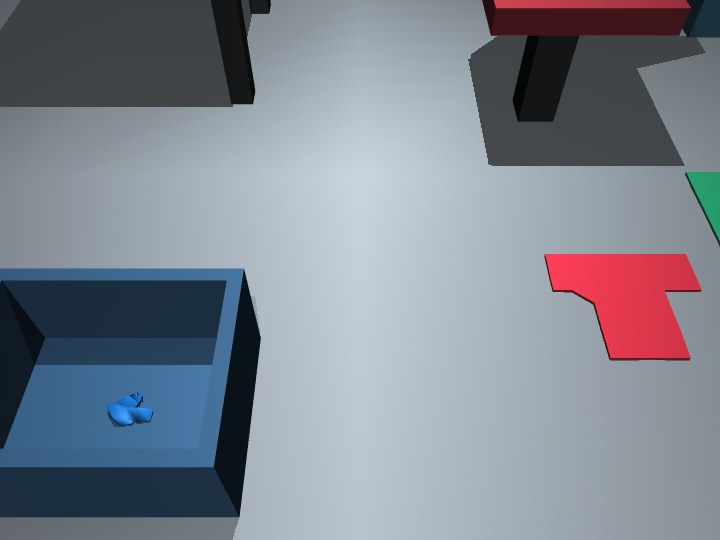
| sock_blue | tak | 100% |
| shirt_red | nie | 0% |
| towel_green | nie | 0% |
skilllaundry
modelanthropic/claude-sonnet-5.5
profilgpu
LLM / koszt7 calli · $0.081
ag. limity6 req · 3 seq · 9 tools
czas misji39.0s
status agentarobot_stop_latched
calle LLM
7
tool calls
9
koszt zadania
$0.081
tokeny (sum)
90,487
in / out
1,589 / 2,490
cache R/W
67,822 / 18,586
czas modelu
29.1s
Calle LLM na zadanie
| # | czas | co zrobił (tool + wynik) | tokeny | koszt |
|---|---|---|---|---|
| 1 | 1.9s toolUse | robot_capabilities discover mode=SIMULATION_ONLY mission_memory_read read memory {"revision":0,"agent_notes":null} robot_observe initial observe {"observation_id":"obs-2ad28cbe-1-350","session_id":"2ad28cbe","time_s":0.7,"rgb_path":"/home/pawel/Documents/homebot-l… | 9,608 in 4 · out 151 · cR 0 · cW 9453 | $0.025 |
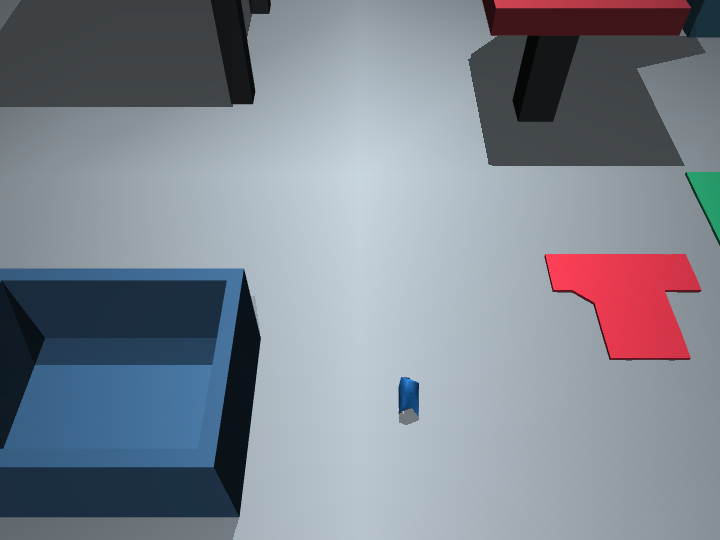
| 2 | 6.9s toolUse | robot_execute_sequence grasp sock and test lift ok · move_tcp → move_tcp → close_gripper → move_tcp → wait · F=0.78N · grip=yes | 13,856 in 527 · out 654 · cR 9453 · cW 3222 · reason 416 | $0.017 |
| 3 | 1.8s toolUse | robot_observe verify lift {"observation_id":"obs-2ad28cbe-2-3169","session_id":"2ad28cbe","time_s":6.338,"rgb_path":"/home/pawel/Documents/homebo… | 13,599 in 2 · out 52 · cR 12675 · cW 870 | $0.0040 |
| 4 | 6.3s toolUse | robot_execute_sequence carry sock over bin and release ok · move_tcp → move_tcp → move_tcp → open_gripper → wait · F=0.31N · grip=no | 16,722 in 527 · out 555 · cR 13545 · cW 2095 · reason 318 | $0.013 |
| 5 | 5.1s toolUse | robot_observe verify sock in bin {"observation_id":"obs-2ad28cbe-3-6352","session_id":"2ad28cbe","time_s":12.704,"rgb_path":"/home/pawel/Documents/homeb… | 16,784 in 2 · out 273 · cR 15640 · cW 869 · reason 217 | $0.0065 |
| 6 | 7.3s toolUse | mission_memory_write progress {"revision":1,"kind":"agent_mission_notes","notes":"Mission 920f474b: sock_blue grasped (1 grasp) and released over bin… robot_execute_sequence grasp shirt, test lift collision_guard · F=0.00N · grip=no · STOP | 19,918 in 527 · out 805 · cR 16509 · cW 2077 · reason 384 | $0.016 |
| 7 | — aborted | — | 0 in 0 · out 0 | — |
Źródła: messages.json · openrouter-costs.json. Koszt = OpenRouter total_cost (nie zerowe metadata SDK).
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 1.0,
      "delivered": true,
      "max_z_m": 0.07947989592302881
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976656708832238
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.003976074608248684
    }
  },
  "events": [],
  "sim_time_s": 12.704000000000912,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "controller_kind": "see host run manifest; evaluator is not a planner sensor"
}