free_towel_agent
towel attempt · 2026-11-02 13:03 ·
homebot-lab/experiments/laundry/original_runs/free_towel_agentMP4 · 155.9 KB · pełny ekran w playerze
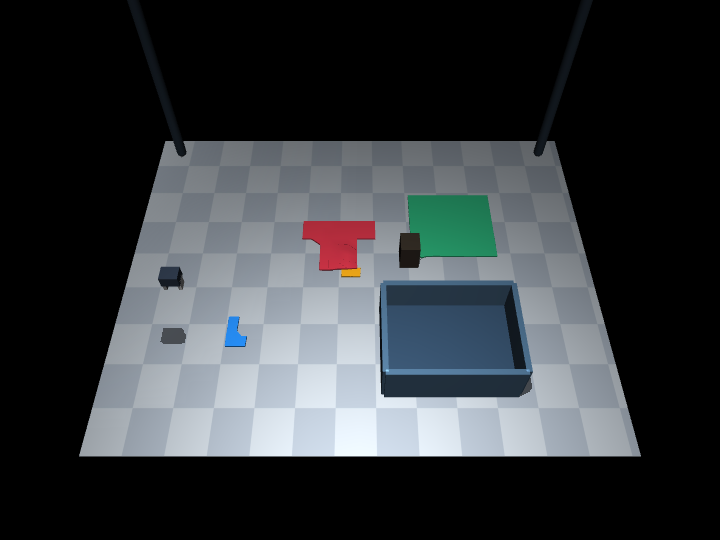
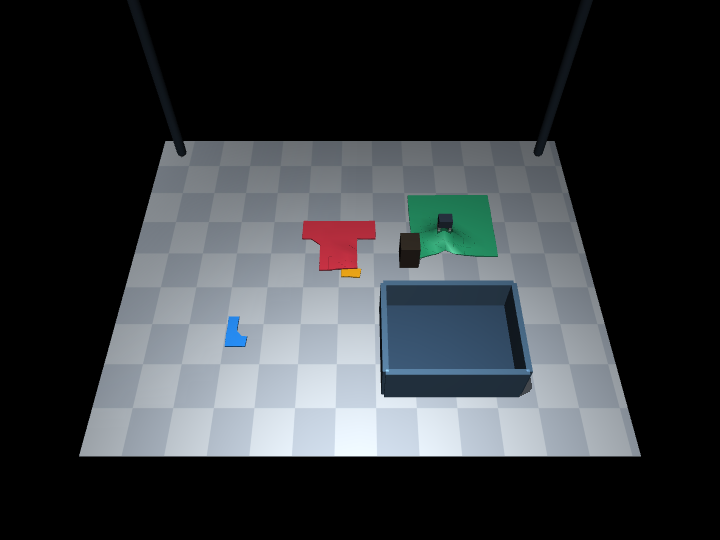
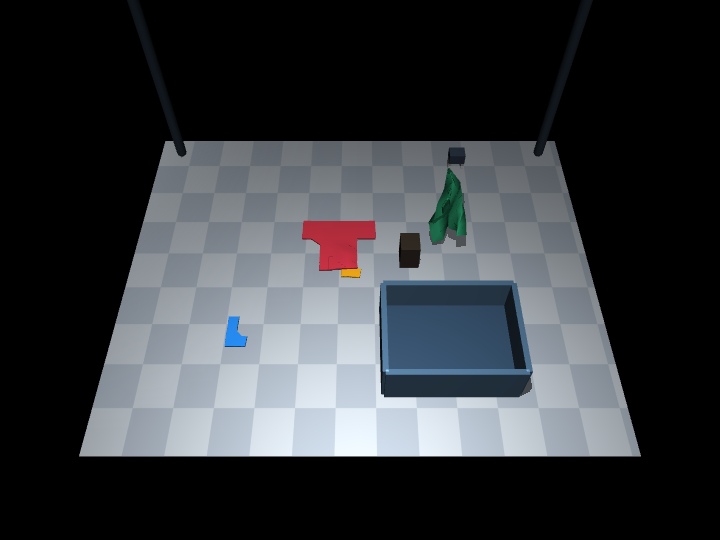
| obiekt | dostarczony | w koszu |
|---|---|---|
| sock_blue | nie | 0% |
| sock_yellow | nie | 0% |
| shirt_red | nie | 0% |
| towel_green | nie | 0% |
evaluation.json
{
  "objects": {
    "sock_blue": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.004
    },
    "sock_yellow": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.004
    },
    "shirt_red": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.019
    },
    "towel_green": {
      "fraction_in_bin": 0.0,
      "delivered": false,
      "max_z_m": 0.479
    }
  },
  "events": [
    {
      "event": "force_stop",
      "time": 12.262000000000764,
      "N": 3.0330240580641883
    }
  ],
  "sim_time_s": 12.262,
  "sequences": 2,
  "physics": "MuJoCo flex 2D FEM/contact/self collision",
  "limitations": [
    "ideal Cartesian TCP: no calibrated arm IK, actuator torque or wheel dynamics",
    "external calibrated RGB-D camera; segmentation and vertex association from simulator",
    "force-limited spring pinch, not finger/cloth friction",
    "towel corner pinned to model a furniture snag"
  ]
}